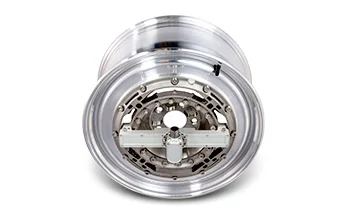
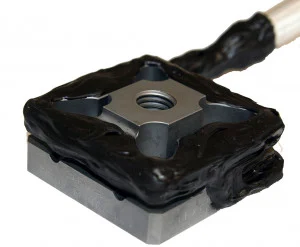
LW9.5 wheel force transducer
Six-axis wheel force transducer for ATVs, utility and other lightweight vehicles, 35.6 kN radial and 17.8 kN lateral, in stainless steel, with amplifier and slip ring.
- 35.6 kN
- Fx, Fz capacity
- 17.8 kN
- Fy capacity
- 5.4 kN·m
- Moment capacity
- ≤ 0.25 % FS
- Non-linearity
- OutputsFx Fy Fz · Mx My Mz
- Also measuredX and Z acceleration (X, Y, Z on the LW50 and LW55) · wheel speed and angle
- Signal outputanalog · CAN · Ethernet · CAN FD and EtherCAT on the CT3
- Signal transmissionslip ring or telemetry
LW9.5: wheel force transducer for ATVs and small vehicles, 35.6 kN
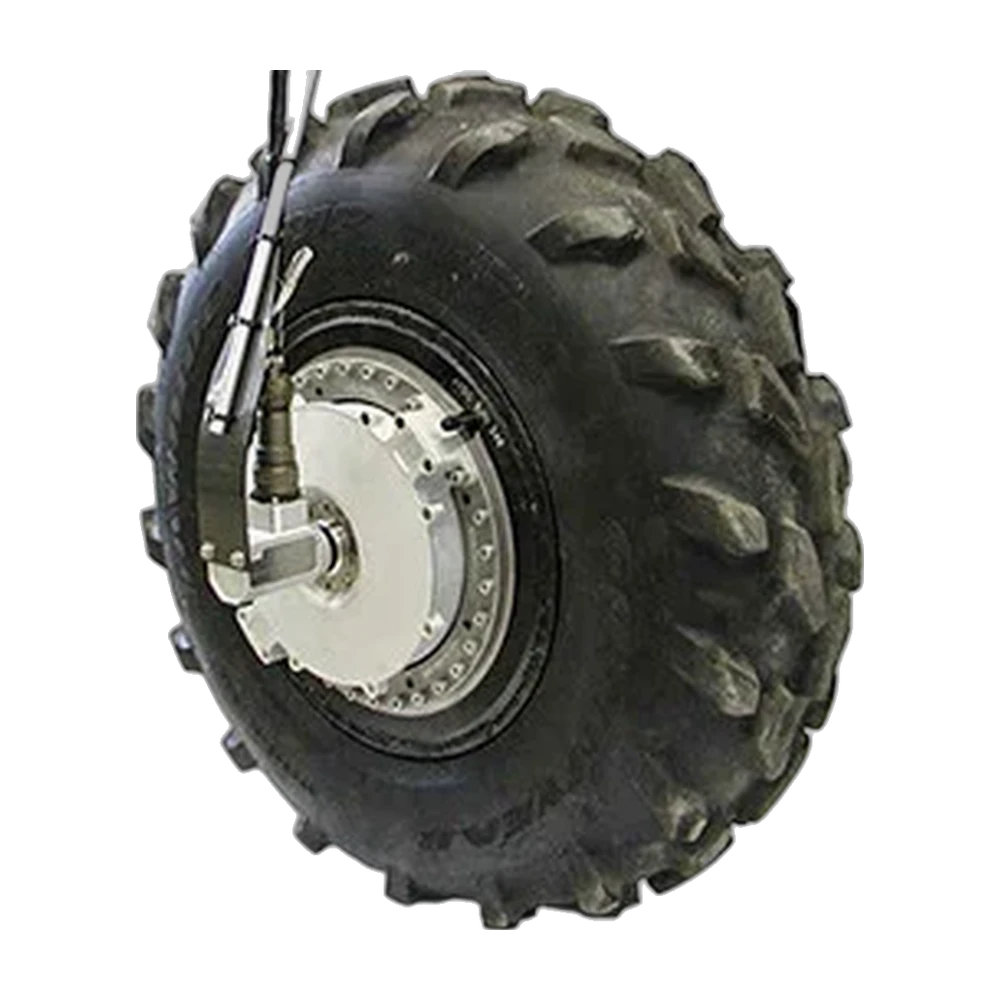
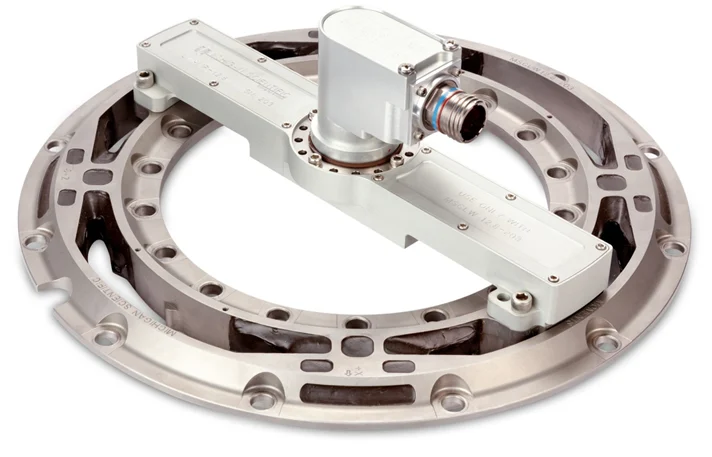
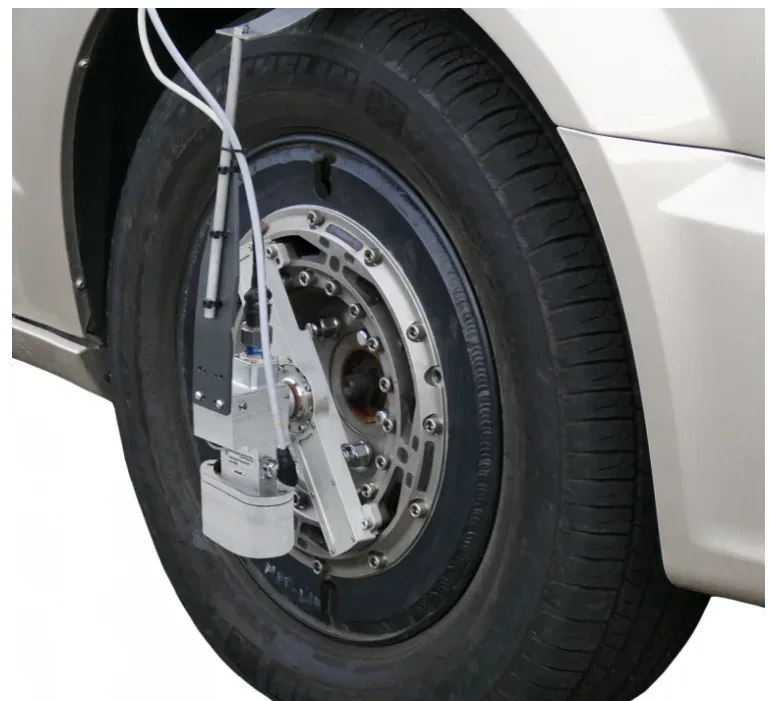
The LW9.5 measures all the wheel forces and moments on ATVs, utility and other lightweight vehicles: vertical, lateral and longitudinal forces, and camber, steer and torque moments. Its 4-arm strain gage bridges are rated 35.6 kN (8,000 lb) on Fx and Fz, 17.8 kN (4,000 lb) on Fy and 5.4 kN·m on all three moments, with non-linearity of 0.25 % of full scale or less. The stainless steel transducer is weatherproof and temperature compensated, operates from −40 to 125 °C and adapts to 10 in and larger wheels. A matching amplifier adds X and Z accelerations and digitizes the signals before the slip ring; angular resolution is 0.17°.
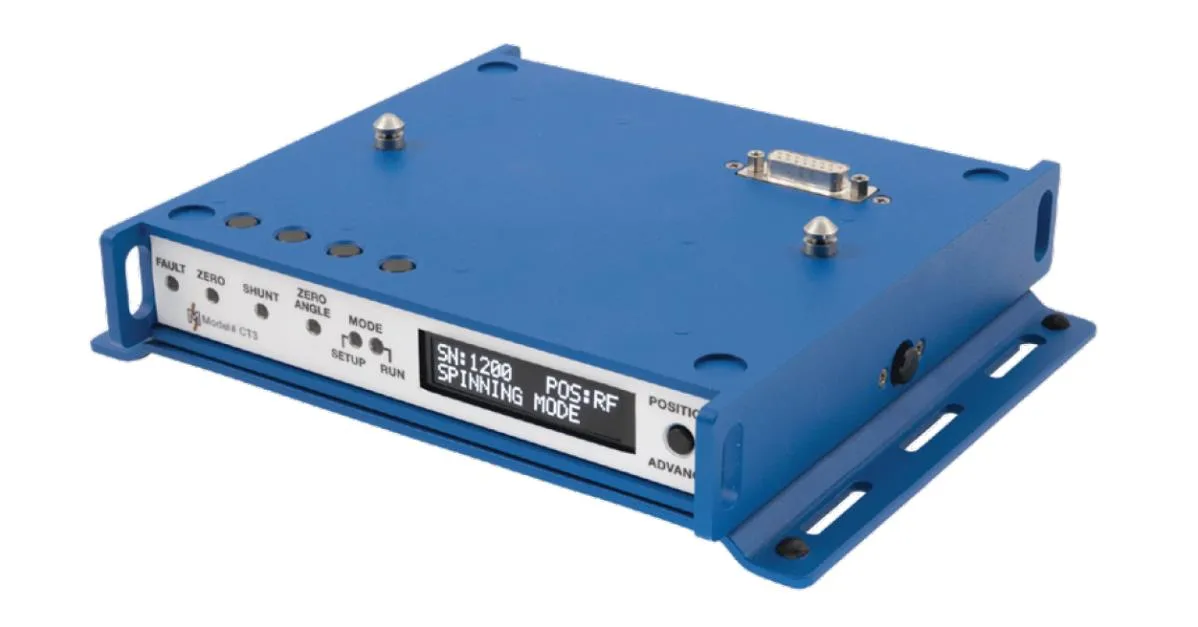
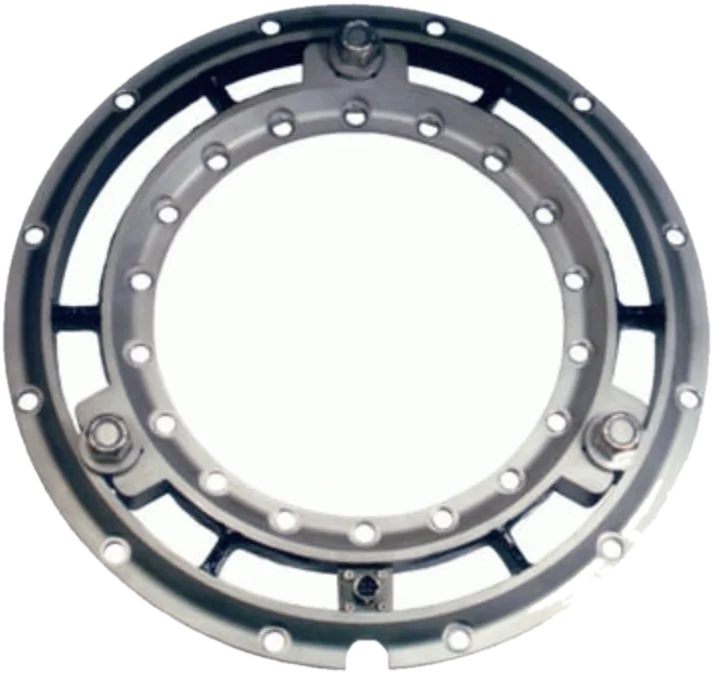
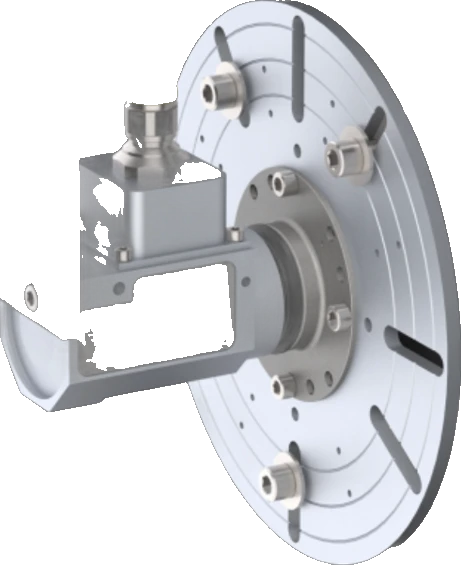
The hub adapter bolts to the transducer with thirty-two 1/4-20 screws and the rim adapter with twenty-four, torqued crosswise to 13 N·m; four more hold the amplifier, sealed by O-rings and matched to its transducer. The slip ring, with a 512-pulse encoder, stays on the amplifier; a magnetic restraint and rod hold its stator on non-steered wheels, a stator angle corrector on steered ones. The CT3 box, powered at 9 to 36 V DC, zeroes the transducer on a hoist or on the road, checks the shunt calibration and gives the loads in vehicle coordinates.
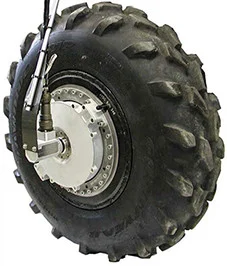
The Michigan Tech Blizzard Baja team fitted an LW9.5 to its off-road car on custom adapters. On a utility vehicle, it records the force falling to zero in flight and peaking at landing after a ramp.
Specifications
| Measured quantities | Fx · Fy · Fz · Mx · My · Mz |
|---|---|
| Force capacity | Fx 35.6 · Fy 17.8 · Fz 35.6 kN |
| Moment capacity | Mx 5 400 · My 5 400 · Mz 5 400 N·m |
| Max static load | 725 kg |
| Non-linearity | ≤ 0.25 % FS |
| Hysteresis | ≤ 0.5 % FS |
| Crosstalk | ≤ 1 % FS (after correction) |
| Angle resolution | 0.17° |
| Axes | 6 |
| Sensing principle | Strain gage (4-arm bridges) |
| Accelerometer range | 55 g (X and Z) |
| Output | Analog voltage · CAN · CAN FD · Ethernet · EtherCAT (CT3; EtherCAT with an add-on module) |
| Signal transmission | Slip ring |
| Material | Stainless steel |
| Operating temperature | −40 to 125 °C |
| Interface box | CT3 |
| Vehicles | ATVs · Utility vehicles · Lightweight vehicles |
| Rim size | 10 in (and larger) |
Request a quote
Unusual bolt pattern, motorsport hub, agricultural wheel: we build it around your wheel.
Used with the LW9.5
What you add here goes into the same quote request.
-
Measure on a steered wheel
SAC stator angle corrector
Corrects the rotation angle signal in real time for the coordinate transformation, with no over-the-wheel bracket. Internal encoder accuracy ≤ 0.25°, IP67.
Slip ring versions, with the CT3 interface box.
Resources
Datasheets and manuals
Drawings
None for LW9.5.
Guides and notes
Related applications
-
 Durability Wheel loads on the road Three forces and three moments at each wheel, recorded while the vehicle is driven.
-
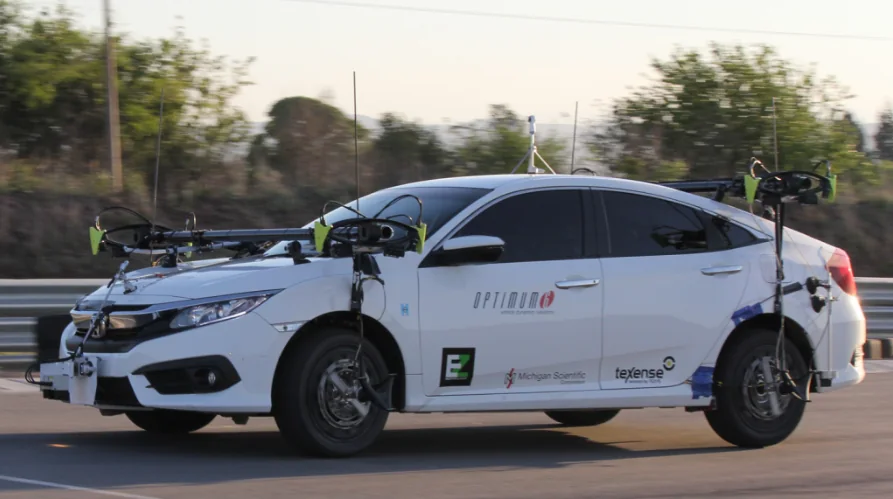 Dynamics Vehicle dynamics The forces and moments at each wheel while the vehicle brakes, turns and changes lane.
-
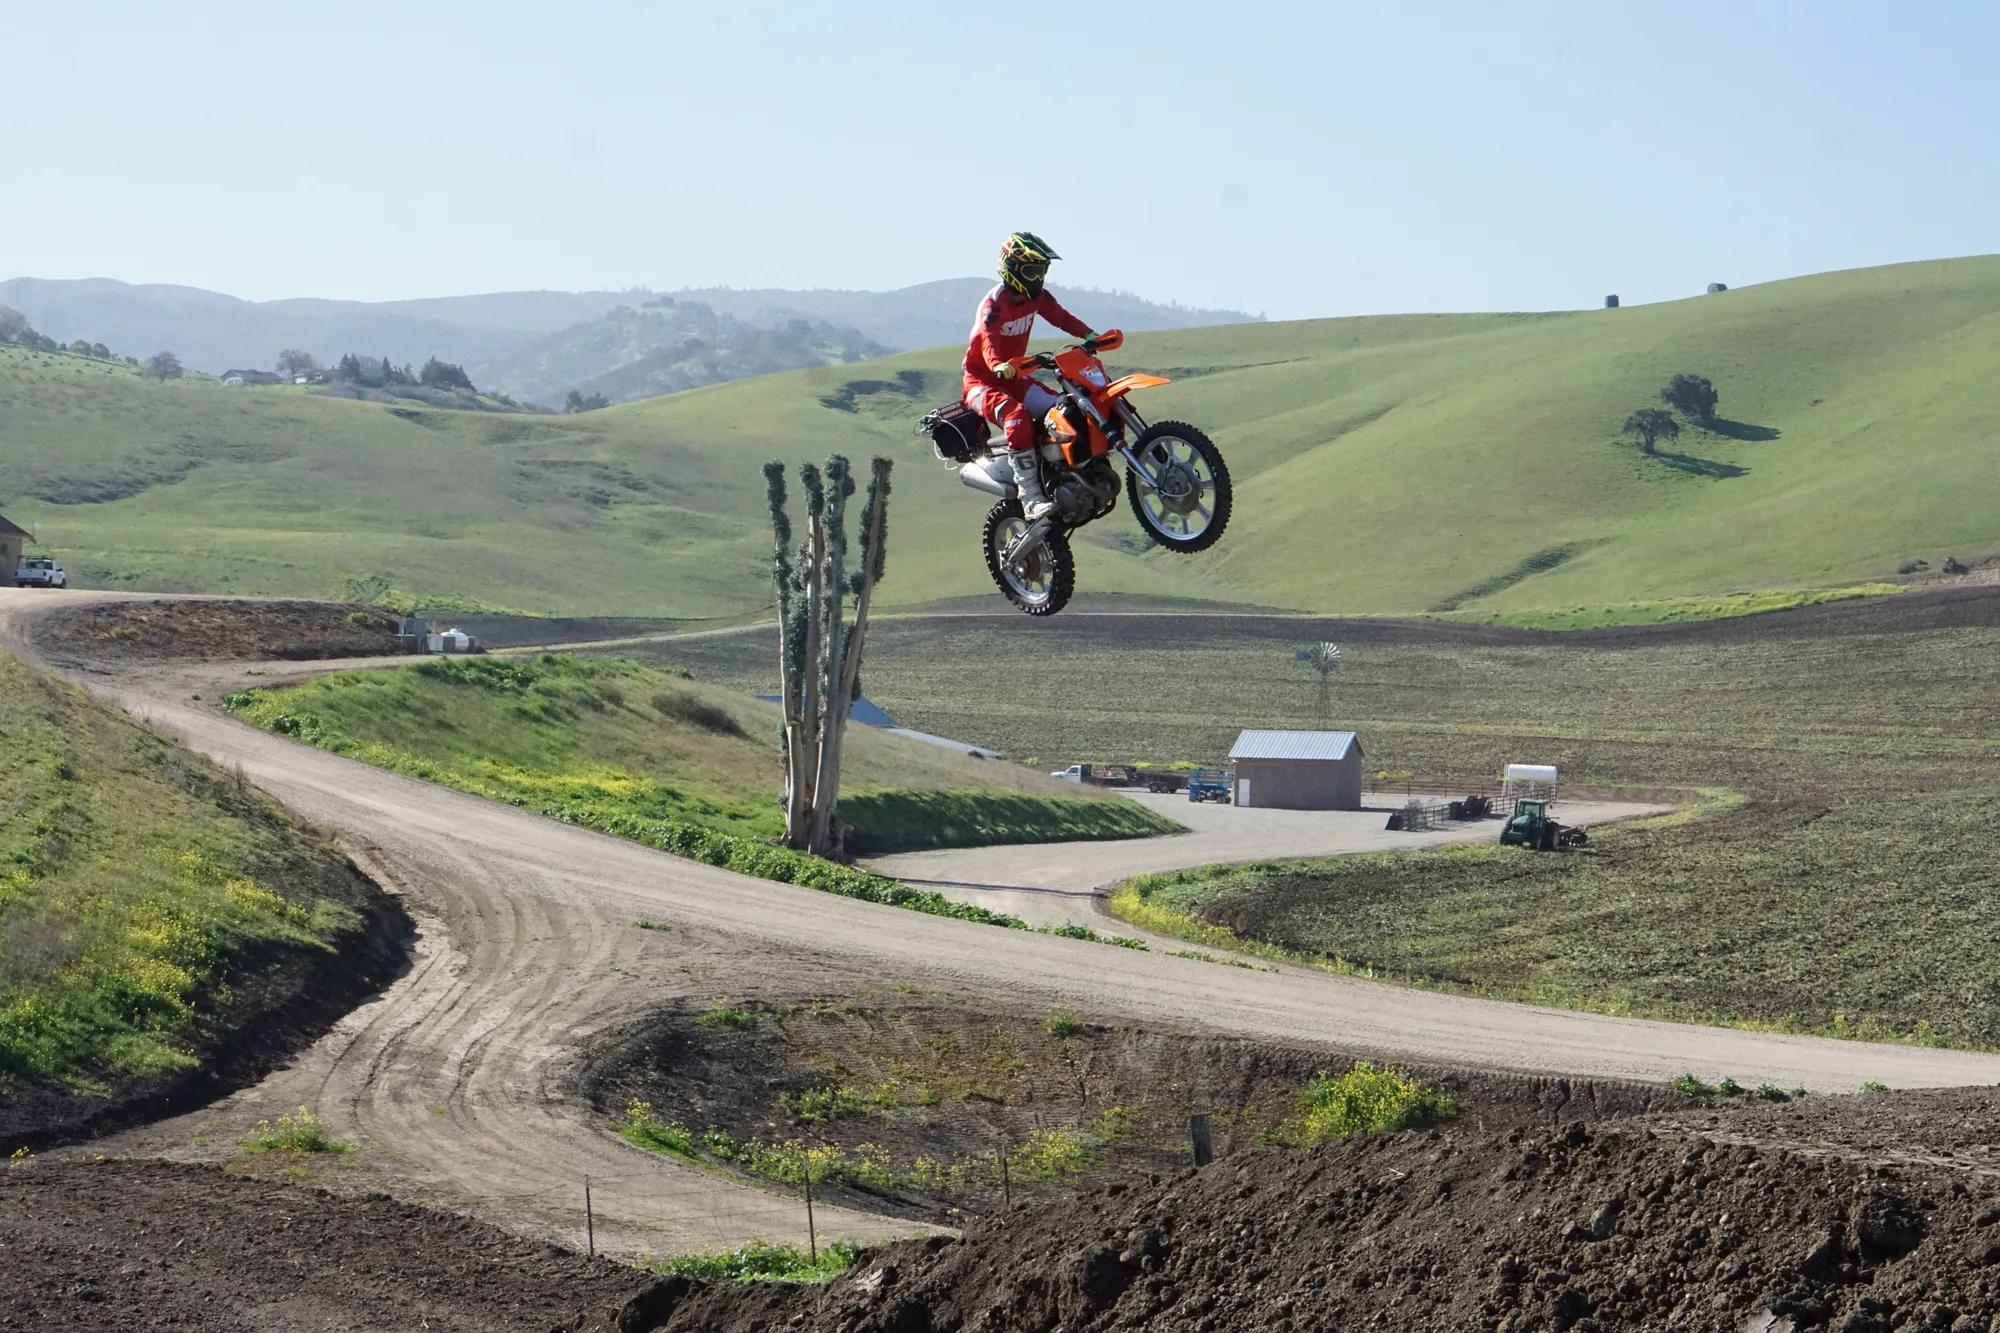 Durability Durability campaigns The load each wheel really sees on a pothole, an obstacle or a rough track, as recorded data.
-
 Dynamics Side slip angle Side slip angle read without contact by an optical sensor, on a wheel or on the vehicle body.
If the LW9.5 is not the one
- Torque only Wheel torque transducers
Drive and brake torque at the wheel, while the vehicle is driven.
- Signals from the series wheel Wheel Instrumentation System
Strain gage and thermocouple signals off a rotating wheel, on the vehicle's own wheel, on track or off-road.
- Force on a part, not a wheel TR3D-B
Three perpendicular forces from a square body, down to 25.4 mm a side.
A question on this product?
Vehicle, wheel size, expected loads. An application engineer answers.
More details to give? Use the full contact form.