SW-SR2 steering wheel torque and angle transducer
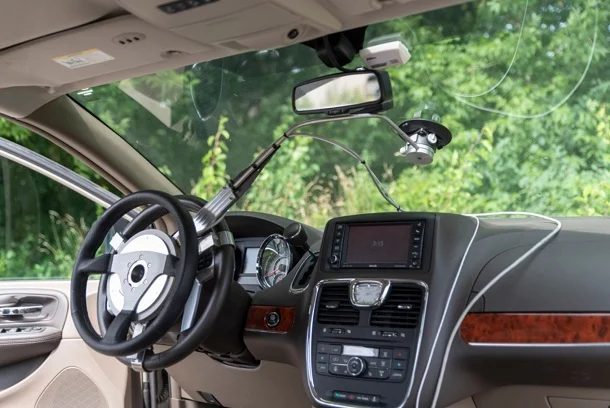
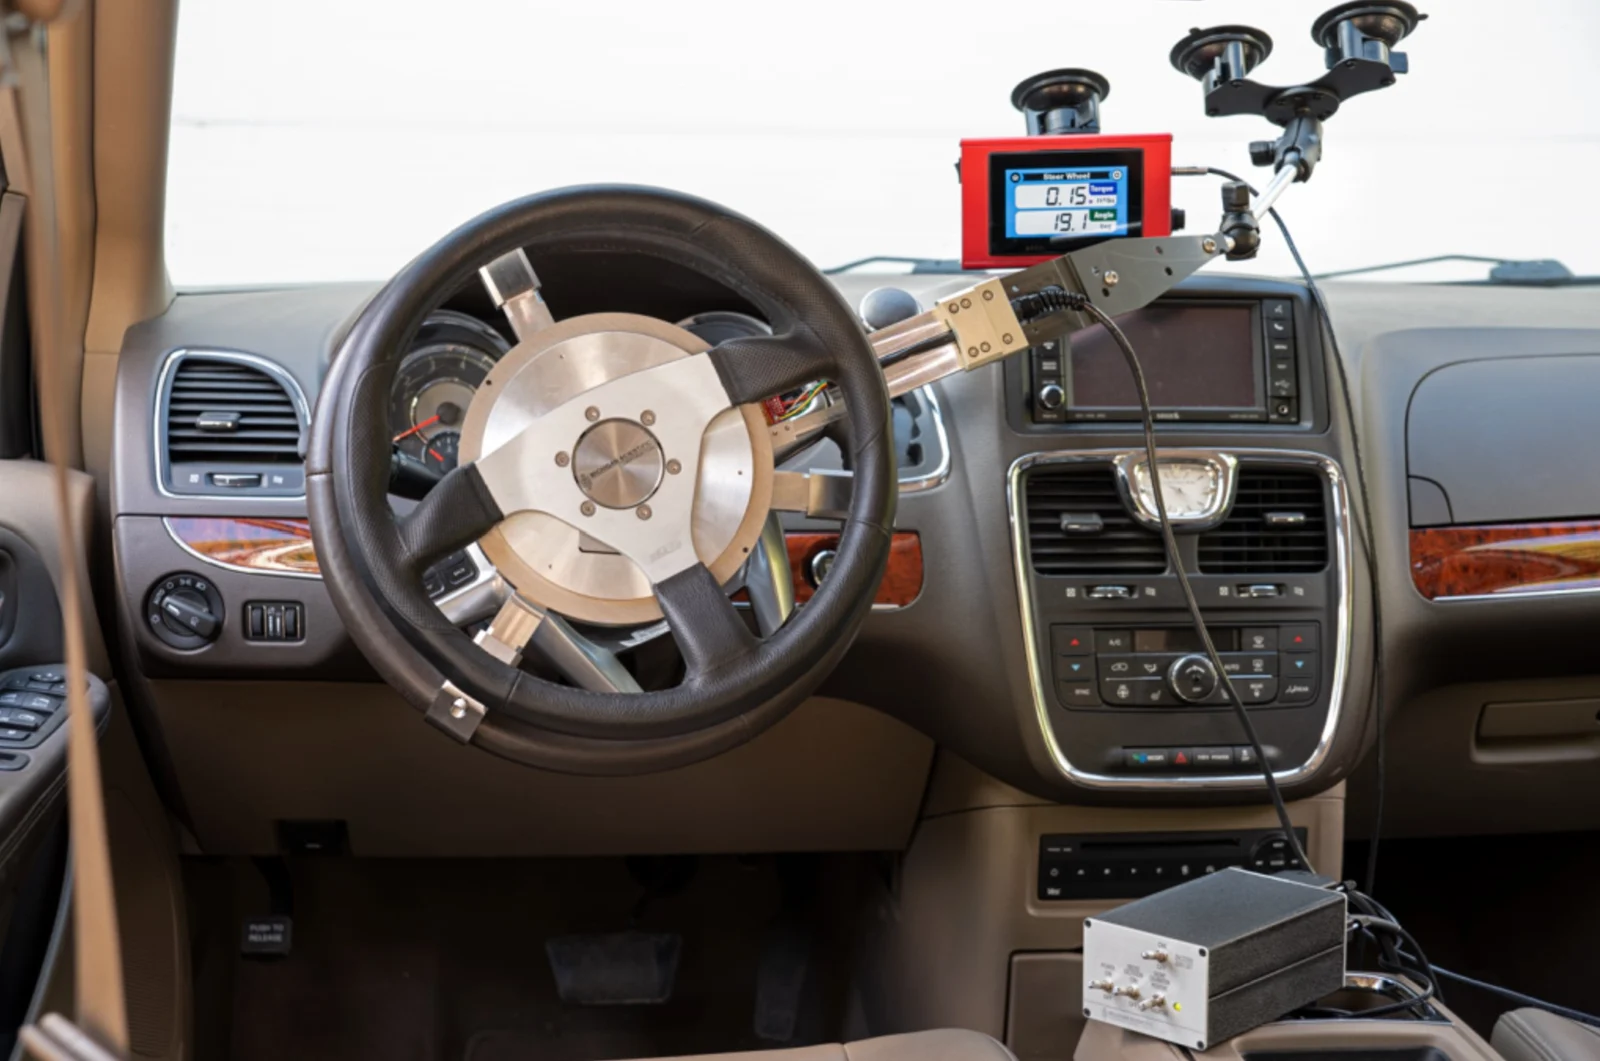
Steering wheel torque and angle transducer, 100, 200 or 300 N·m, with a ±1 440° multi-turn encoder and a slip ring, mounted on the steering wheel or shaft.
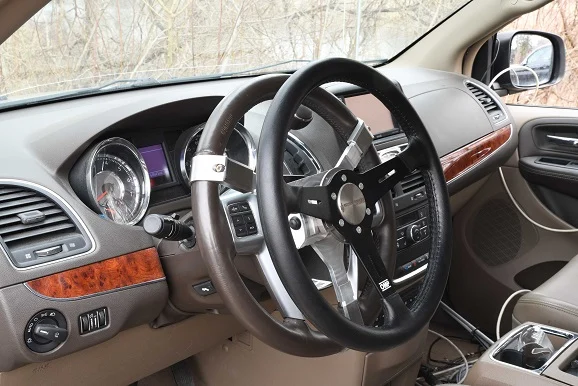
Steering wheel torque transducer, 135 N·m, with battery-powered wireless telemetry and no position restraint, on the bolt patterns of common racing steering wheels.
- 100 · 200 · 300 N·m
- Torque ranges
- ± 1 440°
- Steering angle
- 0.04°
- Angle resolution
- ± 10 V · CAN 2.0
- Outputs
- 135 N·m
- Torque capacity
- 300 %
- Overload
- battery-powered telemetry
- Transmission
- < 0.5 % FS
- Torque non-linearity
- Torque non-linearity< 0.25 % FS
- Weight, transducer and slip ring electronics4.0 kg
- Torque non-linearity< 0.25 % FS
- Steering angle± 1 440°
- Weight, transducer and slip ring electronics4.0 kg
Steering wheel torque and angle, through a slip ring
The SW-SR2 measures steering effort torque, steering wheel angle and steering rate. Torque comes from a full-bridge strain gage sensor in high-strength stainless steel, rated 100, 200 or 300 N·m, temperature compensated from 24 to 85 °C, with non-linearity below 0.25 % of full scale. Angle comes from a high-resolution inductive encoder over ±1 440°, with 0.04° resolution and 0.18° accuracy. A Michigan Scientific slip ring carries the signals to the DIGI-STEER electronics box, which outputs torque and angle at ±10 V and on CAN 2.0, and steering rate on CAN only. The assembly weighs 4.0 kg and operates from −40 to 85 °C.
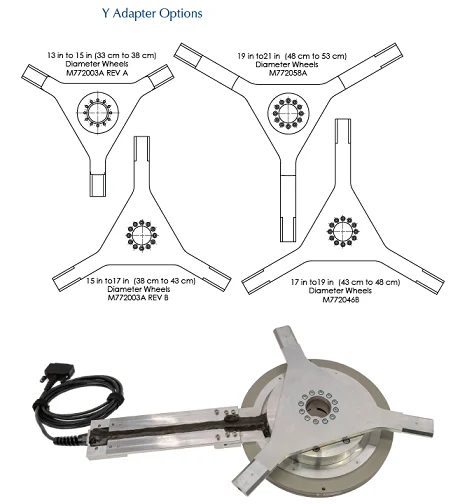
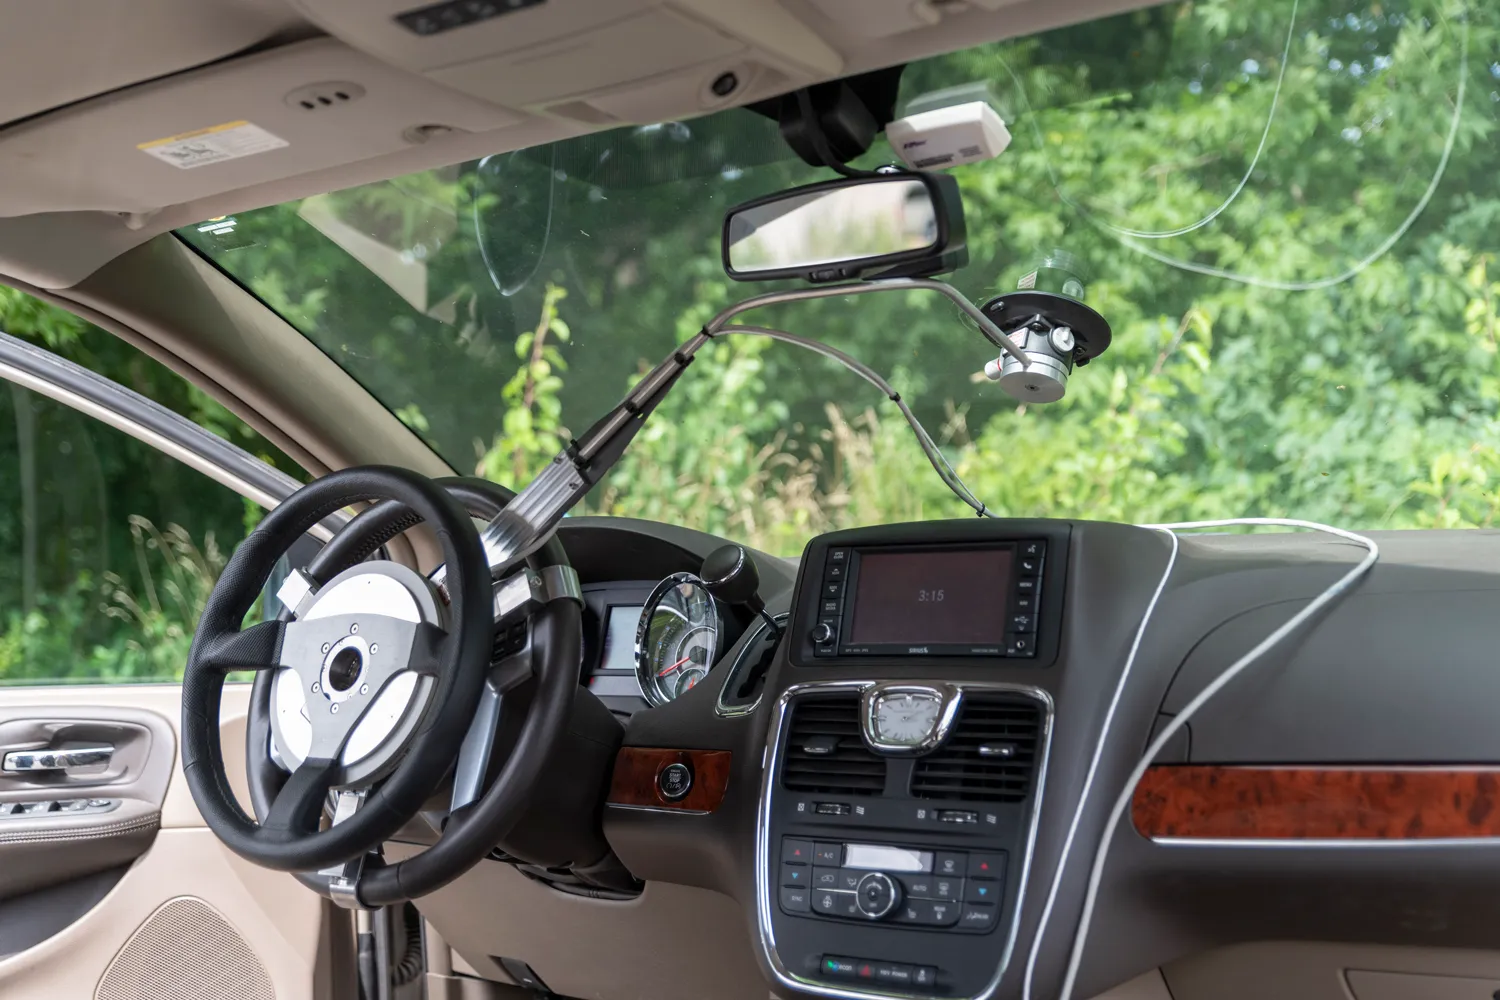
The driver turns an aftermarket steering wheel bolted to the top of the transducer. The base either clamps onto the production steering wheel with three clamp hooks on a Y adapter, sized for wheels of 13 to 21 in, or bolts to a spline adapter on the steering shaft once the production wheel is removed; the airbag is disabled first. The encoder stator is held by an anti-rotation bracket on a suction cup on the windshield. The DIGI-STEER unit takes 10 to 36 V DC and has switches for torque zero, shunt calibration and encoder zero; a .dbc file scales the CAN outputs.
It is used to develop and verify steering systems, in the laboratory and in normal driving, and with tie rod load measurements on the same run to relate the driver input to the loads in the steering linkage.
Steering wheel torque, by telemetry
The SW-TEL measures steering effort torque; it does not measure steering angle. The transducer is a strain gage sensor in high-grade stainless steel, rated 135 N·m (100 lbf·ft) with a 300 % overload, temperature compensated from 24 to 85 °C, with non-linearity and hysteresis below 0.5 % of full scale. It takes an axial load of 4.4 kN at the wheel center and 440 N at the wheel edge. A battery-powered telemetry package transmits the torque, output as an analog ±10 V signal. It operates from −40 to 125 °C and is protected to IP54.
The SW-TEL mounts to the steering wheel or to the steering shaft and uses the same bolt patterns as common racing steering wheels, for steering wheels of 13 to 15 in. It has no position restraint, so nothing is fixed to the windshield or dashboard. The airbag is disabled while it is fitted, and the mounting bracket may block some buttons on the steering wheel. When the steering angle is also needed, the slip ring version, the SW-SR2, is used.
It is designed for in-vehicle testing and measures steering wheel torque on any vehicle, with normal steering function maintained.
Specifications
| Torque capacity | 100 · 200 · 300 N·m |
|---|---|
| Angle range | 1 440° (each way) |
| Non-linearity | ≤ 0.25 % FS |
| Angle resolution | 0.04° |
| Sensing principle | Strain gage (full bridge) |
| Angle accuracy | ≤ 0.18° |
| Output | Analog voltage · CAN (CAN 2.0) |
| Output range | −10 to 10 V |
| Safe axial load, wheel edge | 440 N |
| Weight | 4 kg (transducer and slip ring electronics) |
| Operating temperature | −40 to 85 °C |
| Compensated temperature | 24 to 85 °C |
| Torque capacity | 135 N·m |
|---|---|
| Overload capacity | 300 % |
| Non-linearity | ≤ 0.5 % FS |
| Hysteresis | ≤ 0.5 % FS |
| Sensing principle | Strain gage |
| Output | Analog voltage |
| Output range | −10 to 10 V |
| Signal transmission | Telemetry |
| Power source | Battery |
| Safe axial load, wheel centre | 4 400 N |
| Safe axial load, wheel edge | 440 N |
| Weight | 4 kg |
| Operating temperature | −40 to 125 °C |
| Compensated temperature | 24 to 85 °C |
| Protection | IP54 |
| Steering wheel diameter | 330.2 to 381 mm (13 to 15 in) |
Request a quote
Resources
Datasheets and manuals
Drawings
None for SW-SR2.
CAD models
None for SW-SR2.
Datasheets and manuals
Drawings
None for SW-TEL.
CAD models
None for SW-TEL.
Related applications
Next to the steering wheel
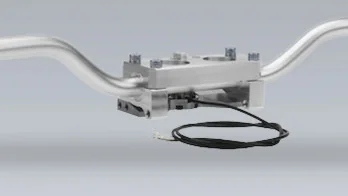
- Motorcycle handlebar Model HBT
Steering torque and angle on a handlebar.
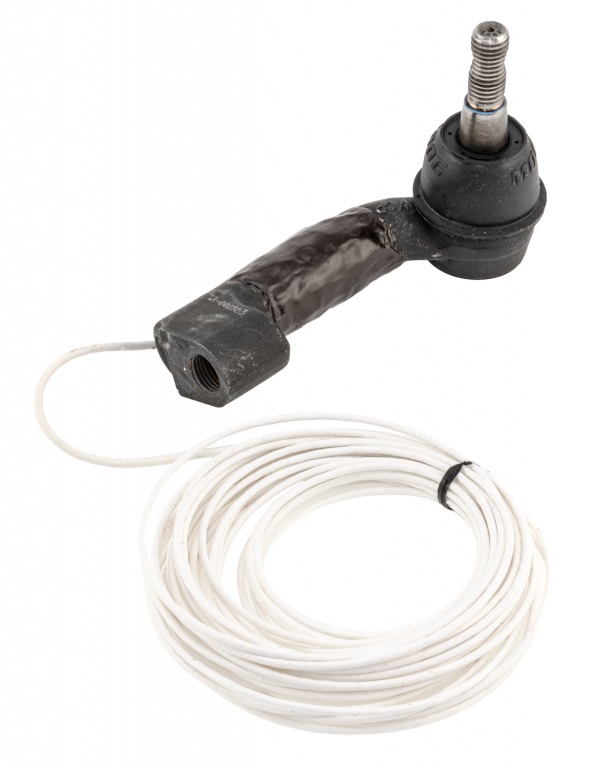
- Loads in the tie rod Custom transducers
The tie rod itself, strain gaged and calibrated.
- Forces at the tire LW series wheel force transducers
Six components at the wheel center.
A question on this product?
Vehicle, steering wheel diameter, expected torque. An application engineer answers.
More details to give? Use the full contact form.