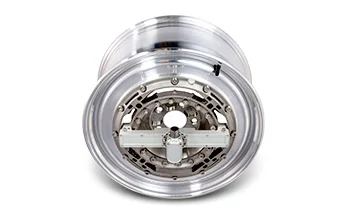
Michigan Scientific · wheel force transducer
LW series wheel force transducers
Three forces and three moments at the wheel center, in real driving conditions.
For: motorcycle. LW-MC-3.5K: Datasheet PDF
For: motorcycle and car. LW25: Datasheet PDF
For: ATV and small vehicle. LW9.5: Datasheet PDF
For: passenger car and SUV. LW12.8-50: Datasheet PDF
For: cars and light duty trucks, telemetry. LW12.8-50-TEL: Datasheet PDF
For: passenger car and SUV. LW50: Datasheet PDF
For: car and SUV. LW12.8-60: Datasheet PDF
For: car and SUV. LW60: Datasheet PDF
For: car and SUV. LW65: Datasheet PDF
For: heavy SUV and pick-up truck. LW-2T-20K: Datasheet PDF
For: forklift and construction equipment. LW9.5-HS: Datasheet PDF
For: medium duty vehicle. LW-2T-30K: Datasheet PDF
For: class 8 trucks. LW150: Datasheet PDF
For: very heavy vehicles, hubs with a 425 mm bolt circle. LW700: Datasheet PDF
For: forklift and heavy duty trucks. LW-2T-40K: Datasheet PDF
For: heavy duty. LW-2T-50K: Datasheet PDF
For: class 8 trucks. LW-2T-60K-S: Datasheet PDF
For: class 8 trucks and tractors. LW-2T-100K-S: Datasheet PDF
For: heavy trucks and construction equipment. LW-2T-100K: Datasheet PDF
- 15.5 kN
- Fx, Fz capacity
- 5.3 kN
- Fy capacity
- 1.6 / 3.4 kN·m
- Moment capacity
- < 1 % FS
- Non-linearity
- 25 kN
- Fx, Fz capacity
- 8.9 kN
- Fy capacity
- 3.4 kN·m
- Moment capacity
- ≤ 0.25 % FS (forces, My)
- Non-linearity
- 35.6 kN
- Fx, Fz capacity
- 17.8 kN
- Fy capacity
- 5.4 kN·m
- Moment capacity
- ≤ 0.25 % FS
- Non-linearity
- 50 kN
- Fx, Fz capacity
- 25 kN
- Fy capacity
- 6.5 kN·m
- Moment capacity
- ≤ 0.2 % FS (Fx, Fz)
- Non-linearity
- 50 kN
- Fx, Fz capacity
- 25 kN
- Fy capacity
- 6.5 kN·m
- Moment capacity
- ≤ 0.2 % FS (Fx, Fz)
- Non-linearity
- 50 kN
- Fx, Fz capacity
- 25 kN
- Fy capacity
- 6.5 kN·m
- Moment capacity
- ≤ 0.25 % FS
- Non-linearity
- 60 kN
- Fx, Fz capacity
- 30 kN
- Fy capacity
- 9 kN·m
- Moment capacity
- ± 0.5 % FS
- Non-linearity
- 60 kN
- Fx, Fz capacity
- 35 kN
- Fy capacity
- 9 kN·m
- Moment capacity
- ≤ 0.25 % FS
- Non-linearity
- 65 kN
- Fx, Fz capacity
- 35 kN
- Fy capacity
- 10.5 kN·m
- Moment capacity
- ≤ 0.2 % FS (forces, My)
- Non-linearity
- 90 kN
- Fx, Fz capacity
- 45 kN
- Fy capacity
- 15 / 20 kN·m
- Moment capacity
- ≤ 0.5 % FS
- Non-linearity
- 93 kN
- Fx, Fz capacity
- 45 kN
- Fy capacity
- 9.5 kN·m
- Moment capacity
- < 1 % FS
- Non-linearity
- 133 kN
- Fx, Fz capacity
- 66 kN
- Fy capacity
- 30 kN·m
- Moment capacity
- ≤ 0.5 % FS (Fx, Fz)
- Non-linearity
- 150 kN
- Fx, Fz capacity
- 75 kN
- Fy capacity
- 40 kN·m
- Moment capacity
- ≤ 0.5 % FS
- Non-linearity
- 700 kN
- Fx, Fz capacity
- 700 kN
- Fy capacity
- 275 kN·m
- Moment capacity
- ≤ 0.5 % FS
- Non-linearity
- 178 kN
- Fx, Fz capacity
- 89 kN
- Fy capacity
- 40 kN·m
- Moment capacity
- ≤ 0.5 % FS (Fx, Fz)
- Non-linearity
- 222 kN
- Fx, Fz capacity
- 111 kN
- Fy capacity
- 68 kN·m
- Moment capacity
- ± 1 % FS
- Non-linearity
- 300 kN
- Fx, Fz capacity
- 150 kN
- Fy capacity
- 81 kN·m
- Moment capacity
- ± 1 % FS
- Non-linearity
- 445 kN
- Fx, Fz capacity
- 222 kN
- Fy capacity
- 108 kN·m
- Moment capacity
- ± 1 % FS
- Non-linearity
- 445 kN
- Fx, Fz capacity
- 225 kN
- Fy capacity
- 135 kN·m
- Moment capacity
- ± 1 % FS
- Non-linearity
- OutputsFx Fy Fz · Mx My Mz
- Also measuredX and Z acceleration · wheel speed and angle
- Signal outputanalog · CAN
- Signal transmissionslip ring or telemetry
01 · The essential
All the wheel loads, one transducer
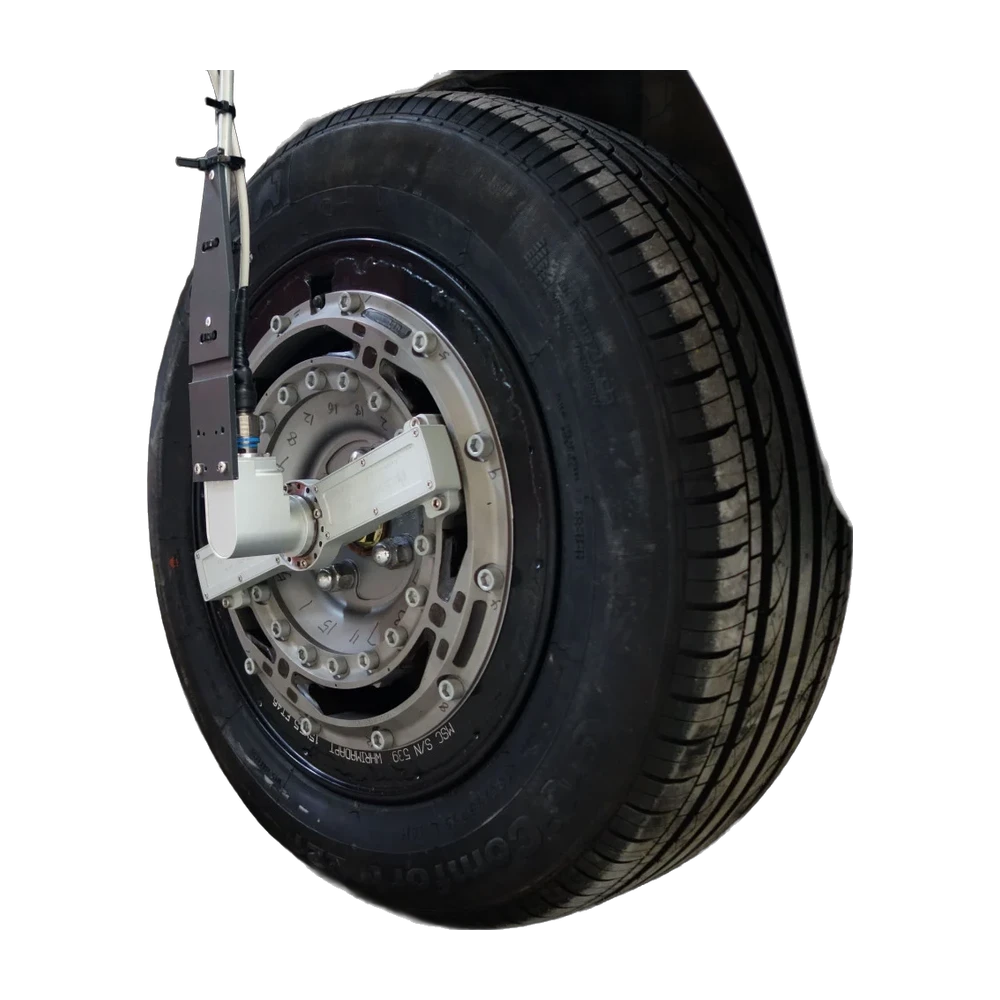
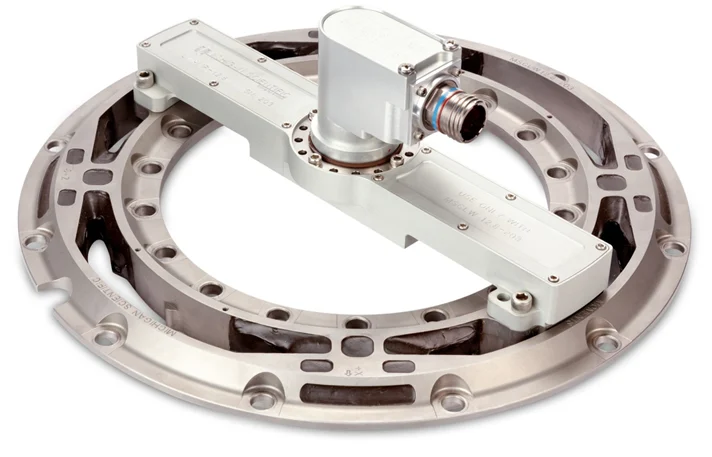
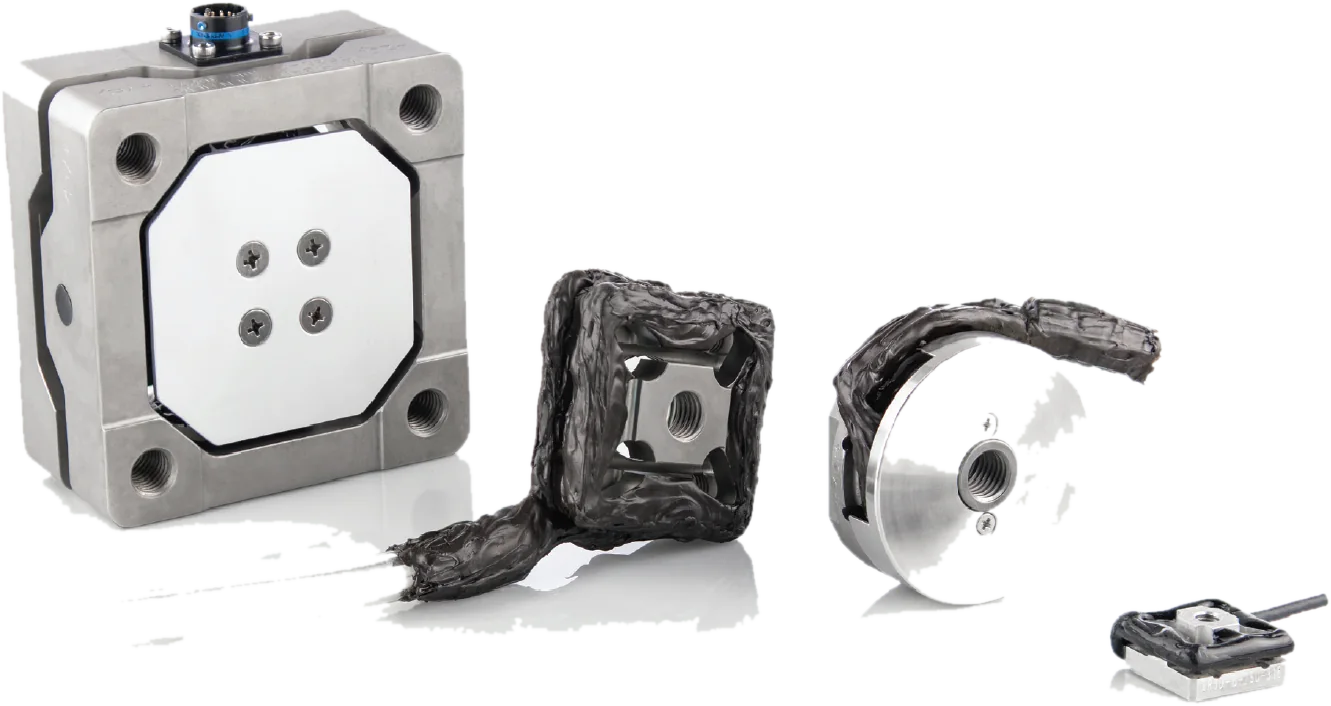
An LW transducer replaces the wheel center and gives independent signals for vertical, lateral and longitudinal force and for camber, steer and torque moments. It also outputs X and Z acceleration, wheel speed and wheel angle.
Stainless steel and weatherproof sealing make it fit for the road; temperature compensation keeps the output stable over a wide range. The same transducer mounts on a test rig through flanges or hubs, spinning or not.
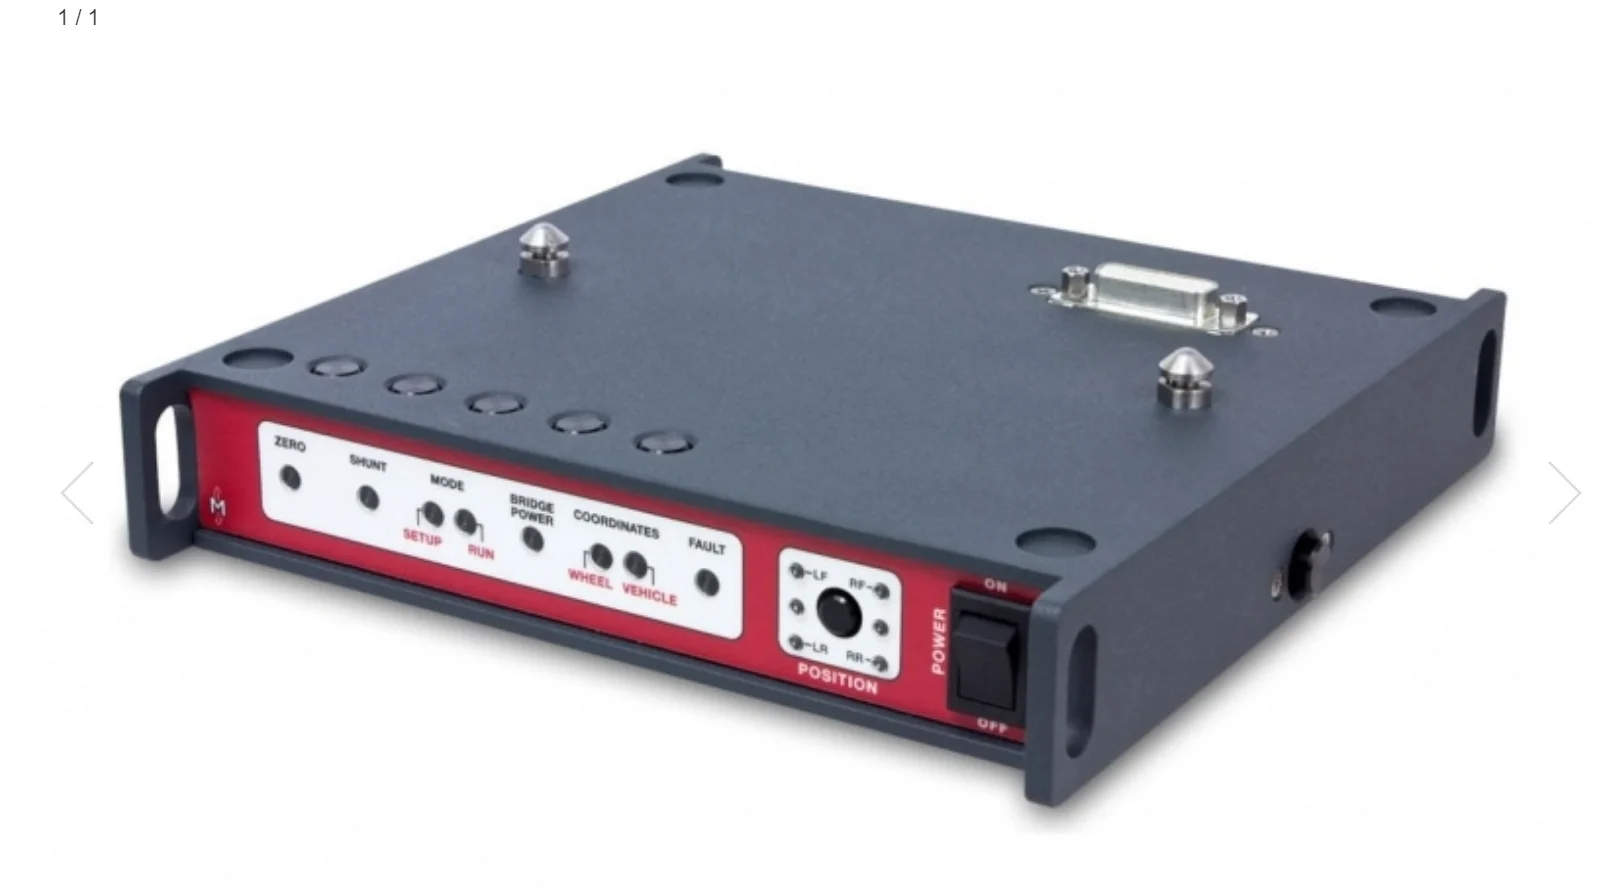
The signals are amplified on the transducer, leave the wheel through a slip ring or telemetry, and reach the CT2 interface box, which does the coordinate transformation and crosstalk compensation in real time. Setup is done in a web browser.
02 · Specifications
The numbers
| Vehicle | Motorcycle |
|---|---|
| Fx, Fz capacity | 15.5 kN |
| Fy capacity | 5.3 kN |
| Moment capacity | 1.6 / 3.4 kN·m |
| Non-linearity | < 1 % FS |
| Hysteresis | ≤ 0.5 % FS |
| Cross Axis Sensitivity after correction | < 1 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.25° |
| Weight | 2.25 kg, with telemetry electronics |
| Supply voltage | 10 to 36 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 25 kN |
|---|---|
| Fy capacity | 8.9 kN |
| Maximum recommended static weight | 550 kg |
| Maximum Torque Capacity [Mx, Mz] | 2.0 kN·m |
| Maximum Torque Capacity [My] | 3.4 kN·m |
| Accelerometer range | 100 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ≤ 0.25 % FS (Fx, Fy, Fz, My) · ≤ 0.5 % FS (Mx, Mz) |
| Hysteresis | ≤ 0.25 % FS |
| Cross Axis Sensitivity after correction | ≤ 0.4 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° (slip ring) · 0.25° (telemetry) |
| Vehicle | Motorcycle, ATV, small car |
| Analog output | 0-10 V DC |
| Supply voltage | 10 V DC |
| Weight | 1.5 kg |
| Axes | 6 Axis |
| Vehicle | ATV, utility and small vehicles |
|---|---|
| Fx, Fz capacity | 35.6 kN |
| Fy capacity | 17.8 kN |
| Moment capacity | 5.4 kN·m |
| Accelerometer range | 55 g |
| Non-linearity | ≤ 0.25 % FS |
| Hysteresis | < 0.5 % FS |
| Cross Axis Sensitivity after correction | < 1 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Wheel size | 10 in and larger |
| Analog output | 0-10 V DC |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 50 kN |
|---|---|
| Fy capacity | 25 kN |
| Maximum Torque Capacity [Mx, My, Mz] | 6.5 kN·m |
| Accelerometer range | 55 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ≤ 0.2 % FS (Fx, Fz, My) · ≤ 0.5 % FS (Fy) · ≤ 1.0 % FS (Mx, Mz) |
| Hysteresis | < 1.0 % FS |
| Cross Axis Sensitivity after correction | < 0.5 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Wheel size | 12 in and larger |
| Weight | 4.7 kg |
| Vehicle | Automotive - LD veh. |
| Moment capacity | 6.5 kN·m |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 50 kN |
|---|---|
| Fy capacity | 25 kN |
| Maximum Torque Capacity [Mx, My, Mz] | 6.5 kN·m |
| Accelerometer range | 55 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ≤ 0.2 % FS (Fx, Fz, My) · ≤ 0.5 % FS (Fy) · ≤ 1.0 % FS (Mx, Mz) |
| Hysteresis | < 1.0 % FS |
| Cross Axis Sensitivity before compensation | < 1 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.25° |
| Wheel size | 14 in and larger |
| Weight | 6 kg |
| Vehicle | Automotive - LD veh. |
| Moment capacity | 6.5 kN·m |
| Supply voltage | 10 to 36 V DC |
| Axes | 6 Axis |
| Vehicle | Automotive - LD veh. |
|---|---|
| Fx, Fz capacity | 50 kN |
| Fy capacity | 25 kN |
| Maximum recommended static weight | 1 020 kg |
| Moment capacity | 6.5 kN·m |
| Accelerometer range | 100 g |
| Non-linearity | ≤ 0.25 % FS |
| Hysteresis | ≤ 0.25 % FS |
| Cross Axis Sensitivity after correction | ≤ 0.4 % FS |
| Analog output | 0-10 V DC, 0-5 V DC, ± 5 V DC, ± 10 V DC |
| Operating temperature | −40 to 177 °C |
| Angular Resolution | 0.17° |
| Weight | 4.4 kg |
| Axes | 6 Axis |
| Fx, Fz capacity | 60 kN |
|---|---|
| Fy capacity | 30 kN |
| Maximum Torque Capacity [Mx, My, Mz] | 9.0 kN·m |
| Accelerometer range | 55 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ± 0.5 % FS |
| Hysteresis | < 0.5 % FS |
| Cross Axis Sensitivity after correction | < 0.5 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Vehicle | Automotive - LD veh. |
| Moment capacity | 9 kN·m |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 60 kN |
|---|---|
| Fy capacity | 35 kN |
| Maximum recommended static weight | 1 225 kg |
| Maximum Torque Capacity [Mx, My, Mz] | 8 kN·m / 9 kN·m / 8 kN·m |
| Accelerometer range | 100 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ≤ 0.25 % FS |
| Hysteresis | ≤ 0.25 % FS |
| Cross Axis Sensitivity after correction | ≤ 0.4 % FS |
| Operating temperature | −40 to 177 °C |
| Angular Resolution | 0.17° |
| Weight | 5.7 kg |
| Vehicle | Automotive - LD veh. |
| Analog output | 0-10 V DC |
| Supply voltage | 10 V DC |
| Moment capacity | 9 kN·m |
| Axes | 6 Axis |
| Fx, Fz capacity | 65 kN |
|---|---|
| Fy capacity | 35 kN |
| Maximum recommended static weight | 1 320 kg |
| Maximum Torque Capacity [Mx, My, Mz] | 10.5 kN·m |
| Accelerometer range | 100 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ≤ 0.2 % FS (Fx, Fy, Fz, My) · ≤ 0.4 % FS (Mx, Mz) |
| Hysteresis | ≤ 0.25 % FS (Fx, Fz, My) · ≤ 0.45 % FS (Fy, Mx, Mz) |
| Cross Axis Sensitivity after correction | ≤ 0.4 % FS |
| Operating temperature | −40 to 177 °C |
| Angular Resolution | 0.17° |
| Vehicle | Automotive - LD veh. |
| Moment capacity | 10.5 kN·m |
| Analog output | 0-10 V DC |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 90 kN |
|---|---|
| Fy capacity | 45 kN |
| Maximum Torque Capacity [Mx, My, Mz] | 15 kN·m (Mx, Mz) · 20 kN·m (My) |
| Accelerometer range | +/- 55 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ≤ 0.5 % FS |
| Hysteresis | < 0.5 % FS |
| Cross Axis Sensitivity after correction | < 1 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Vehicle | Forklift - Truck - Bus |
| Moment capacity | 15 / 20 kN·m |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Vehicle | Forklift - Truck - Bus |
|---|---|
| Fx, Fz capacity | 93 kN |
| Fy capacity | 45 kN |
| Moment capacity | 9.5 kN·m |
| Accelerometer range | 55 g |
| Non-linearity | < 1 % FS |
| Hysteresis | < 0.5 % FS |
| Cross Axis Sensitivity after correction | < 0.5 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Wheel size | 10 in and larger |
| Analog output | 0-10 V DC |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 133 kN |
|---|---|
| Fy capacity | 66 kN |
| Maximum Torque Capacity [Mx, My, Mz] | 30 kN·m |
| Accelerometer range | +/- 55 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ≤ 0.5 % FS (Fx, Fz, My) · ≤ 0.75 % FS (Fy, Mx, Mz) |
| Hysteresis | < 0.5 % FS |
| Cross Axis Sensitivity after correction | < 0.5 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Wheel size | 15 in and larger, single or dual |
| Hub bolt pattern | 265 mm diameter and smaller |
| Weight | 10 kg |
| Vehicle | Forklift - Truck - Bus |
| Moment capacity | 30 kN·m |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 150 kN |
|---|---|
| Fy capacity | 75 kN |
| Moment capacity | 40 kN·m |
| Maximum recommended static weight | 4 400 kg |
| Maximum Torque Capacity [Mx, My, Mz] | 40 kN·m |
| Accelerometer range | 100 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ≤ 0.5 % FS |
| Hysteresis | ≤ 0.5 % FS |
| Cross Axis Sensitivity after correction | ≤ 1 % FS |
| Operating temperature | −40 to 177 °C |
| Angular Resolution | 0.17° |
| Weight | 20.9 kg |
| Vehicle | Heavy-duty - Tractor |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 700 kN |
|---|---|
| Fy capacity | 700 kN |
| Maximum recommended static weight | 23 800 kg |
| Moment capacity | 275 kN·m |
| Maximum Torque Capacity [Mx, My, Mz] | 275 kN·m |
| Accelerometer range | 100 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ≤ 0.5 % FS |
| Hysteresis | ≤ 0.5 % FS |
| Cross Axis Sensitivity after correction | ≤ 0.2 % FS |
| Operating temperature | −40 to 177 °C |
| Angular Resolution | 0.17° |
| Weight | 64.5 kg |
| Vehicle | Heavy-duty - Tractor |
| Supply voltage | 10 V DC |
| Protection | IP67 |
| Hub bolt pattern | 425 mm bolt circle, standard hubs |
| Axes | 6 Axis |
| Fx, Fz capacity | 178 kN |
|---|---|
| Fy capacity | 89 kN |
| Maximum Torque Capacity [Mx, My, Mz] | 40 kN·m |
| Accelerometer range | +/- 55 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ≤ 0.5 % FS (Fx, Fz, My) · ≤ 0.75 % FS (Mx, Mz) · ≤ 1.5 % FS (Fy) |
| Hysteresis | < 0.5 % FS |
| Cross Axis Sensitivity after correction | < 0.5 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Wheel size | 15 in and larger, single or dual |
| Hub bolt pattern | 265 mm diameter and smaller |
| Weight | 10 kg |
| Vehicle | Heavy-duty - Tractor |
| Moment capacity | 40 kN·m |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 222 kN |
|---|---|
| Fy capacity | 111 kN |
| Maximum Torque Capacity [Mx, My, Mz] | 68 kN·m |
| Accelerometer range | 55 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ± 1 % FS |
| Hysteresis | < 1 % FS |
| Cross Axis Sensitivity after correction | < 1 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Weight | 16.1 Kg |
| Vehicle | Heavy-duty - Tractor |
| Moment capacity | 68 kN·m |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 300 kN |
|---|---|
| Fy capacity | 150 kN |
| Maximum Torque Capacity [Mx, My, Mz] | 81 kN·m |
| Accelerometer range | 55 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ± 1 % FS |
| Hysteresis | < 0.5 % FS |
| Cross Axis Sensitivity after correction | < 1 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Wheel size | 20 in and larger |
| Weight | 26 kg |
| Vehicle | Heavy-duty - Tractor |
| Moment capacity | 81 kN·m |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 445 kN |
|---|---|
| Fy capacity | 222 kN |
| Maximum Torque Capacity [Mx, My, Mz] | 108 kN·m |
| Accelerometer range | +/- 55 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ± 1 % FS |
| Hysteresis | < 0.5 % FS |
| Cross Axis Sensitivity after correction | < 1 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Wheel size | 20 in and larger |
| Weight | 26 kg |
| Vehicle | Heavy-duty - Tractor |
| Moment capacity | 108 kN·m |
| Analog output | 0-10 V DC |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
| Fx, Fz capacity | 445 kN |
|---|---|
| Fy capacity | 225 kN |
| Maximum Torque Capacity [Mx, My, Mz] | 135 kN·m |
| Accelerometer range | +/- 55 g |
| Sensor | 4 arm strain gage bridges |
| Non-linearity | ± 1 % FS |
| Hysteresis | < 0.5 % FS |
| Cross Axis Sensitivity after correction | < 1 % FS |
| Operating temperature | −40 to 125 °C |
| Angular Resolution | 0.17° |
| Vehicle | Heavy-duty - Tractor |
| Moment capacity | 135 kN·m |
| Supply voltage | 10 V DC |
| Axes | 6 Axis |
No 3D model for this version.
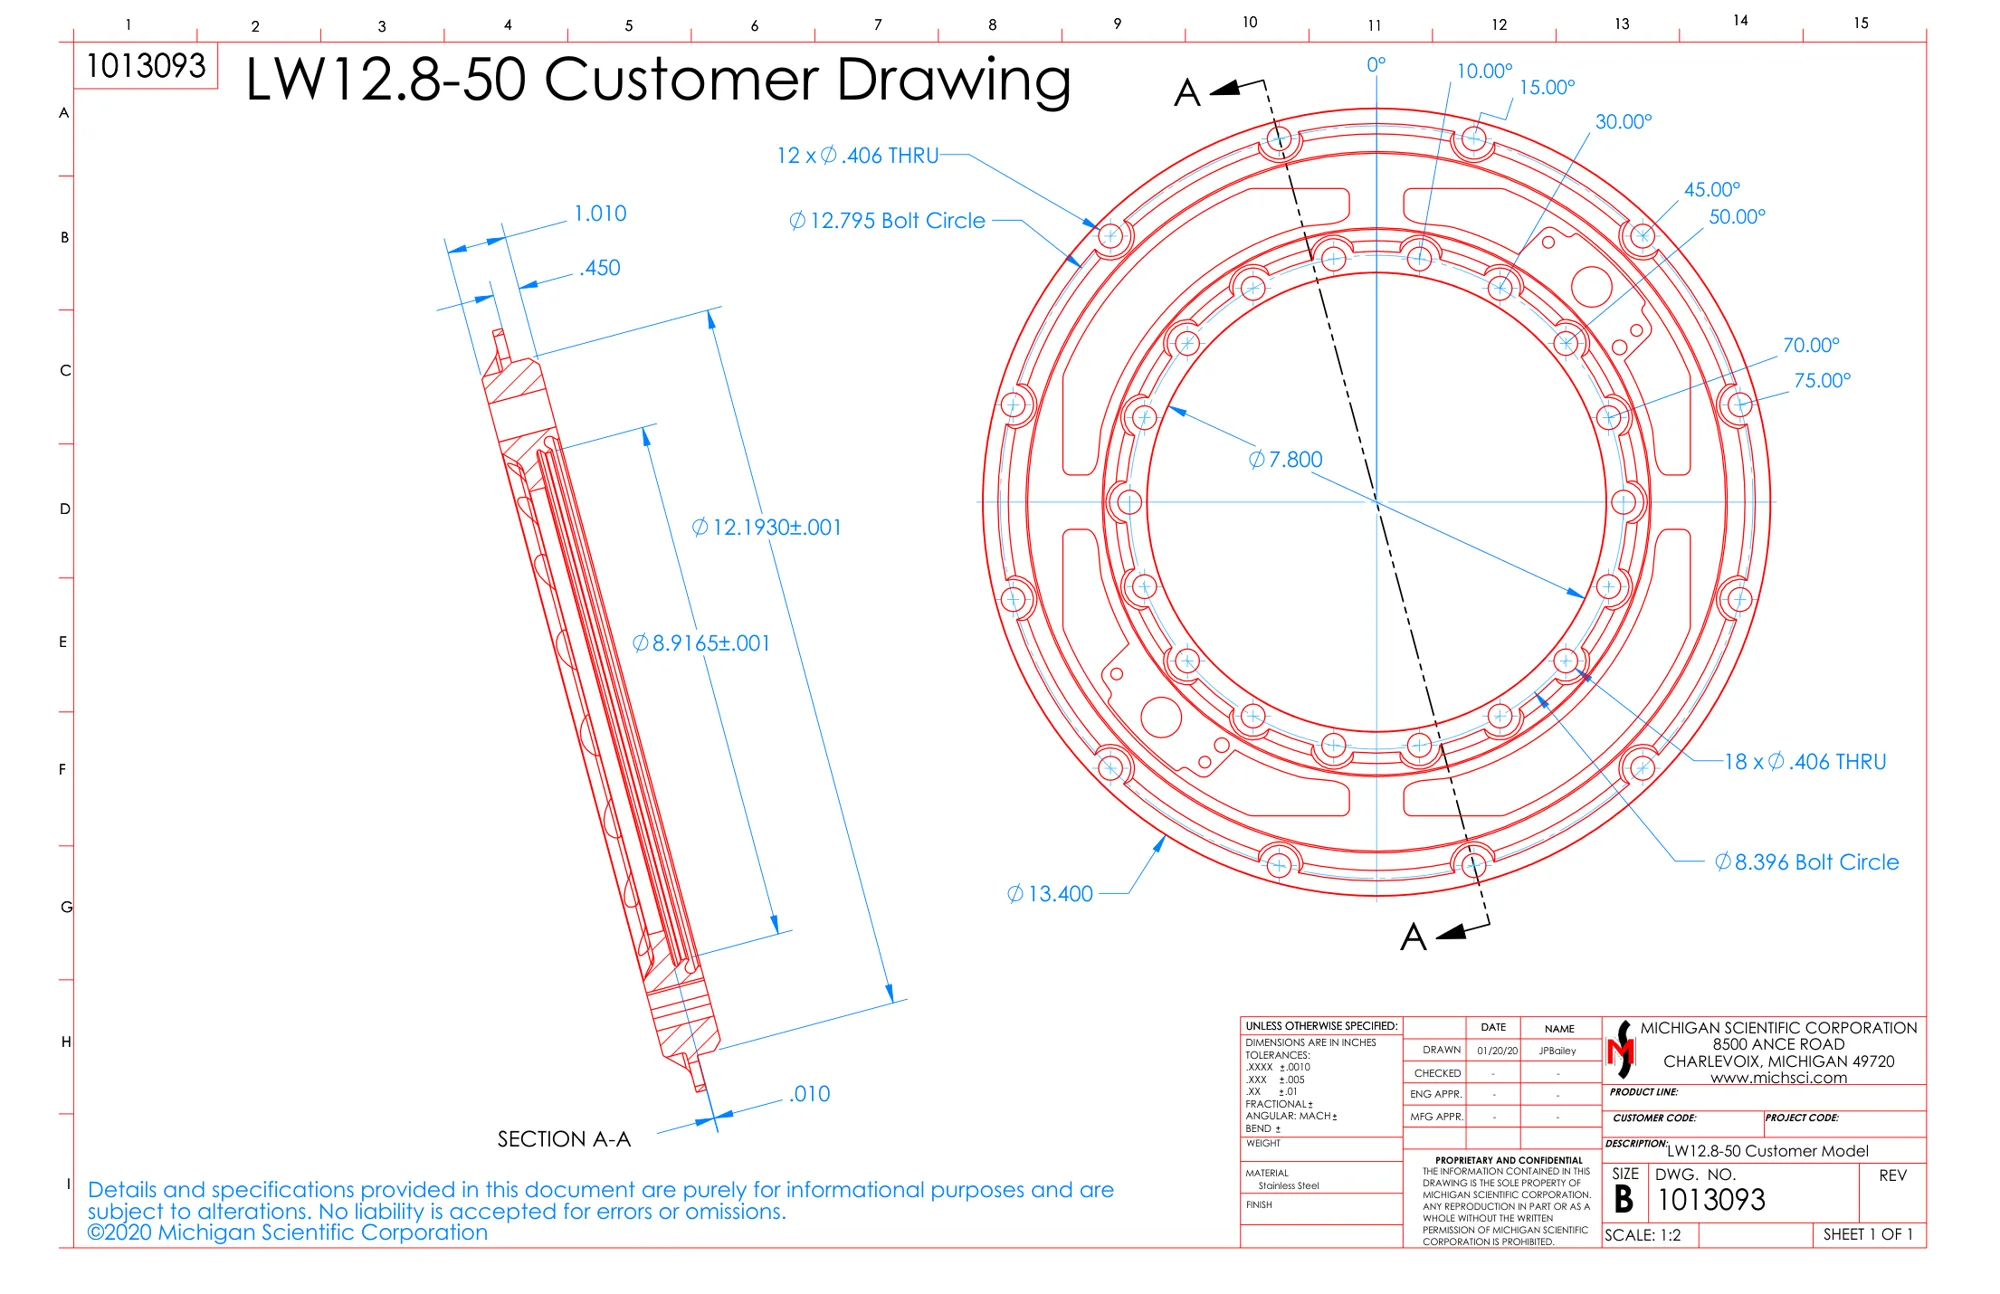
No drawing for this version.
03 · Configure
Request a quote
Pick the model, how the signal leaves the wheel and what goes with it. The summary becomes your quote request.
Unusual bolt pattern, motorsport hub, agricultural wheel: we build it around your wheel.
04 · Resources
Resources
Datasheets and manuals
Drawings
CAD models
Datasheets and manuals
Drawings
CAD models
Datasheets and manuals
Drawings
None for LW9.5.
CAD models
Datasheets and manuals
Drawings
CAD models
Datasheets and manuals
Drawings
CAD models
None for LW12.8-50-TEL.
Datasheets and manuals
Drawings
CAD models
Datasheets and manuals
Drawings
CAD models
Datasheets and manuals
Drawings
None for LW60.
CAD models
Datasheets and manuals
Drawings
None for LW65.
CAD models
Datasheets and manuals
- Datasheet LW 2T 20K (PDF)
- doc wft lw 2t 20k de reva (PDF)
- doc wft lw 2t 20k de reva (PDF)
- LW 2T 20K WFT Manual Rev 2.4 (PDF)
- LW 2T 20K Hub Adapter Design Guide 200+ mm (PDF)
- LW 2T 20K Hub Adapter Design Guide (PDF)
- LW 2T 20K Rim Adapter Design Guide (PDF)
- LW-2T-20K user's manual, CT2 version, rev. 2.5
- LW-2T-20K user's manual, CT3 version, rev. 3.0
Drawings
CAD models
Datasheets and manuals
Drawings
None for LW9.5-HS.
CAD models
Datasheets and manuals
Drawings
CAD models
Datasheets and manuals
Drawings
CAD models
Datasheets and manuals
Drawings
CAD models
Datasheets and manuals
CAD models
Datasheets and manuals
Datasheets and manuals
Drawings
CAD models
None for LW-2T-100K.
05 · Applications
Related applications
-
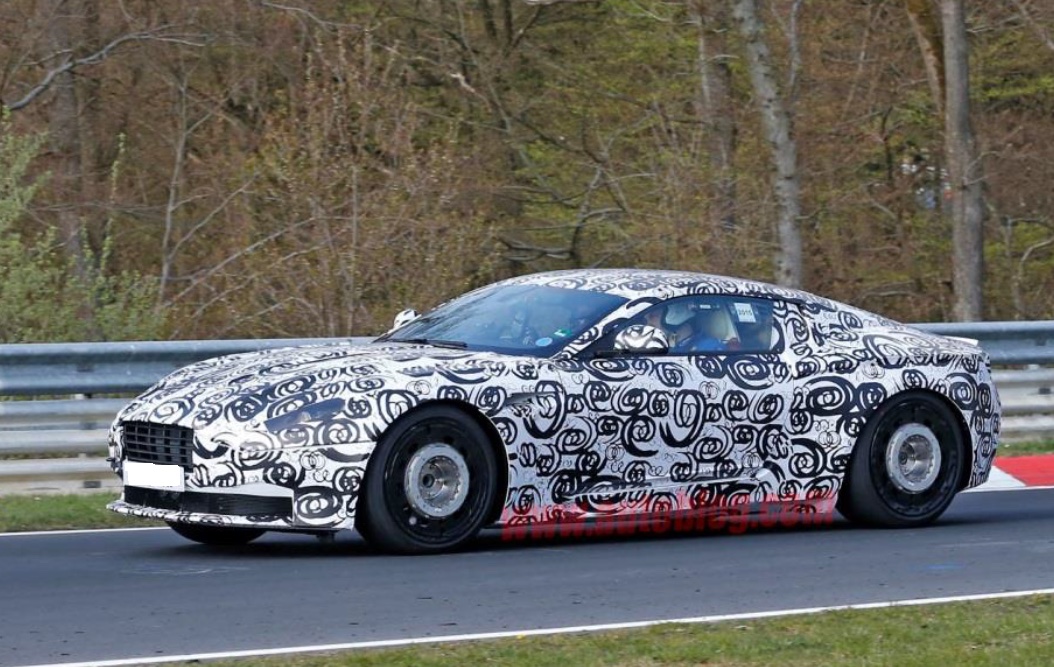 Durability Wheel loads on the road Three forces and three moments at each wheel, recorded while the vehicle is driven.
-
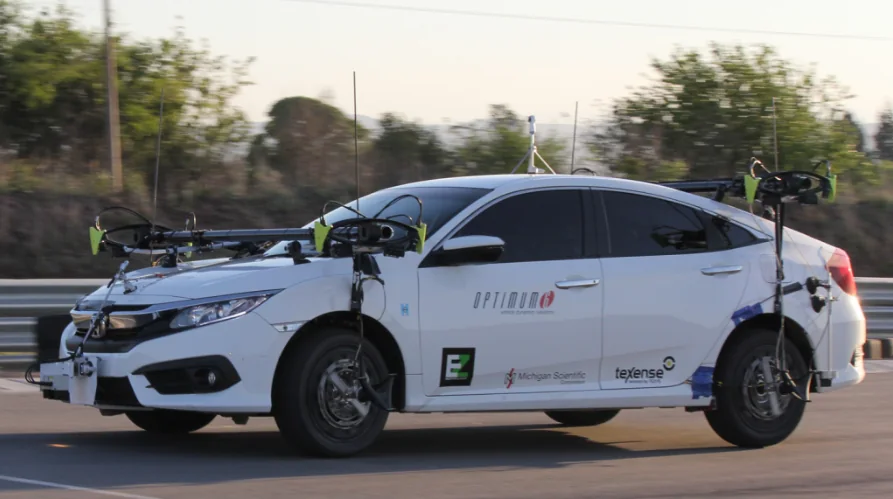 Dynamics Vehicle dynamics The forces and moments at each wheel while the vehicle brakes, turns and changes lane.
-
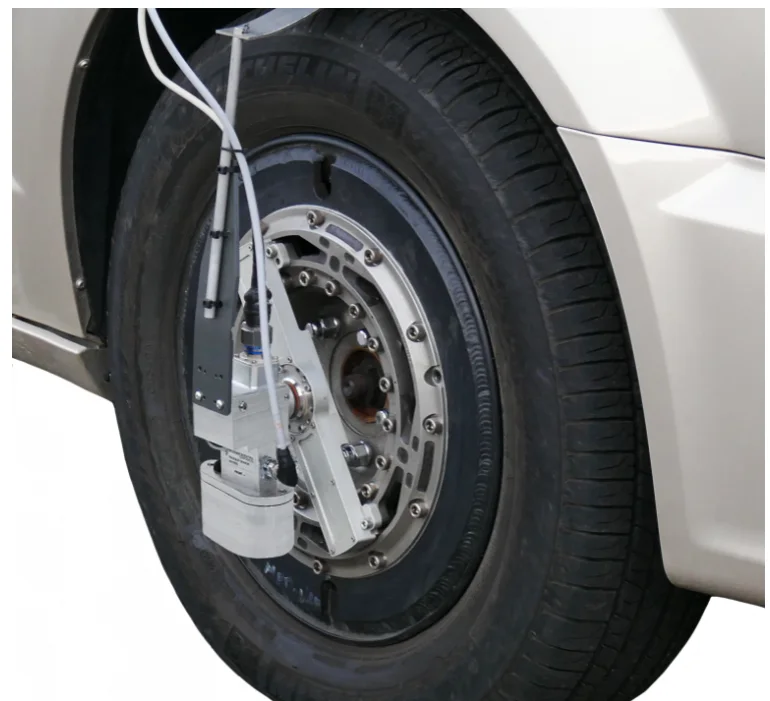 Dynamics Side slip angle Side slip angle read without contact by an optical sensor, on a wheel or on the vehicle body.
-
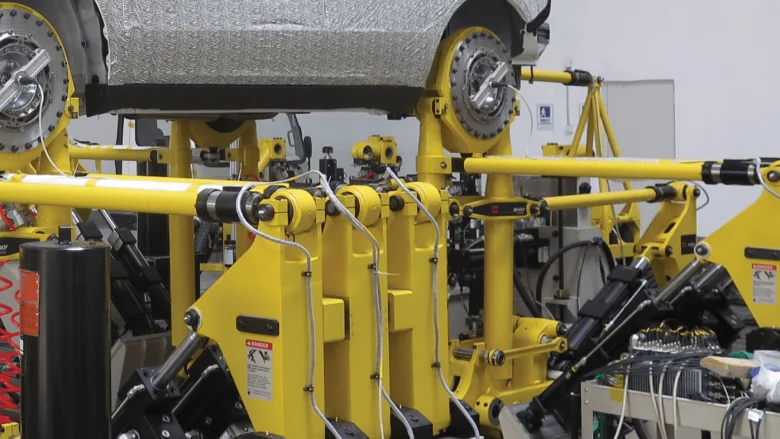 Test rig Road simulators The loads measured at the wheel on the road, and the proof that the simulator reproduces them.
06 · Related
If a six-axis wheel is not what you need
- Torque only TW series wheel torque transducers
Drive and brake torque My at the wheel, 237 N·m to 81 kN·m.
- Signals from the series wheel Wheel instrumentation
Strain gages, thermocouples and wheel speed, on the wheel the vehicle already has.
- Force on a part, not a wheel TR3D three-axis load cells
Three orthogonal forces from 1.1 to 444 kN.
A question on this product?
Vehicle, wheel size, expected loads. An application engineer answers.
More details to give? Use the full contact form.