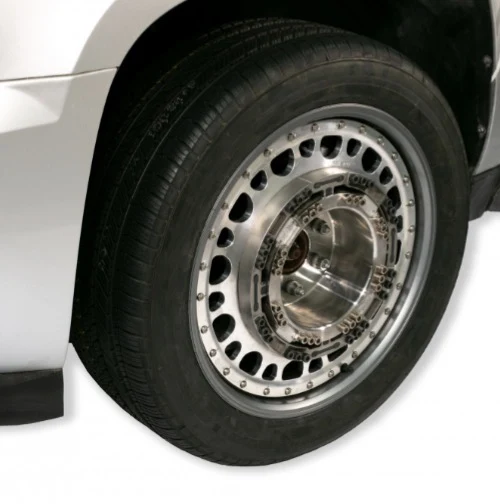
LW65 wheel force transducer
Six-axis wheel force transducer for passenger cars, SUVs and light-duty trucks, 65 kN radial, 35 kN lateral and 10.5 kN·m, IP67, with slip ring or telemetry.
- 65 kN
- Fx, Fz capacity
- 35 kN
- Fy capacity
- 10.5 kN·m
- Moment capacity
- ≤ 0.2 % FS (forces, My)
- Non-linearity
- OutputsFx Fy Fz · Mx My Mz
- Also measuredX and Z acceleration (X, Y, Z on the LW50 and LW55) · wheel speed and angle
- Signal outputanalog · CAN · Ethernet · CAN FD and EtherCAT on the CT3
- Signal transmissionslip ring or telemetry
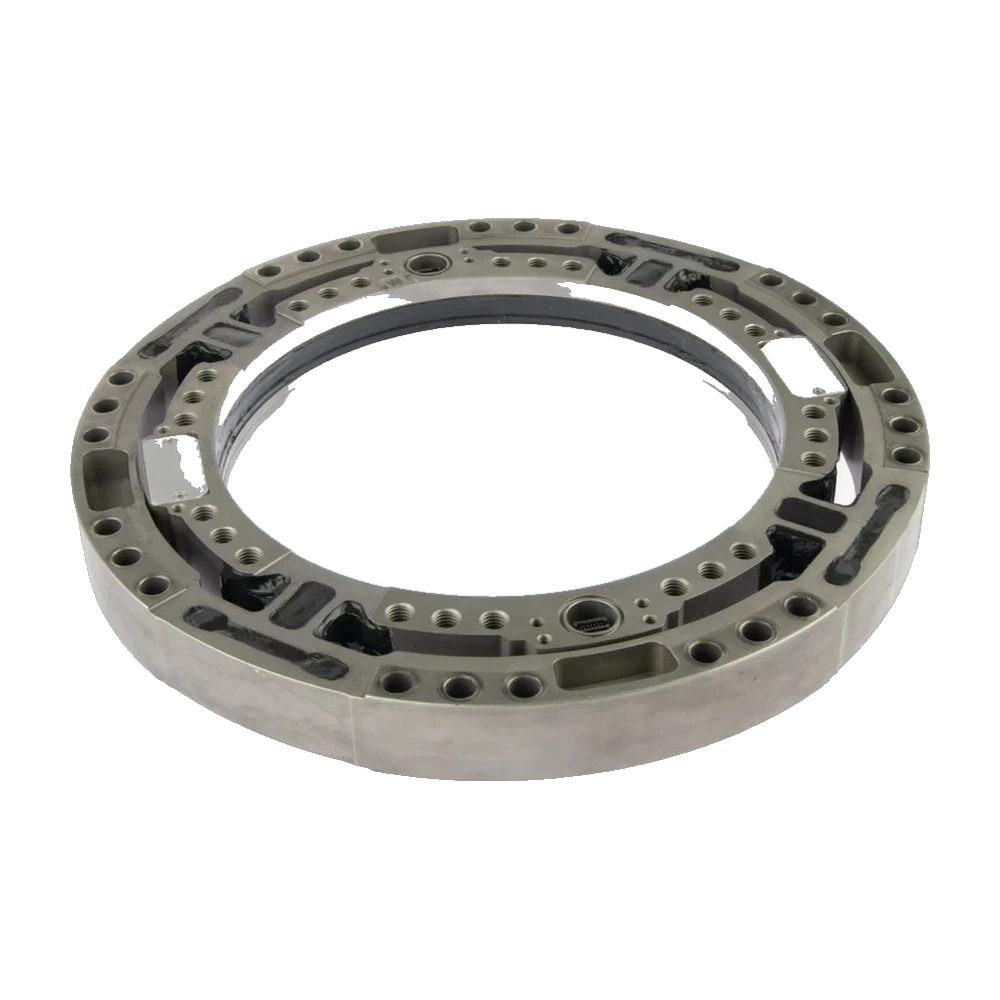
LW65: wheel force transducer for cars and SUVs, 65 kN
The LW65 measures all the wheel forces and moments on passenger cars, SUVs and light-duty trucks, with X and Z accelerations up to ±100 g. It is rated 65 kN (14,500 lb) on Fx and Fz, 35 kN (7,850 lb) on Fy and 10.5 kN·m (7,700 lbf·ft) on all three moments, for a static weight of 1,320 kg. Non-linearity is 0.2 % of full scale or less on the forces and My, cross-axis sensitivity after correction 0.4 % or less. The IP67 transducer operates from −40 to 177 °C and adapts to 12 in and larger wheels; angular resolution is 0.17°.
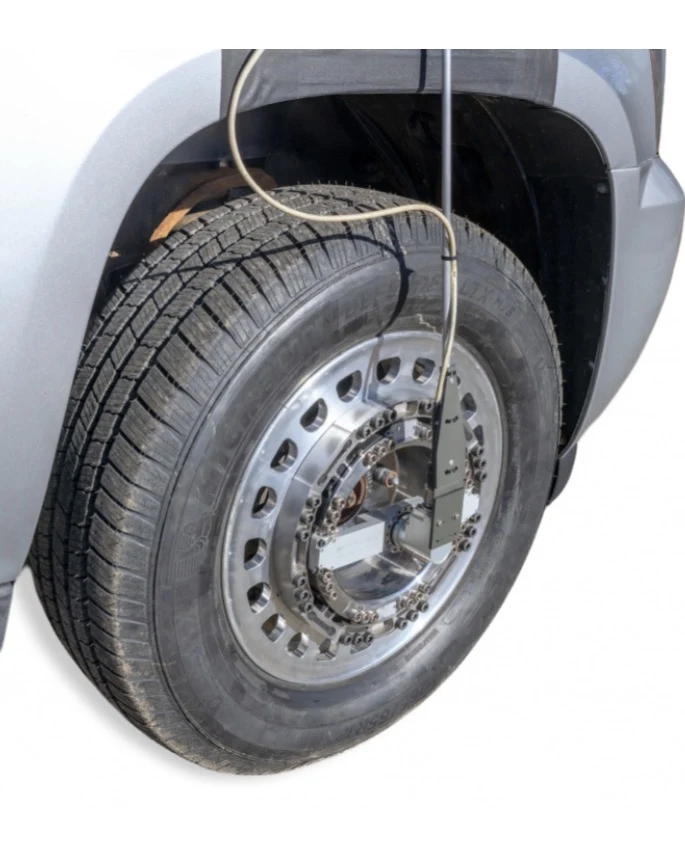
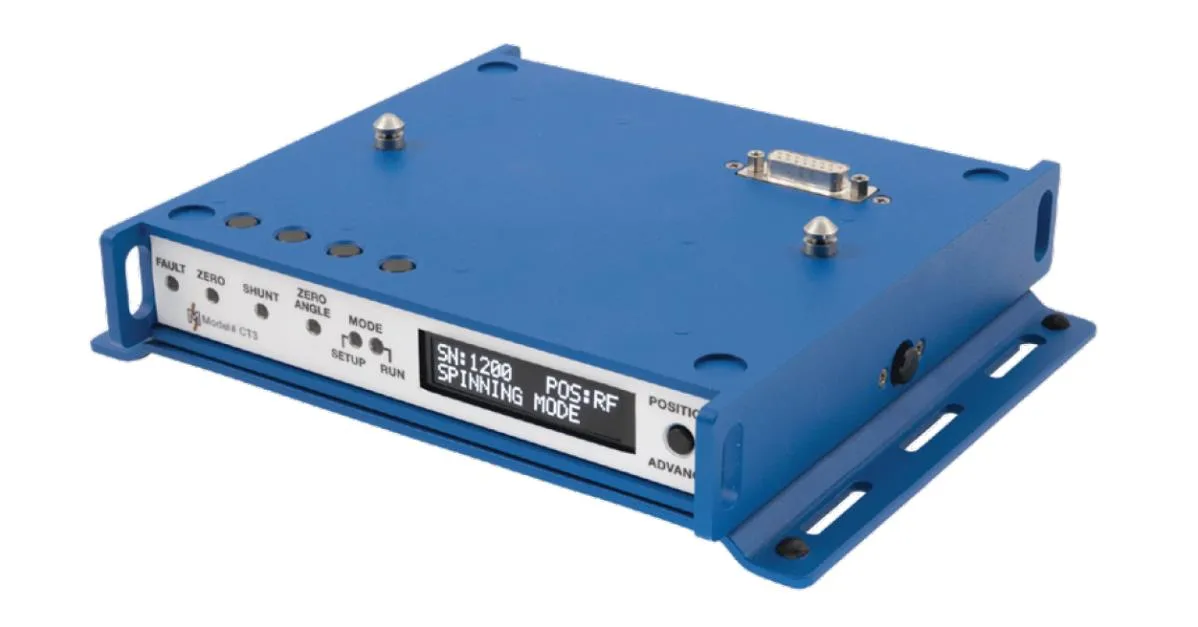
Twenty-four M10 × 1.5 screws pass through the transducer into the rim adapter and twenty-four more fasten the hub adapter, torqued crosswise to 81 N·m; design guides give both adapters. With the slip ring, the amplifier carries a 20-circuit slip ring with a 512-pulse encoder, its stator held by a restraint rod or a stator angle corrector. With telemetry, a factory-mated telemetry and encoder ring feeds an inboard stator set with an alignment tool, read by the CT3 box.
Its IP67 design suits the harshest track and off-road measurements, and non-spinning applications that monitor and control laboratory test rigs. A Michigan Scientific video shows its telemetry set fitted to the front hub of a car.
Specifications
| Measured quantities | Fx · Fy · Fz · Mx · My · Mz |
|---|---|
| Force capacity | Fx 65 · Fy 35 · Fz 65 kN |
| Moment capacity | Mx 10 500 · My 10 500 · Mz 10 500 N·m |
| Max static load | 1 320 kg |
| Non-linearity | Fx ≤ 0.2 · Fy ≤ 0.2 · Fz ≤ 0.2 · Mx ≤ 0.4 · My ≤ 0.2 · Mz ≤ 0.4 % FS |
| Hysteresis | Fx ≤ 0.25 · Fy ≤ 0.45 · Fz ≤ 0.25 · Mx ≤ 0.45 · My ≤ 0.25 · Mz ≤ 0.45 % FS |
| Crosstalk | ≤ 0.4 % FS (after correction) |
| Angle resolution | 0.17° |
| Axes | 6 |
| Accelerometer range | 100 g (X and Z) |
| Output | Analog voltage · CAN · CAN FD · Ethernet · EtherCAT (CT3; EtherCAT with an add-on module) |
| Signal transmission | Slip ring · Telemetry (slip ring outboard; telemetry inboard) |
| Operating temperature | −40 to 177 °C |
| Protection | IP67 |
| Interface box | CT3 |
| Vehicles | Passenger cars · SUVs · Light trucks |
| Rim size | 12 in (and larger) |
Used with the LW65
What you add here goes into the same quote request.
-
Measure on a steered wheel
SAC stator angle corrector
Corrects the rotation angle signal in real time for the coordinate transformation, with no over-the-wheel bracket. Internal encoder accuracy ≤ 0.25°, IP67.
Slip ring versions, with the CT3 interface box.
Resources
Datasheets and manuals
Drawings
None for LW65.
CAD models
Related applications
-
 Durability Wheel loads on the road Three forces and three moments at each wheel, recorded while the vehicle is driven.
-
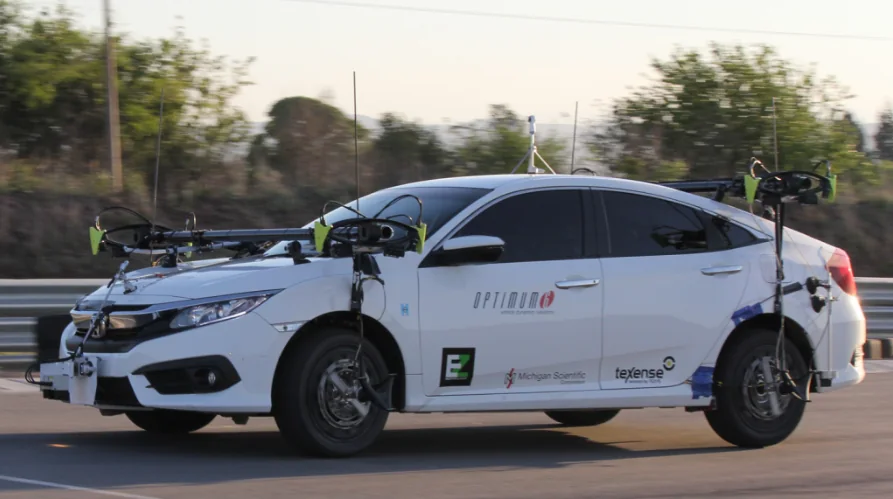 Dynamics Vehicle dynamics The forces and moments at each wheel while the vehicle brakes, turns and changes lane.
-
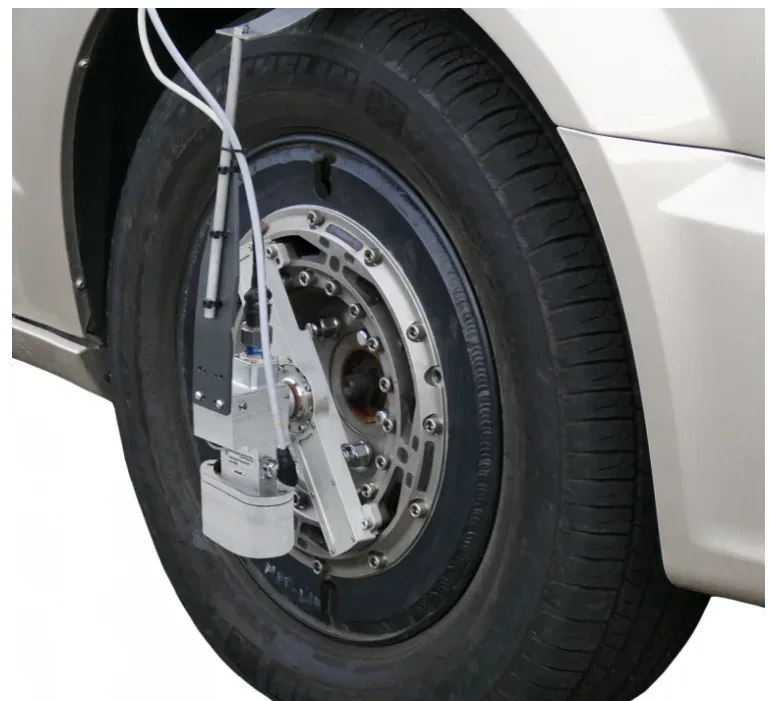 Dynamics Side slip angle Side slip angle read without contact by an optical sensor, on a wheel or on the vehicle body.
-
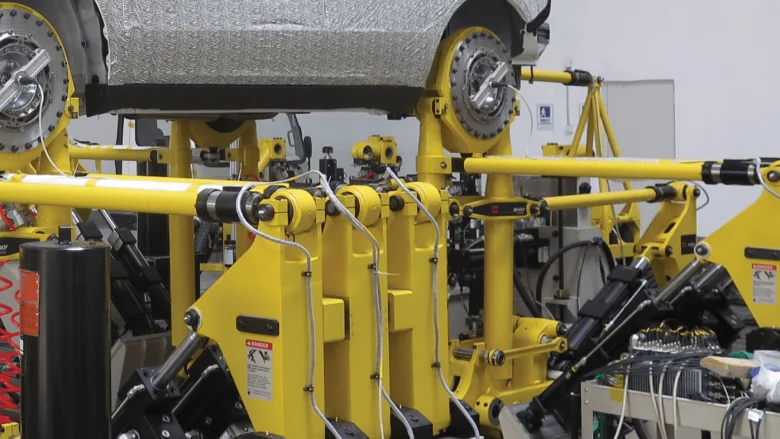 Test rig Road simulators The loads measured at the wheel on the road, and the proof that the simulator reproduces them.
If the LW65 is not the one
- Torque only Wheel torque transducers
Drive and brake torque at the wheel, while the vehicle is driven.
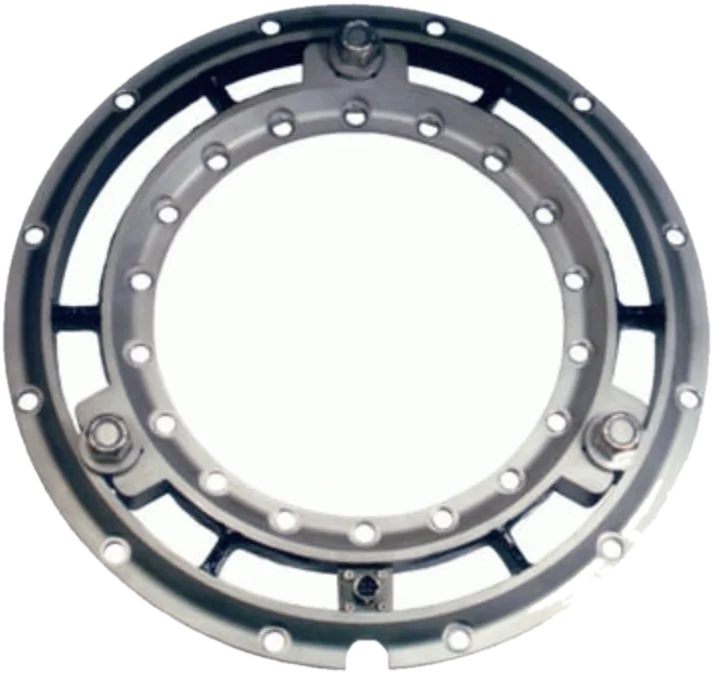
- Signals from the series wheel Wheel Instrumentation System
Strain gage and thermocouple signals off a rotating wheel, on the vehicle's own wheel, on track or off-road.
- Force on a part, not a wheel TR3D-B
Three perpendicular forces from a square body, down to 25.4 mm a side.
A question on this product?
Vehicle, wheel size, expected loads. An application engineer answers.
More details to give? Use the full contact form.