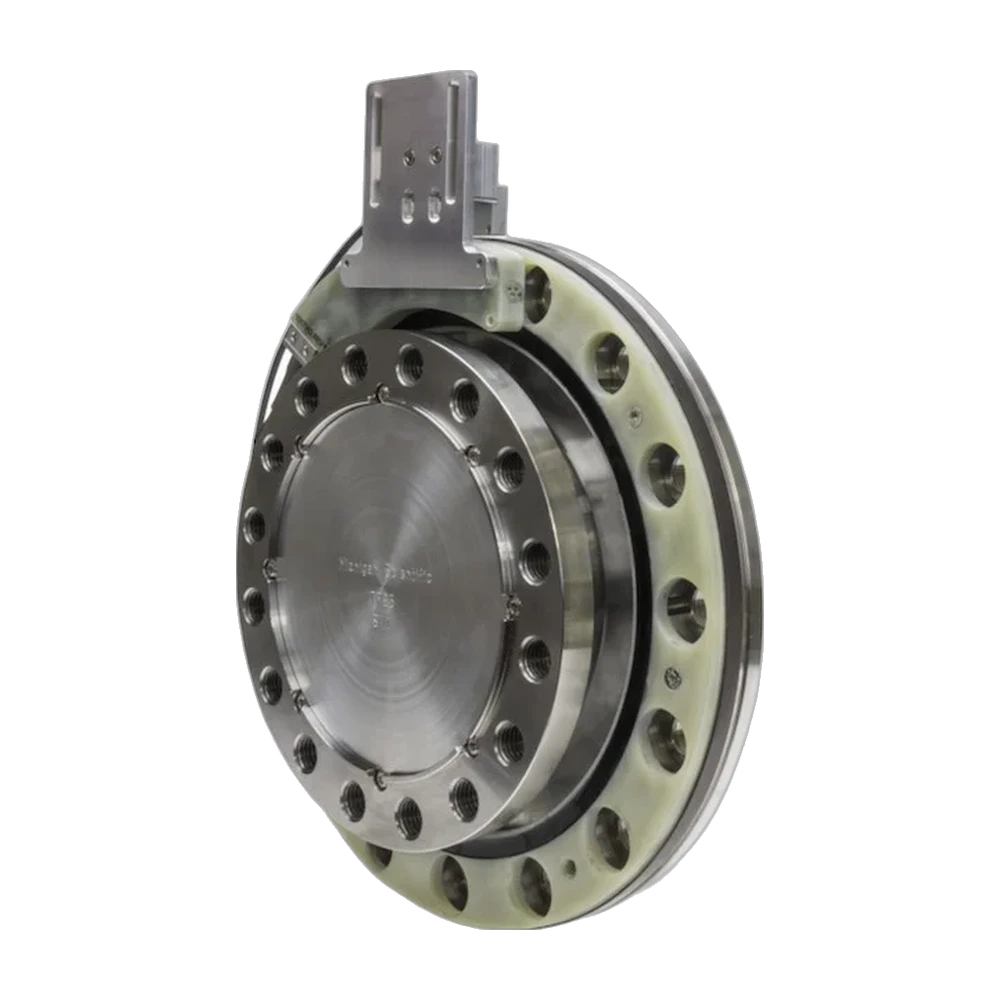
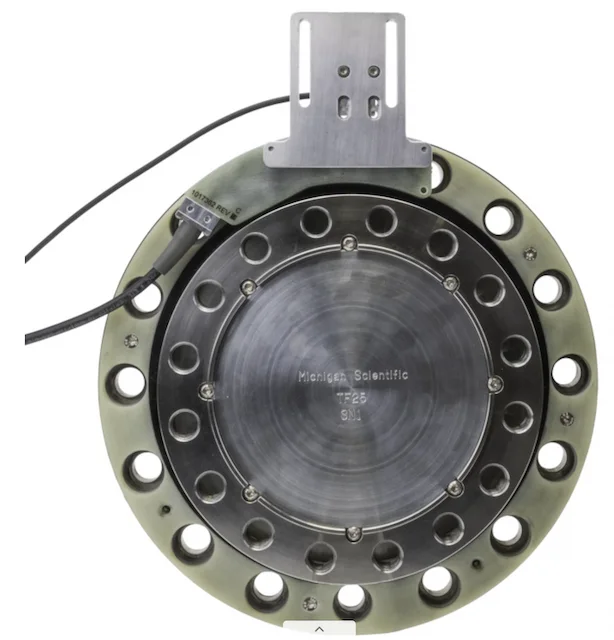
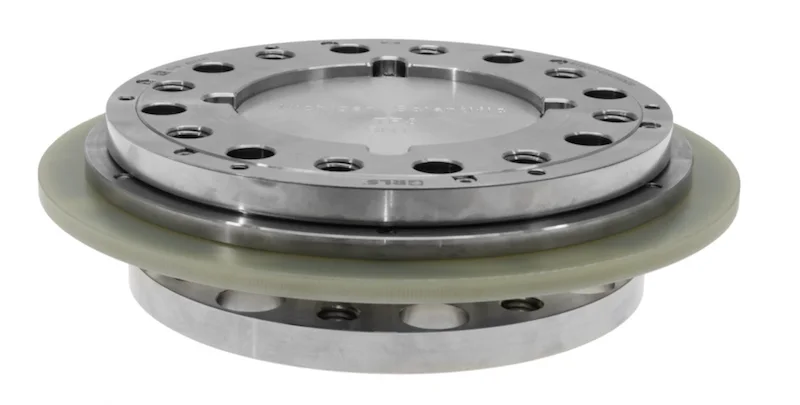
TF Series torque flange for test benches
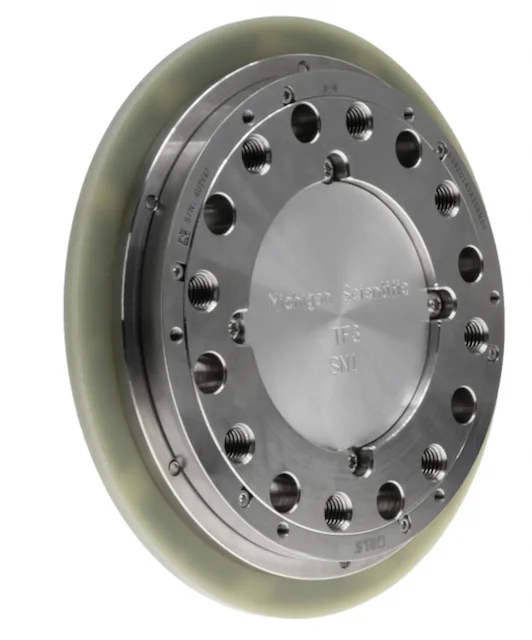
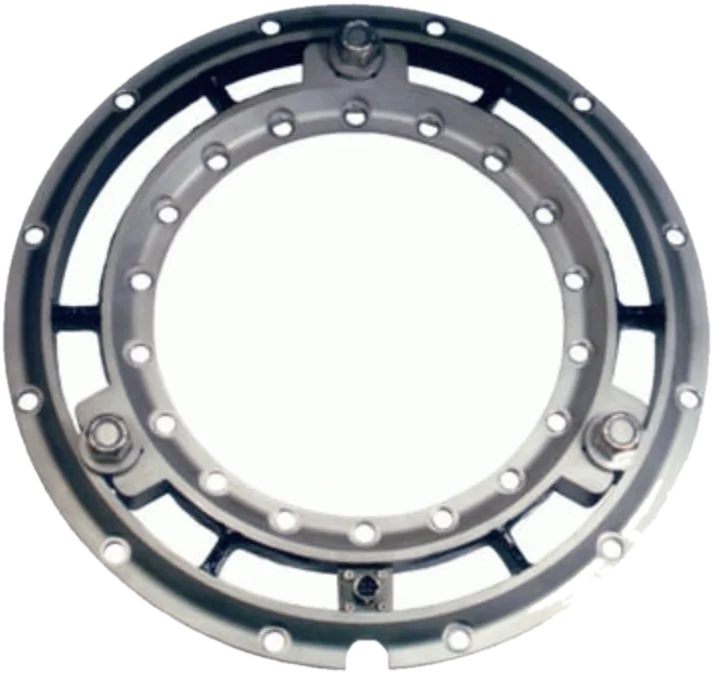
Flange-mounted rotating torque transducer for 0.1 kN·m, with wireless telemetry and no bearing, 126.65 mm in diameter and 45 mm long.
Flange-mounted rotating torque transducer for 1 kN·m, with wireless telemetry and no bearing, 162 mm in diameter and 49 mm long.
Flange-mounted rotating torque transducer for 2 kN·m, with wireless telemetry and no bearing, 202 mm in diameter and 53 mm long.
Flange-mounted rotating torque transducer for 3 kN·m, with wireless telemetry and no bearing, 202 mm in diameter and 53 mm long.
Flange-mounted rotating torque transducer for 5 kN·m, with wireless telemetry and no bearing, 325 mm in diameter and 63 mm long.
Flange-mounted rotating torque transducer for 10 kN·m, with wireless telemetry and no bearing, 325 mm in diameter and 75 mm long.
Flange-mounted rotating torque transducer for 15 kN·m, with wireless telemetry and no bearing, 326 mm in diameter and 73 mm long.
Flange-mounted rotating torque transducer for 25 kN·m, with wireless telemetry and no bearing, 326 mm in diameter and 73 mm long.
Flange-mounted rotating torque transducer for 50 kN·m, with wireless telemetry and no bearing, 390 mm in diameter and 85 mm long.
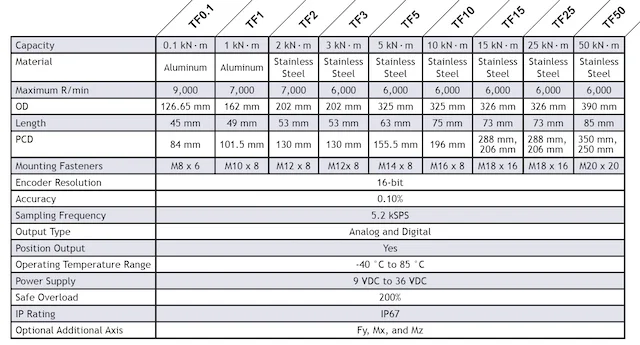
- 0.1 kN·m
- Torque capacity
- 9 000 rpm
- Max speed
- 126.65 mm
- Outer diameter
- 45 mm
- Length
- 1 kN·m
- Torque capacity
- 7 000 rpm
- Max speed
- 162 mm
- Outer diameter
- 49 mm
- Length
- 2 kN·m
- Torque capacity
- 7 000 rpm
- Max speed
- 202 mm
- Outer diameter
- 53 mm
- Length
- 3 kN·m
- Torque capacity
- 6 000 rpm
- Max speed
- 202 mm
- Outer diameter
- 53 mm
- Length
- 5 kN·m
- Torque capacity
- 6 000 rpm
- Max speed
- 325 mm
- Outer diameter
- 63 mm
- Length
- 10 kN·m
- Torque capacity
- 6 000 rpm
- Max speed
- 325 mm
- Outer diameter
- 75 mm
- Length
- 15 kN·m
- Torque capacity
- 6 000 rpm
- Max speed
- 326 mm
- Outer diameter
- 73 mm
- Length
- 25 kN·m
- Torque capacity
- 6 000 rpm
- Max speed
- 326 mm
- Outer diameter
- 73 mm
- Length
- 50 kN·m
- Torque capacity
- 6 000 rpm
- Max speed
- 390 mm
- Outer diameter
- 85 mm
- Length
- Outputanalog and digital
- Safe overload200 %
- Total thickness45 to 85 mm depending on version
- SealingIP67
TF0.1: torque flange, 0.1 kN·m
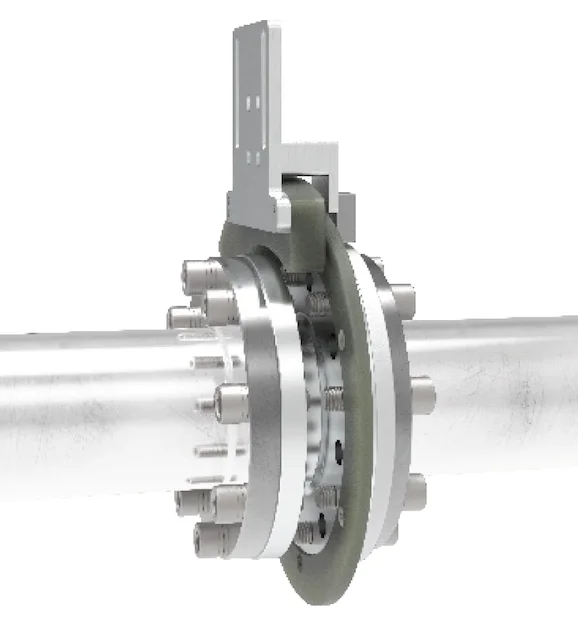
The TF0.1 is a rotating torque transducer mounted in the shaft line between two flanges. It measures torque up to 0.1 kN·m (100 N·m), with an accuracy of 0.10 % and a safe overload of 200 %, as well as speed and position. The aluminum body is 126.65 mm in diameter and 45 mm long, runs up to 9 000 rpm and is sealed to IP67. The design has no bearing. Data is sampled at 5.2 kS/s with a 16-bit encoder resolution. It operates from −40 to 85 °C.
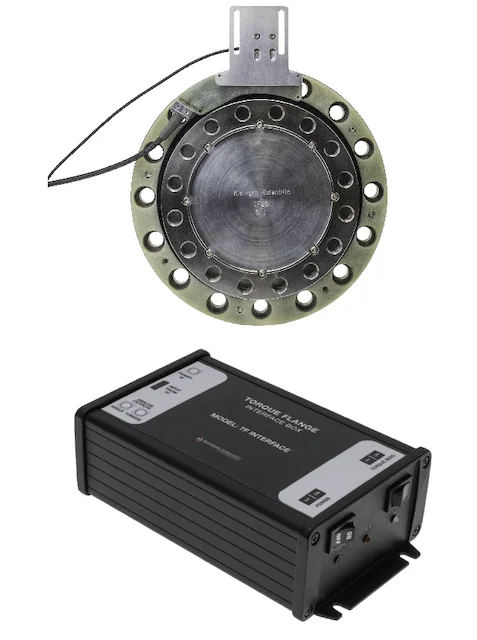
The transducer is bolted into the shaft line with six M8 bolts on an 84 mm pitch circle. It is supplied with a telemetry stator, a receiver and the system cables: the stator powers the transmitter by induction and the torque data reaches the receiver by RF. The Torque Flange Interface Box takes a 9 to 36 V DC supply, powers the system and provides the analog and digital outputs for data acquisition; a zeroing function is built in. The additional axes Fy, Mx and Mz are options, as is the speed and position encoder, with a resolution set to the customer's request.
Torque flanges are used on dynos, motors, engines, gearboxes and axles, for efficiency, fatigue, end-of-line and hybrid drive testing.
TF1: torque flange, 1 kN·m
The TF1 is a rotating torque transducer mounted in the shaft line between two flanges. It measures torque up to 1 kN·m (1 000 N·m), with an accuracy of 0.10 % and a safe overload of 200 %, as well as speed and position. The aluminum body is 162 mm in diameter and 49 mm long, runs up to 7 000 rpm and is sealed to IP67. The design has no bearing. Data is sampled at 5.2 kS/s with a 16-bit encoder resolution. It operates from −40 to 85 °C.
The transducer is bolted into the shaft line with eight M10 bolts on a 101.5 mm pitch circle. It is supplied with a telemetry stator, a receiver and the system cables: the stator powers the transmitter by induction and the torque data reaches the receiver by RF. The Torque Flange Interface Box takes a 9 to 36 V DC supply, powers the system and provides the analog and digital outputs for data acquisition; a zeroing function is built in. The additional axes Fy, Mx and Mz are options, as is the speed and position encoder, with a resolution set to the customer's request.
Torque flanges are used on dynos, motors, engines, gearboxes and axles, for efficiency, fatigue, end-of-line and hybrid drive testing.
TF2: torque flange, 2 kN·m
The TF2 is a rotating torque transducer mounted in the shaft line between two flanges. It measures torque up to 2 kN·m (2 000 N·m), with an accuracy of 0.10 % and a safe overload of 200 %, as well as speed and position. The stainless steel body is 202 mm in diameter and 53 mm long, runs up to 7 000 rpm and is sealed to IP67. The design has no bearing. Data is sampled at 5.2 kS/s with a 16-bit encoder resolution. It operates from −40 to 85 °C.
The transducer is bolted into the shaft line with eight M12 bolts on a 130 mm pitch circle. It is supplied with a telemetry stator, a receiver and the system cables: the stator powers the transmitter by induction and the torque data reaches the receiver by RF. The Torque Flange Interface Box takes a 9 to 36 V DC supply, powers the system and provides the analog and digital outputs for data acquisition; a zeroing function is built in. The additional axes Fy, Mx and Mz are options, as is the speed and position encoder, with a resolution set to the customer's request.
Torque flanges are used on dynos, motors, engines, gearboxes and axles, for efficiency, fatigue, end-of-line and hybrid drive testing.
TF3: torque flange, 3 kN·m
The TF3 is a rotating torque transducer mounted in the shaft line between two flanges. It measures torque up to 3 kN·m (3 000 N·m), with an accuracy of 0.10 % and a safe overload of 200 %, as well as speed and position. The stainless steel body is 202 mm in diameter and 53 mm long, runs up to 6 000 rpm and is sealed to IP67. The design has no bearing. Data is sampled at 5.2 kS/s with a 16-bit encoder resolution. It operates from −40 to 85 °C.
The transducer is bolted into the shaft line with eight M12 bolts on a 130 mm pitch circle. It is supplied with a telemetry stator, a receiver and the system cables: the stator powers the transmitter by induction and the torque data reaches the receiver by RF. The Torque Flange Interface Box takes a 9 to 36 V DC supply, powers the system and provides the analog and digital outputs for data acquisition; a zeroing function is built in. The additional axes Fy, Mx and Mz are options, as is the speed and position encoder, with a resolution set to the customer's request.
Torque flanges are used on dynos, motors, engines, gearboxes and axles, for efficiency, fatigue, end-of-line and hybrid drive testing.
TF5: torque flange, 5 kN·m
The TF5 is a rotating torque transducer mounted in the shaft line between two flanges. It measures torque up to 5 kN·m (5 000 N·m), with an accuracy of 0.10 % and a safe overload of 200 %, as well as speed and position. The stainless steel body is 325 mm in diameter and 63 mm long, runs up to 6 000 rpm and is sealed to IP67. The design has no bearing. Data is sampled at 5.2 kS/s with a 16-bit encoder resolution. It operates from −40 to 85 °C.
The transducer is bolted into the shaft line with eight M14 bolts on a 155.5 mm pitch circle. It is supplied with a telemetry stator, a receiver and the system cables: the stator powers the transmitter by induction and the torque data reaches the receiver by RF. The Torque Flange Interface Box takes a 9 to 36 V DC supply, powers the system and provides the analog and digital outputs for data acquisition; a zeroing function is built in. The additional axes Fy, Mx and Mz are options, as is the speed and position encoder, with a resolution set to the customer's request.
Torque flanges are used on dynos, motors, engines, gearboxes and axles, for efficiency, fatigue, end-of-line and hybrid drive testing.
TF10: torque flange, 10 kN·m
The TF10 is a rotating torque transducer mounted in the shaft line between two flanges. It measures torque up to 10 kN·m (10 000 N·m), with an accuracy of 0.10 % and a safe overload of 200 %, as well as speed and position. The stainless steel body is 325 mm in diameter and 75 mm long, runs up to 6 000 rpm and is sealed to IP67. The design has no bearing. Data is sampled at 5.2 kS/s with a 16-bit encoder resolution. It operates from −40 to 85 °C.
The transducer is bolted into the shaft line with eight M16 bolts on a 196 mm pitch circle. It is supplied with a telemetry stator, a receiver and the system cables: the stator powers the transmitter by induction and the torque data reaches the receiver by RF. The Torque Flange Interface Box takes a 9 to 36 V DC supply, powers the system and provides the analog and digital outputs for data acquisition; a zeroing function is built in. The additional axes Fy, Mx and Mz are options, as is the speed and position encoder, with a resolution set to the customer's request.
Torque flanges are used on dynos, motors, engines, gearboxes and axles, for efficiency, fatigue, end-of-line and hybrid drive testing.
TF15: torque flange, 15 kN·m
The TF15 is a rotating torque transducer mounted in the shaft line between two flanges. It measures torque up to 15 kN·m (15 000 N·m), with an accuracy of 0.10 % and a safe overload of 200 %, as well as speed and position. The stainless steel body is 326 mm in diameter and 73 mm long, runs up to 6 000 rpm and is sealed to IP67. The design has no bearing. Data is sampled at 5.2 kS/s with a 16-bit encoder resolution. It operates from −40 to 85 °C.
The transducer is bolted into the shaft line with sixteen M18 bolts on 288 mm and 206 mm pitch circles. It is supplied with a telemetry stator, a receiver and the system cables: the stator powers the transmitter by induction and the torque data reaches the receiver by RF. The Torque Flange Interface Box takes a 9 to 36 V DC supply, powers the system and provides the analog and digital outputs for data acquisition; a zeroing function is built in. The additional axes Fy, Mx and Mz are options, as is the speed and position encoder, with a resolution set to the customer's request.
Torque flanges are used on dynos, motors, engines, gearboxes and axles, for efficiency, fatigue, end-of-line and hybrid drive testing.
TF25: torque flange, 25 kN·m
The TF25 is a rotating torque transducer mounted in the shaft line between two flanges. It measures torque up to 25 kN·m (25 000 N·m), with an accuracy of 0.10 % and a safe overload of 200 %, as well as speed and position. The stainless steel body is 326 mm in diameter and 73 mm long, runs up to 6 000 rpm and is sealed to IP67. The design has no bearing. Data is sampled at 5.2 kS/s with a 16-bit encoder resolution. It operates from −40 to 85 °C.
The transducer is bolted into the shaft line with sixteen M18 bolts on 288 mm and 206 mm pitch circles. It is supplied with a telemetry stator, a receiver and the system cables: the stator powers the transmitter by induction and the torque data reaches the receiver by RF. The Torque Flange Interface Box takes a 9 to 36 V DC supply, powers the system and provides the analog and digital outputs for data acquisition; a zeroing function is built in. The additional axes Fy, Mx and Mz are options, as is the speed and position encoder, with a resolution set to the customer's request.
Torque flanges are used on dynos, motors, engines, gearboxes and axles, for efficiency, fatigue, end-of-line and hybrid drive testing.
TF50: torque flange, 50 kN·m
The TF50 is a rotating torque transducer mounted in the shaft line between two flanges. It measures torque up to 50 kN·m (50 000 N·m), with an accuracy of 0.10 % and a safe overload of 200 %, as well as speed and position. The stainless steel body is 390 mm in diameter and 85 mm long, runs up to 6 000 rpm and is sealed to IP67. The design has no bearing. Data is sampled at 5.2 kS/s with a 16-bit encoder resolution. It operates from −40 to 85 °C.
The transducer is bolted into the shaft line with twenty M20 bolts on 350 mm and 250 mm pitch circles. It is supplied with a telemetry stator, a receiver and the system cables: the stator powers the transmitter by induction and the torque data reaches the receiver by RF. The Torque Flange Interface Box takes a 9 to 36 V DC supply, powers the system and provides the analog and digital outputs for data acquisition; a zeroing function is built in. The additional axes Fy, Mx and Mz are options, as is the speed and position encoder, with a resolution set to the customer's request.
Torque flanges are used on dynos, motors, engines, gearboxes and axles, for efficiency, fatigue, end-of-line and hybrid drive testing.
Specifications
| Measured quantities | Torque · Angular position (Fy, Mx and Mz optional) |
|---|---|
| Torque capacity | 100 N·m |
| Overload capacity | 200 % |
| Accuracy | ≤ 0.1 % |
| Output | Analog · Digital (from the interface box) |
| Encoder resolution | 65 536 ppr (16-bit) |
| Sample rate | 5.2 kHz |
| Signal transmission | Telemetry |
| Supply voltage | 9 to 36 V |
| Power source | Induction (through the stator) |
| Mounting | Inline flange (rotating, bearingless) |
| Max speed | 9 000 rpm |
| Mounting fasteners | 6 × M8 |
| Bolt circle | 84 mm |
| Dimensions | Ø 126.65 × 45 mm |
| Material | Aluminum |
| Operating temperature | −40 to 85 °C |
| Protection | IP67 |
| Measured quantities | Torque · Angular position (Fy, Mx and Mz optional) |
|---|---|
| Torque capacity | 1 000 N·m |
| Overload capacity | 200 % |
| Accuracy | ≤ 0.1 % |
| Output | Analog · Digital (from the interface box) |
| Encoder resolution | 65 536 ppr (16-bit) |
| Sample rate | 5.2 kHz |
| Signal transmission | Telemetry |
| Supply voltage | 9 to 36 V |
| Power source | Induction (through the stator) |
| Mounting | Inline flange (rotating, bearingless) |
| Max speed | 7 000 rpm |
| Mounting fasteners | 8 × M10 |
| Bolt circle | 101.5 mm |
| Dimensions | Ø 162 × 49 mm |
| Material | Aluminum |
| Operating temperature | −40 to 85 °C |
| Protection | IP67 |
| Measured quantities | Torque · Angular position (Fy, Mx and Mz optional) |
|---|---|
| Torque capacity | 2 000 N·m |
| Overload capacity | 200 % |
| Accuracy | ≤ 0.1 % |
| Output | Analog · Digital (from the interface box) |
| Encoder resolution | 65 536 ppr (16-bit) |
| Sample rate | 5.2 kHz |
| Signal transmission | Telemetry |
| Supply voltage | 9 to 36 V |
| Power source | Induction (through the stator) |
| Mounting | Inline flange (rotating, bearingless) |
| Max speed | 7 000 rpm |
| Mounting fasteners | 8 × M12 |
| Bolt circle | 130 mm |
| Dimensions | Ø 202 × 53 mm |
| Material | Stainless steel |
| Operating temperature | −40 to 85 °C |
| Protection | IP67 |
| Measured quantities | Torque · Angular position (Fy, Mx and Mz optional) |
|---|---|
| Torque capacity | 3 000 N·m |
| Overload capacity | 200 % |
| Accuracy | ≤ 0.1 % |
| Output | Analog · Digital (from the interface box) |
| Encoder resolution | 65 536 ppr (16-bit) |
| Sample rate | 5.2 kHz |
| Signal transmission | Telemetry |
| Supply voltage | 9 to 36 V |
| Power source | Induction (through the stator) |
| Mounting | Inline flange (rotating, bearingless) |
| Max speed | 6 000 rpm |
| Mounting fasteners | 8 × M12 |
| Bolt circle | 130 mm |
| Dimensions | Ø 202 × 53 mm |
| Material | Stainless steel |
| Operating temperature | −40 to 85 °C |
| Protection | IP67 |
| Measured quantities | Torque · Angular position (Fy, Mx and Mz optional) |
|---|---|
| Torque capacity | 5 000 N·m |
| Overload capacity | 200 % |
| Accuracy | ≤ 0.1 % |
| Output | Analog · Digital (from the interface box) |
| Encoder resolution | 65 536 ppr (16-bit) |
| Sample rate | 5.2 kHz |
| Signal transmission | Telemetry |
| Supply voltage | 9 to 36 V |
| Power source | Induction (through the stator) |
| Mounting | Inline flange (rotating, bearingless) |
| Max speed | 6 000 rpm |
| Mounting fasteners | 8 × M14 |
| Bolt circle | 155.5 mm |
| Dimensions | Ø 325 × 63 mm |
| Material | Stainless steel |
| Operating temperature | −40 to 85 °C |
| Protection | IP67 |
| Measured quantities | Torque · Angular position (Fy, Mx and Mz optional) |
|---|---|
| Torque capacity | 10 000 N·m |
| Overload capacity | 200 % |
| Accuracy | ≤ 0.1 % |
| Output | Analog · Digital (from the interface box) |
| Encoder resolution | 65 536 ppr (16-bit) |
| Sample rate | 5.2 kHz |
| Signal transmission | Telemetry |
| Supply voltage | 9 to 36 V |
| Power source | Induction (through the stator) |
| Mounting | Inline flange (rotating, bearingless) |
| Max speed | 6 000 rpm |
| Mounting fasteners | 8 × M16 |
| Bolt circle | 196 mm |
| Dimensions | Ø 325 × 75 mm |
| Material | Stainless steel |
| Operating temperature | −40 to 85 °C |
| Protection | IP67 |
| Measured quantities | Torque · Angular position (Fy, Mx and Mz optional) |
|---|---|
| Torque capacity | 15 000 N·m |
| Overload capacity | 200 % |
| Accuracy | ≤ 0.1 % |
| Output | Analog · Digital (from the interface box) |
| Encoder resolution | 65 536 ppr (16-bit) |
| Sample rate | 5.2 kHz |
| Signal transmission | Telemetry |
| Supply voltage | 9 to 36 V |
| Power source | Induction (through the stator) |
| Mounting | Inline flange (rotating, bearingless) |
| Max speed | 6 000 rpm |
| Mounting fasteners | 16 × M18 |
| Bolt circle | 288 mm (and 206 mm) |
| Dimensions | Ø 326 × 73 mm |
| Material | Stainless steel |
| Operating temperature | −40 to 85 °C |
| Protection | IP67 |
| Measured quantities | Torque · Angular position (Fy, Mx and Mz optional) |
|---|---|
| Torque capacity | 25 000 N·m |
| Overload capacity | 200 % |
| Accuracy | ≤ 0.1 % |
| Output | Analog · Digital (from the interface box) |
| Encoder resolution | 65 536 ppr (16-bit) |
| Sample rate | 5.2 kHz |
| Signal transmission | Telemetry |
| Supply voltage | 9 to 36 V |
| Power source | Induction (through the stator) |
| Mounting | Inline flange (rotating, bearingless) |
| Max speed | 6 000 rpm |
| Mounting fasteners | 16 × M18 |
| Bolt circle | 288 mm (and 206 mm) |
| Dimensions | Ø 326 × 73 mm |
| Material | Stainless steel |
| Operating temperature | −40 to 85 °C |
| Protection | IP67 |
| Measured quantities | Torque · Angular position (Fy, Mx and Mz optional) |
|---|---|
| Torque capacity | 50 000 N·m |
| Overload capacity | 200 % |
| Accuracy | ≤ 0.1 % |
| Output | Analog · Digital (from the interface box) |
| Encoder resolution | 65 536 ppr (16-bit) |
| Sample rate | 5.2 kHz |
| Signal transmission | Telemetry |
| Supply voltage | 9 to 36 V |
| Power source | Induction (through the stator) |
| Mounting | Inline flange (rotating, bearingless) |
| Max speed | 6 000 rpm |
| Mounting fasteners | 20 × M20 |
| Bolt circle | 350 mm (and 250 mm) |
| Dimensions | Ø 390 × 85 mm |
| Material | Stainless steel |
| Operating temperature | −40 to 85 °C |
| Protection | IP67 |
Resources
Datasheets and manuals
Drawings
None for this product.
CAD models
None for this product.
Related applications
-
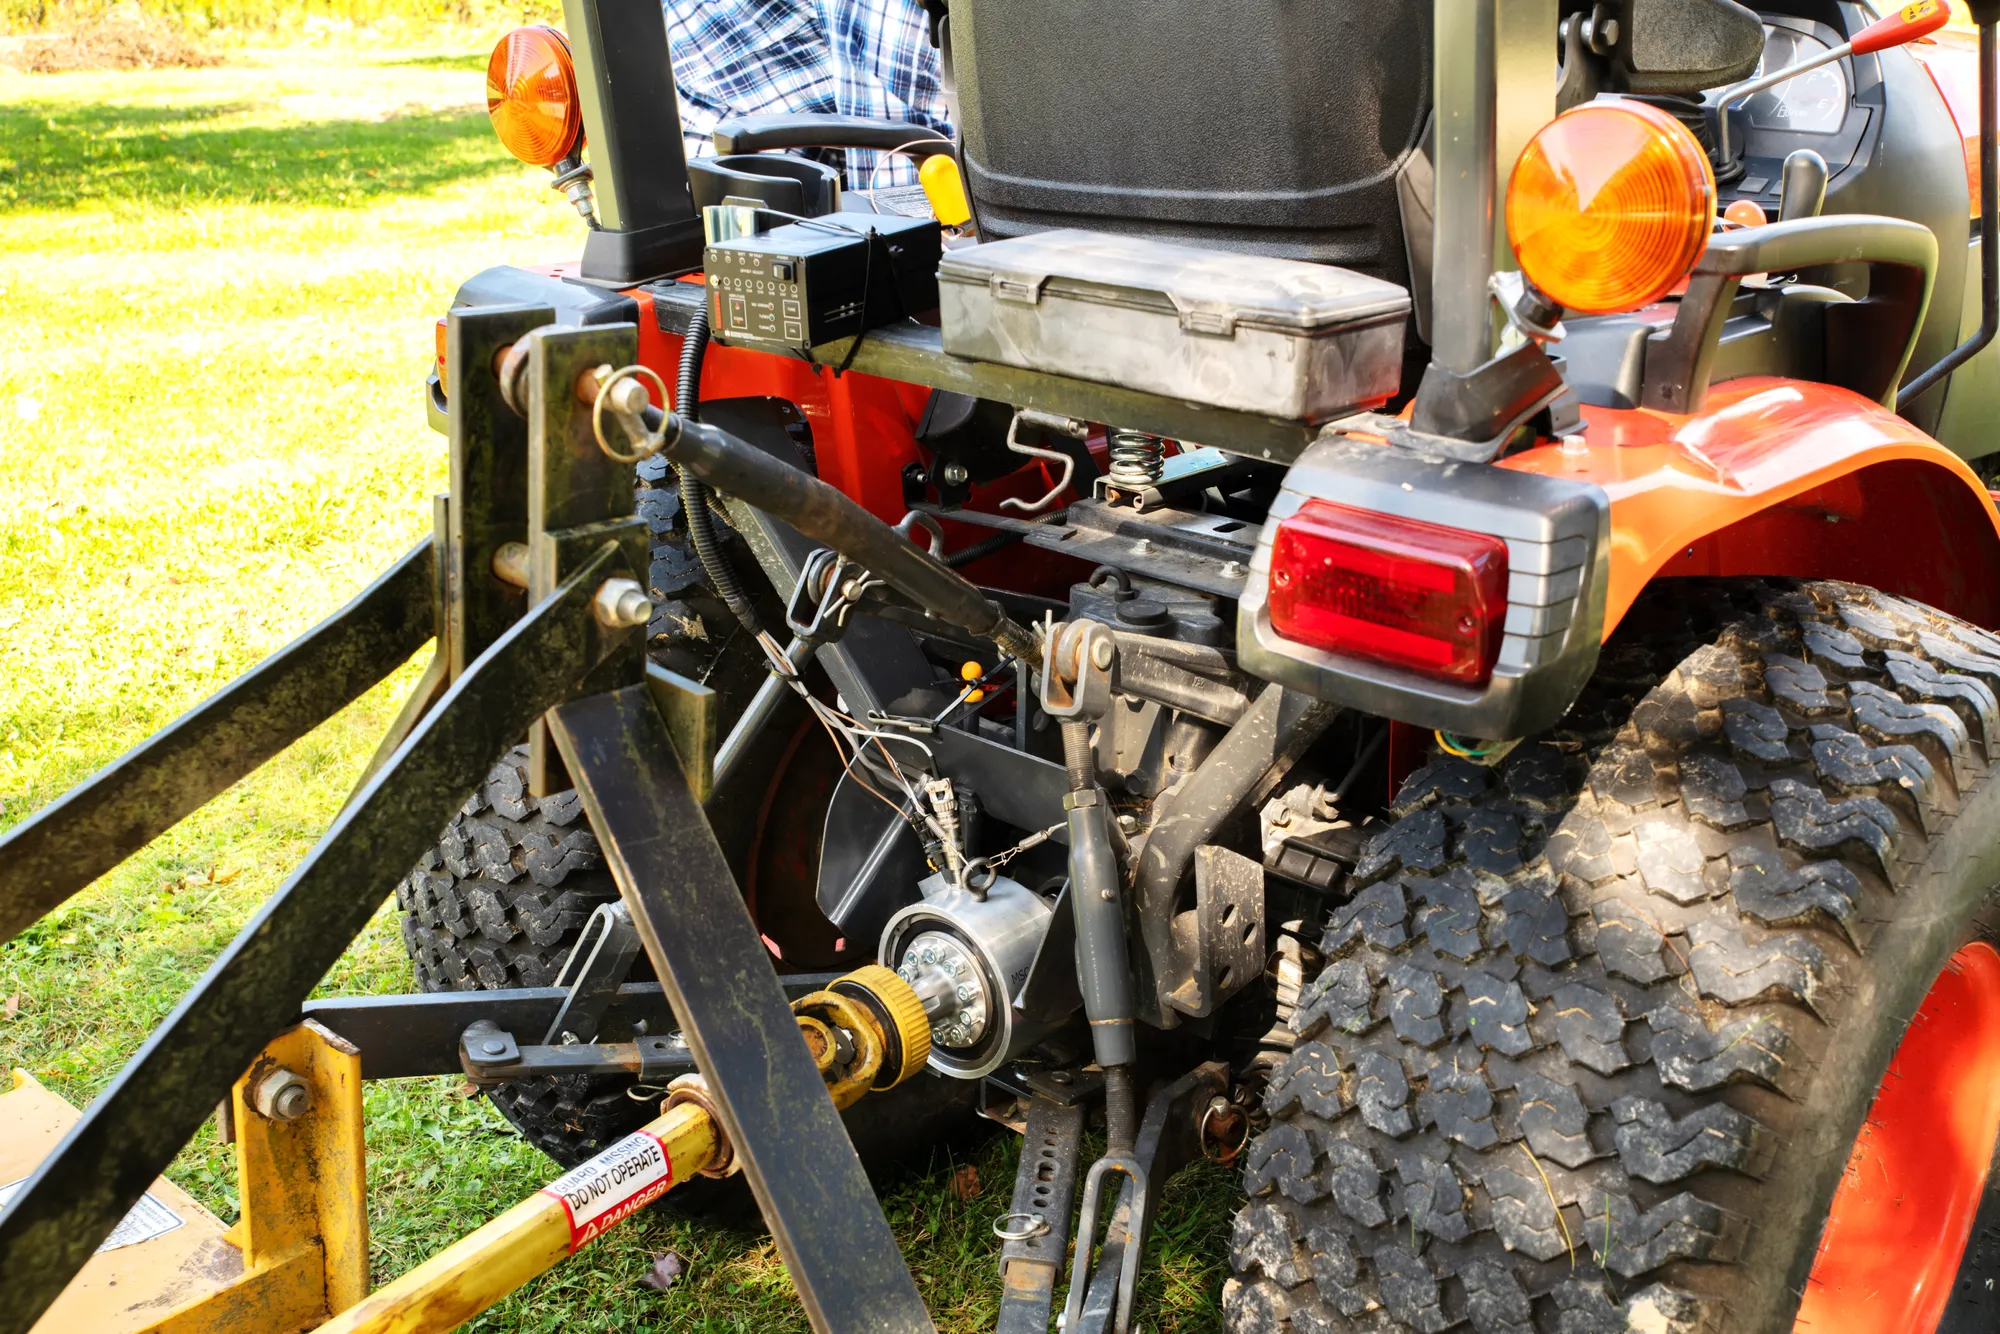 Agriculture PTO torque and power The torque and speed that the tractor delivers to the implement, measured during real field work.
-
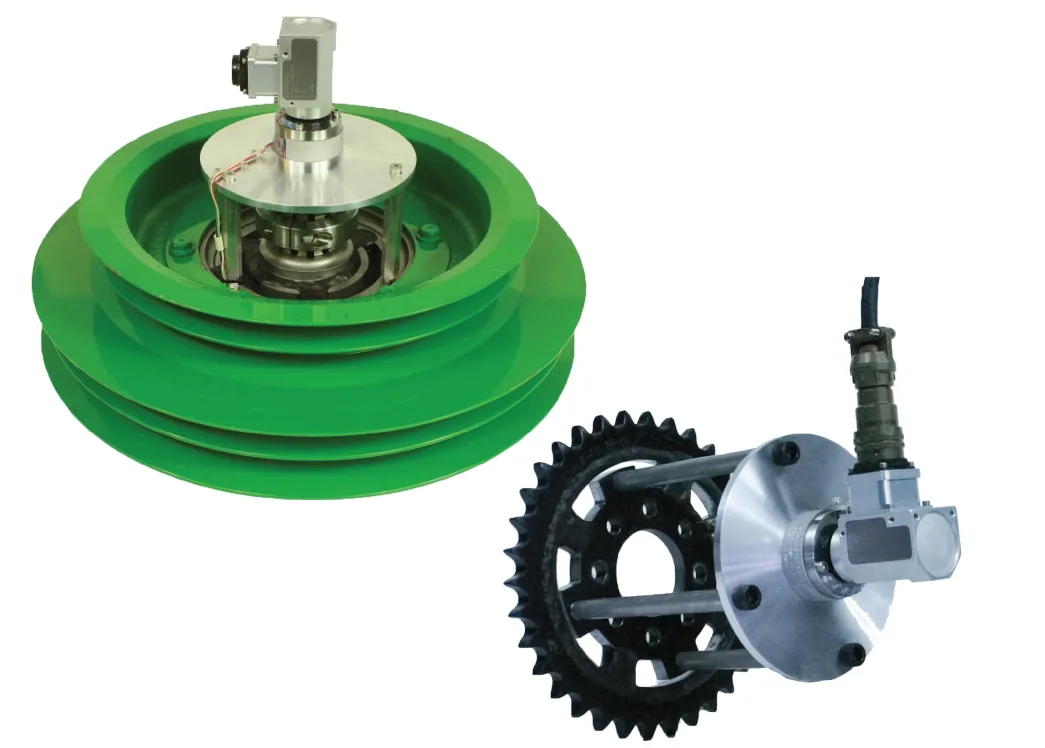 Agriculture Combine harvester gearbox Torque, speed and temperature on the pulleys, gears and gearboxes of a combine, to find power losses.
-
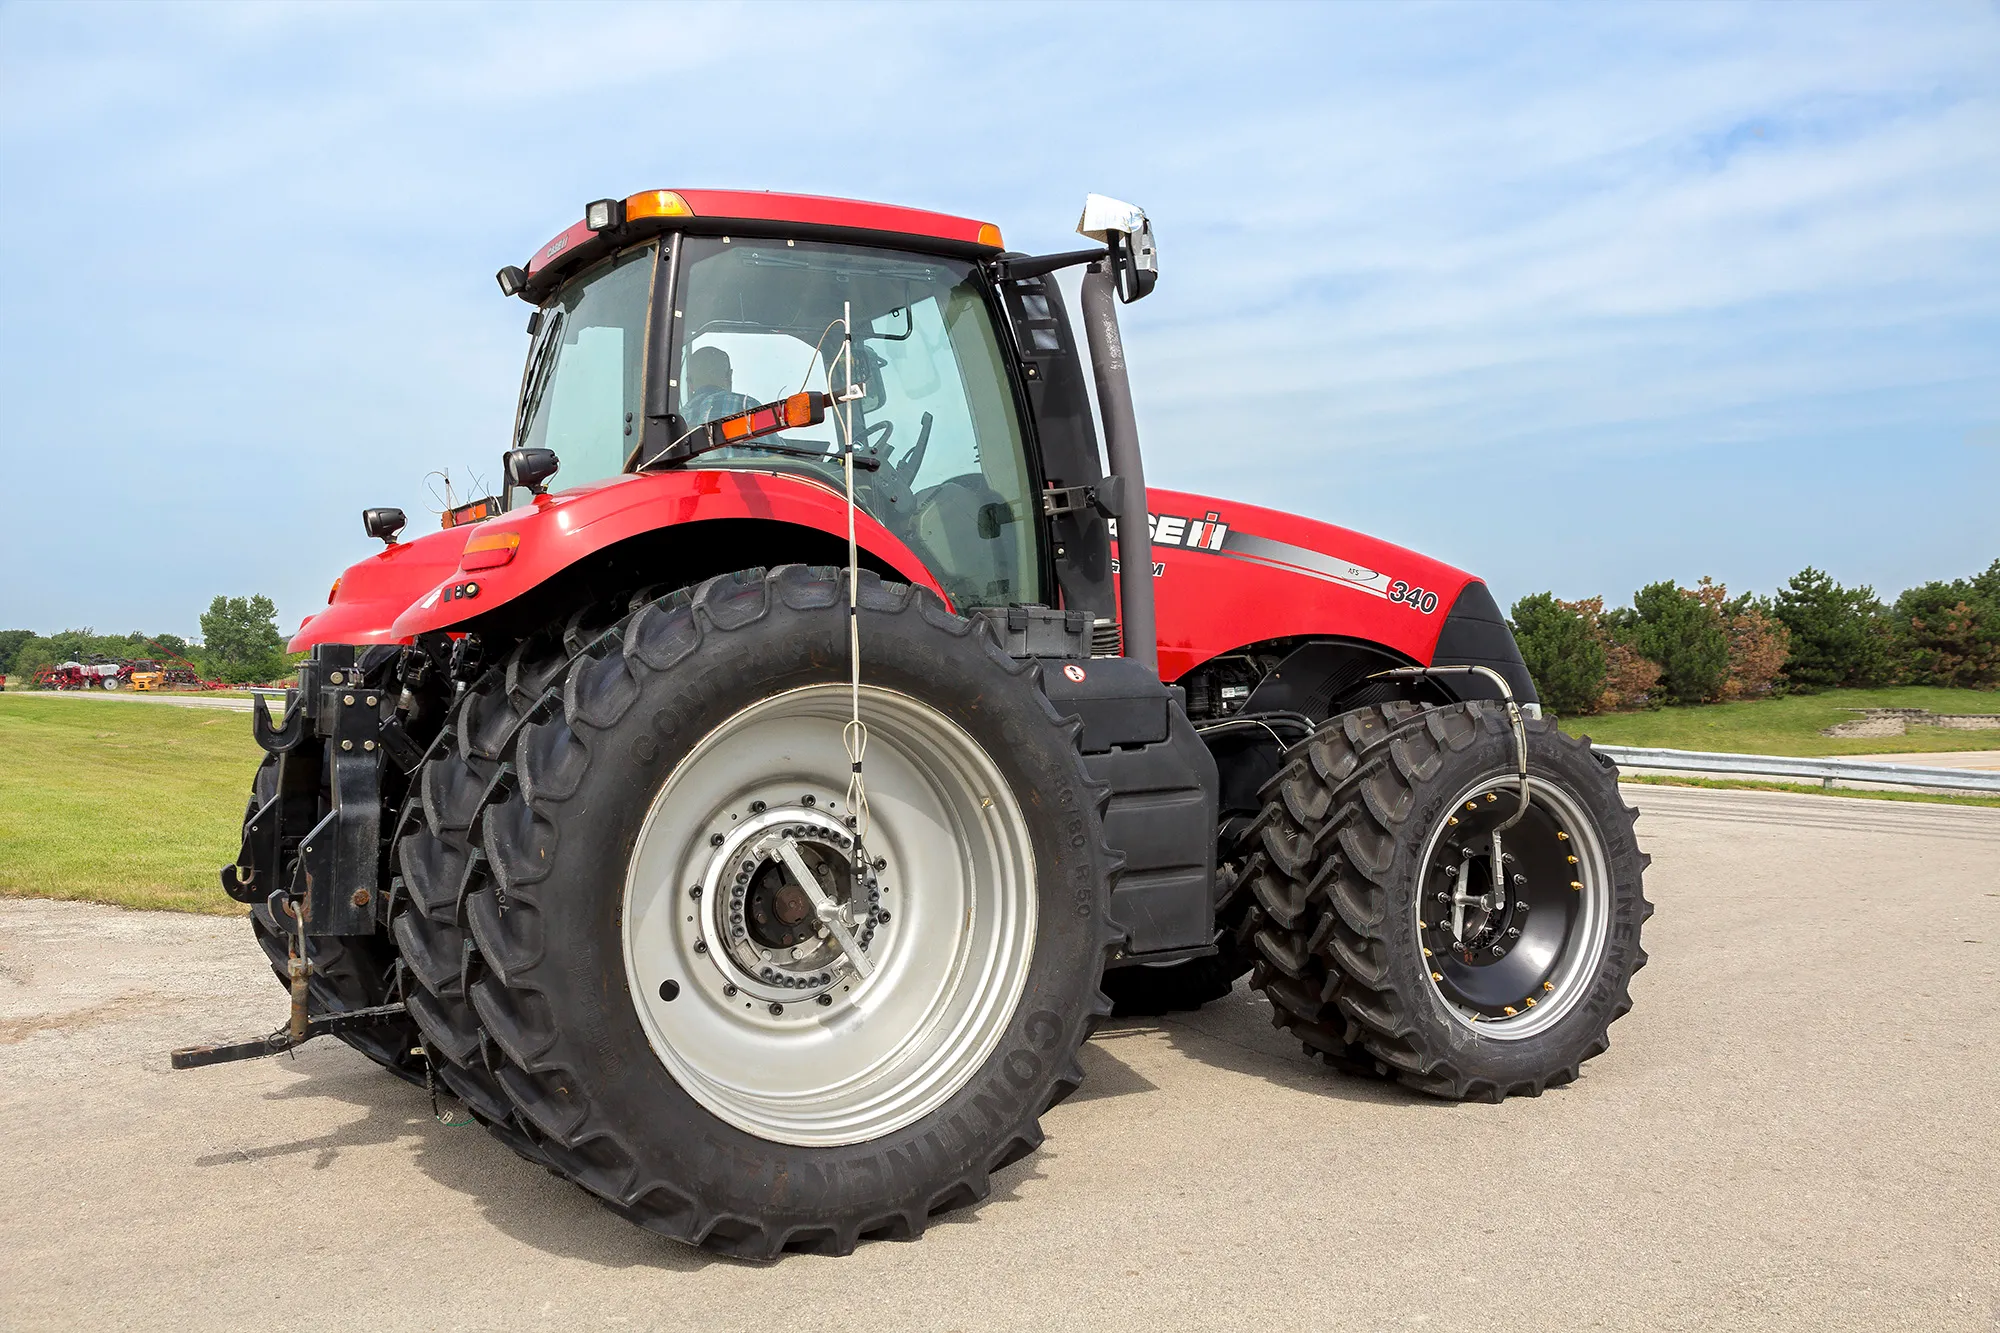 Agriculture Agricultural machinery Wheel loads, wheel torque, PTO power and forces on working parts, measured on the machine at work.
Other ways to measure torque
- At the power take-off PTO
Torque and speed at the power take-off, between the tractor and the implement, with nothing to modify.
- At the wheel Wheel torque transducers
Drive and brake torque at the wheel, while the vehicle is driven.
- On a shaft you cannot wire CBT-mini
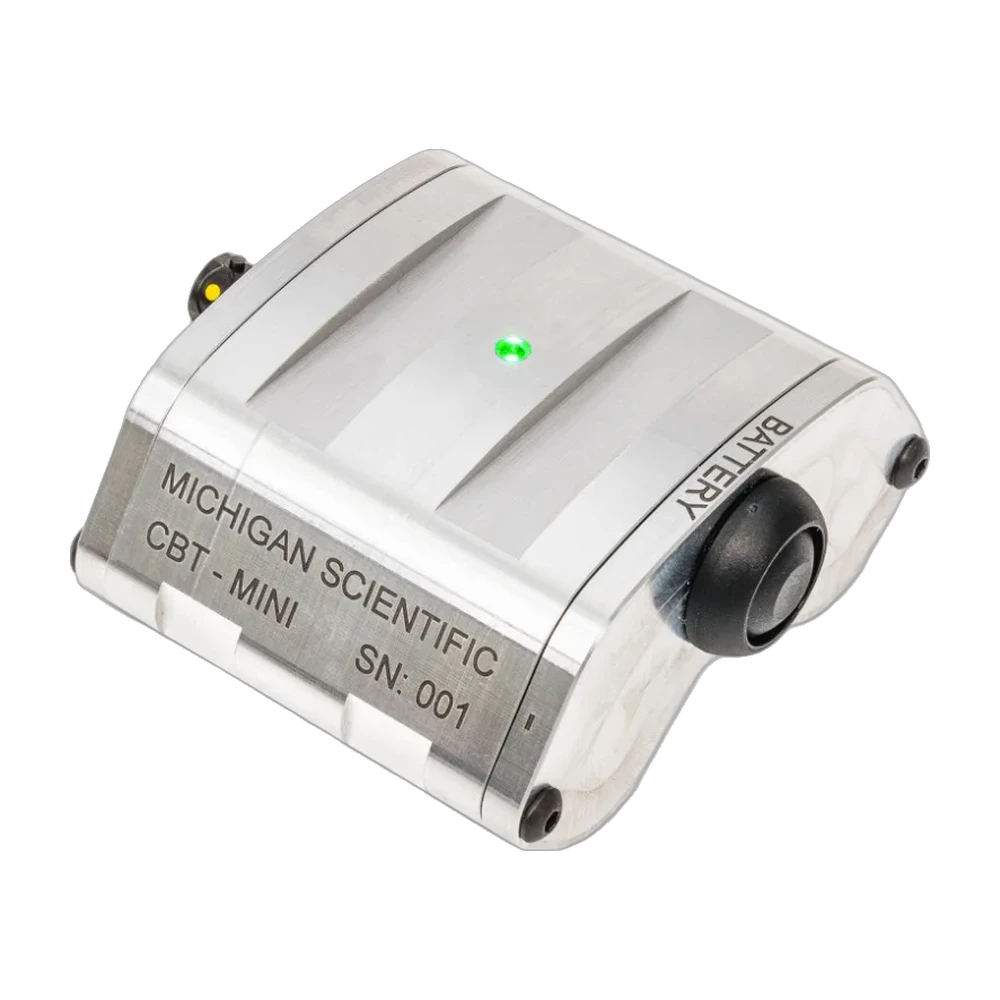
Battery-powered clamp-on telemetry transmitter for one full strain gage bridge, in an IP67 housing that straps to shafts of 25 mm or more, with a 2.4 GHz digital link.
A question on this product?
Describe the measurement. An application engineer answers.
More details to give? Use the full contact form.