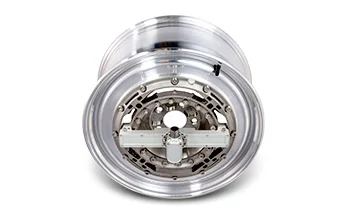
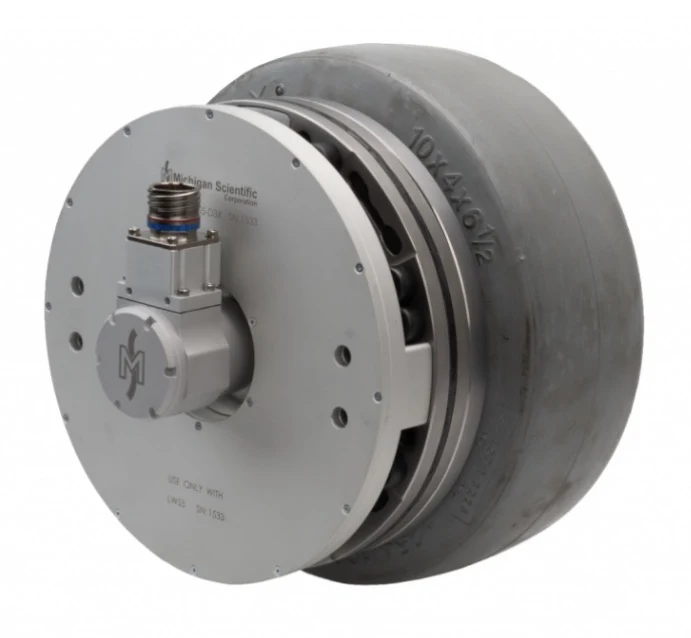
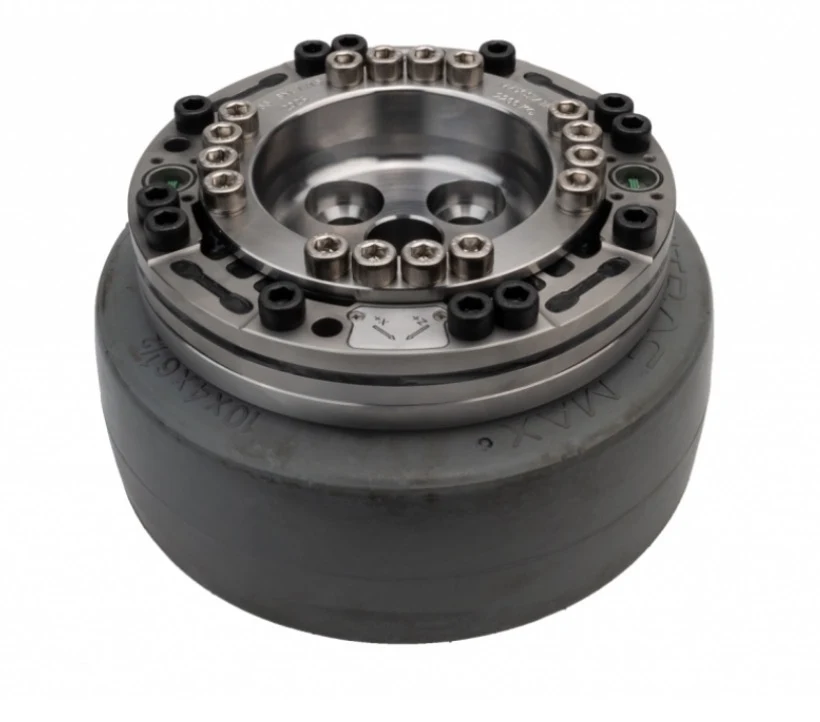
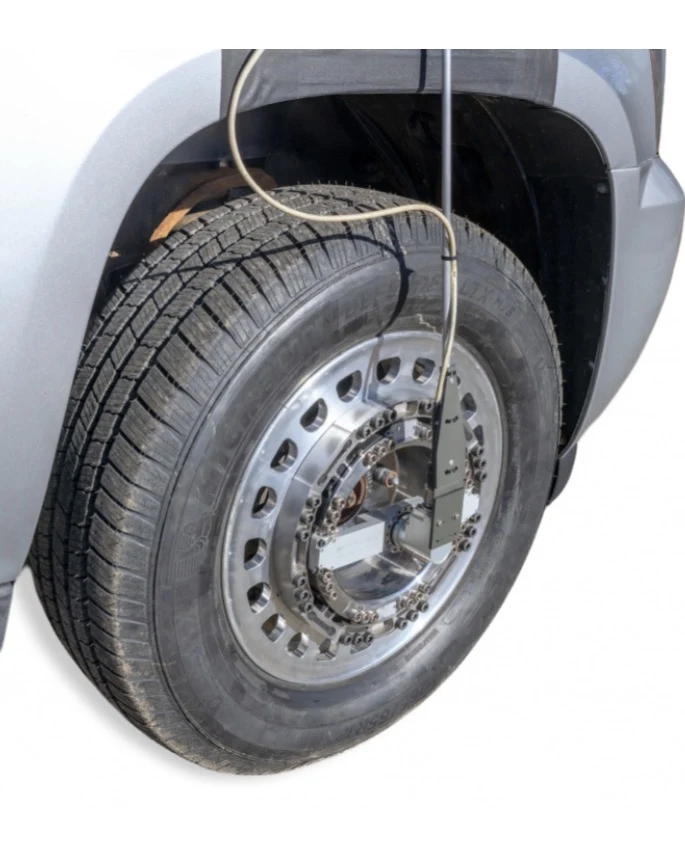
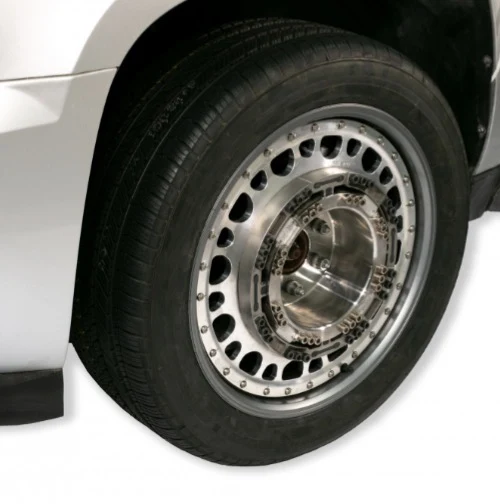
LW60 wheel force transducer
Six-axis wheel force transducer for passenger cars, SUVs and light trucks, 60 kN radial and 35 kN lateral, IP67, rated −40 to 177 °C, with slip ring or telemetry.
- 60 kN
- Fx, Fz capacity
- 35 kN
- Fy capacity
- 8.0 / 9.0 kN·m
- Moment capacity
- ≤ 0.25 % FS
- Non-linearity
- OutputsFx Fy Fz · Mx My Mz
- Also measuredX and Z acceleration (X, Y, Z on the LW50 and LW55) · wheel speed and angle
- Signal outputanalog · CAN · Ethernet · CAN FD and EtherCAT on the CT3
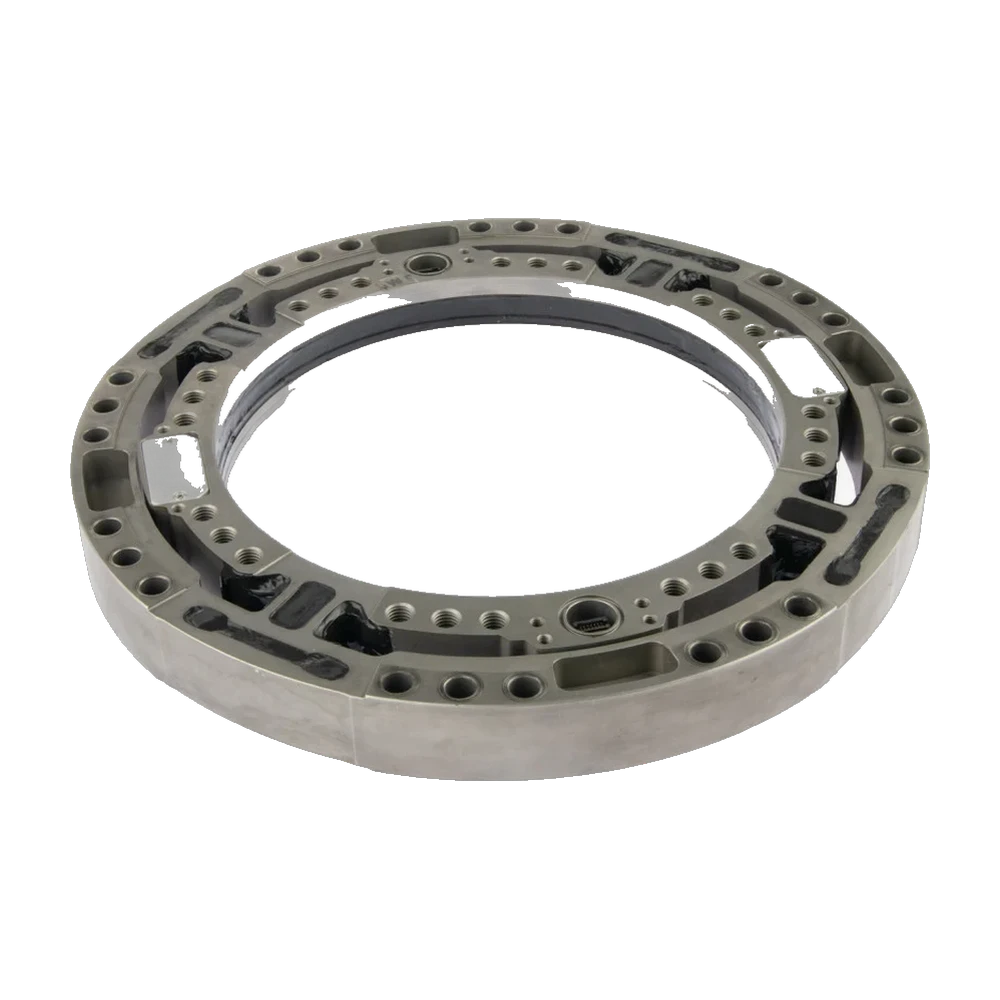
LW60: wheel force transducer for cars and SUVs, 60 kN
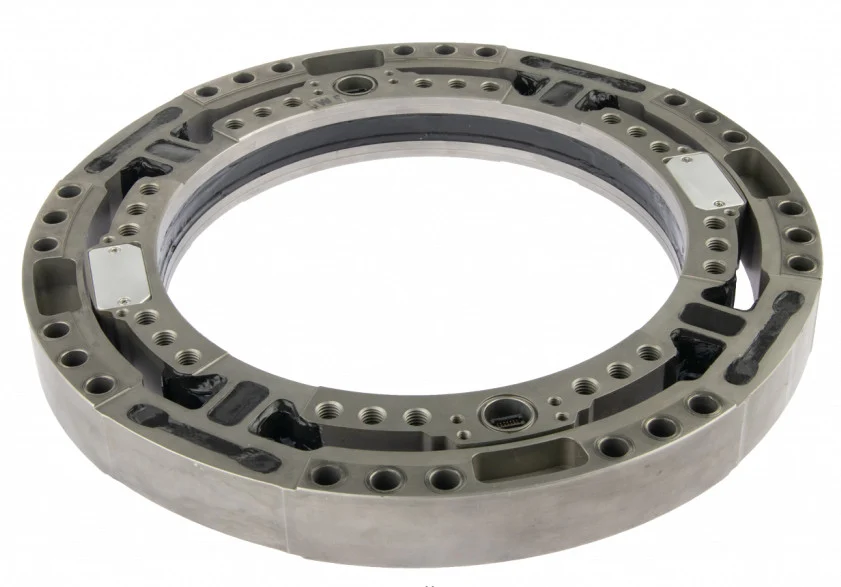
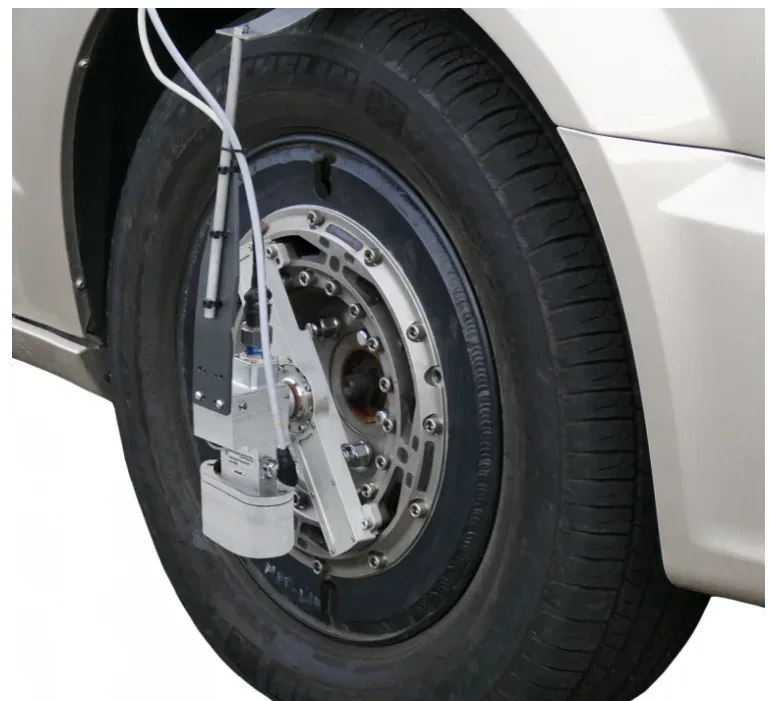
The LW60 measures all the wheel forces and moments on passenger cars, SUVs and light trucks, with X and Z accelerations up to ±100 g. It is rated 60 kN (13,400 lb) on Fx and Fz, 35 kN (7,850 lb) on Fy, 8.0 kN·m on Mx and Mz and 9.0 kN·m on My, for a static weight of 1,225 kg. Non-linearity and hysteresis are 0.25 % of full scale or less, cross-axis sensitivity after correction 0.4 % or less. The IP67 transducer, Ø 342.90 × 26.67 mm, weighs 5.7 kg, operates from −40 to 177 °C and adapts to 12 in and larger wheels.
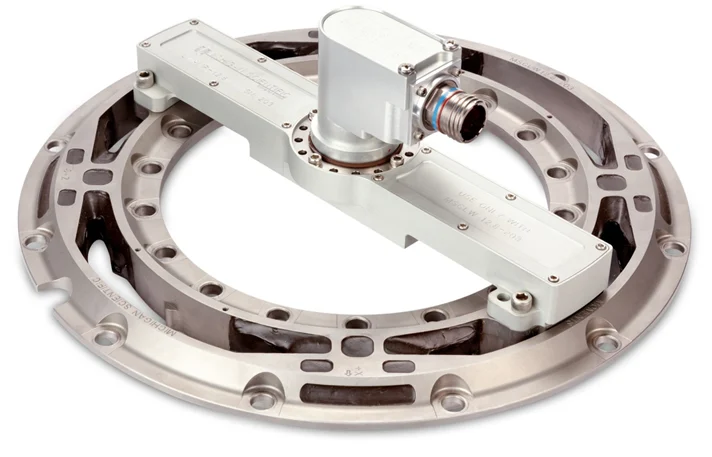
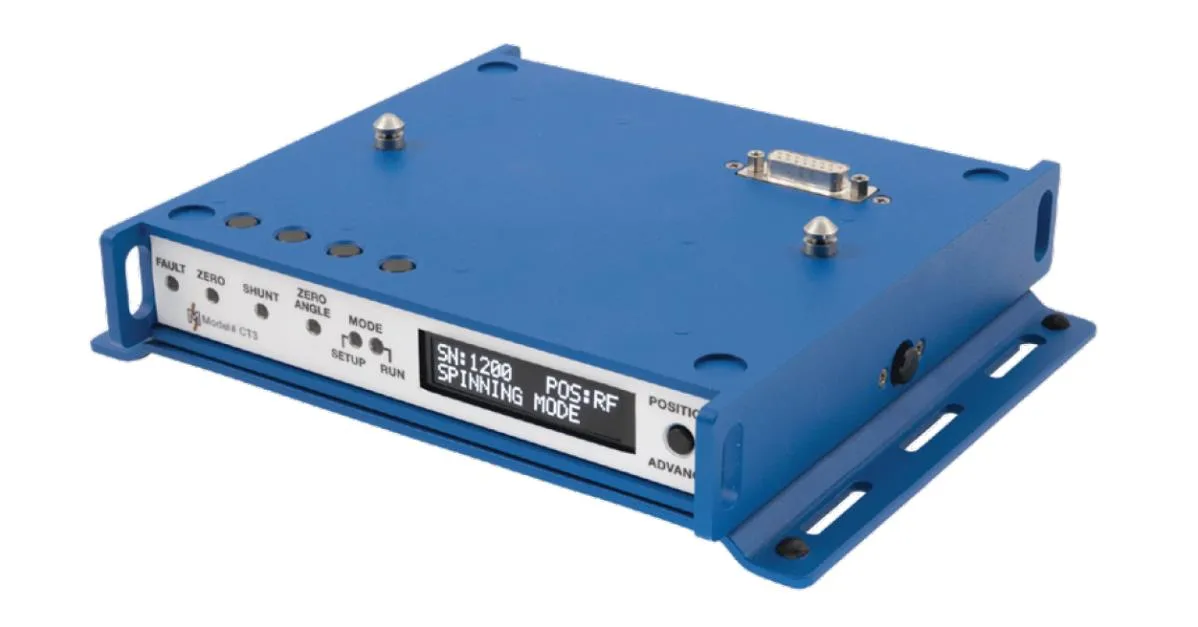
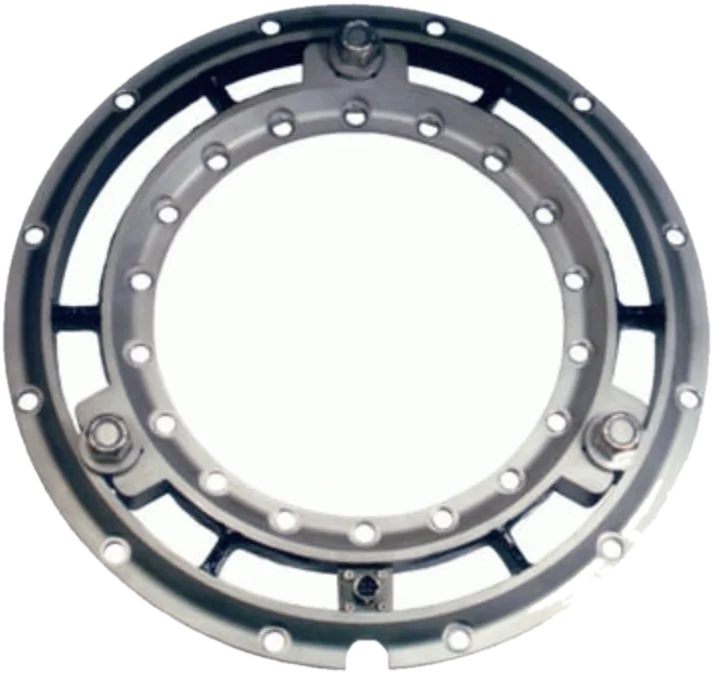
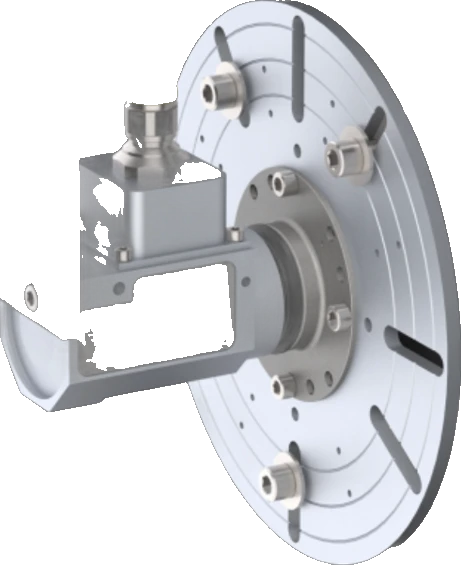
Sixteen M10 × 1.5 screws pass through the transducer into the rim adapter and twenty-four fasten the hub adapter, torqued crosswise to 81 N·m. The amplifier, matched to the transducer, aligns on a flat and carries a 20-circuit slip ring with a 512-pulse encoder; a magnetic restraint and rod hold its stator on non-steered wheels, a stator angle corrector on steered ones. With the CT3 interface box, powered at 9 to 36 V DC, the system is zeroed, its shunt calibration checked and the loads resolved into vehicle axes.
Its IP67 design suits track and off-road measurements and non-spinning test rigs. The telemetry package mounts inboard on cars and SUVs, or outboard for machinery applications.
Specifications
| Measured quantities | Fx · Fy · Fz · Mx · My · Mz |
|---|---|
| Force capacity | Fx 60 · Fy 35 · Fz 60 kN |
| Moment capacity | Mx 8 000 · My 9 000 · Mz 8 000 N·m |
| Max static load | 1 225 kg |
| Non-linearity | ≤ 0.25 % FS |
| Hysteresis | ≤ 0.25 % FS |
| Crosstalk | ≤ 0.4 % FS (after correction) |
| Angle resolution | 0.17° |
| Axes | 6 |
| Accelerometer range | 100 g (X and Z) |
| Output | Analog voltage · CAN · CAN FD · Ethernet · EtherCAT (CT3; EtherCAT with an add-on module) |
| Signal transmission | Slip ring · Telemetry (slip ring outboard; telemetry inboard or outboard) |
| Shaft diameter | 228.6 mm (center bore) |
| Mounting fasteners | 24 × M10 × 1.5 |
| Rim fasteners | 16 × Ø 10.32 mm (through) |
| Bolt circle | 255.27 mm |
| Rim bolt circle | 325.12 mm |
| Dimensions | Ø 342.9 × 26.67 mm |
| Weight | 5.7 kg |
| Operating temperature | −40 to 177 °C |
| Protection | IP67 |
| Interface box | CT3 |
| Vehicles | Passenger cars · SUVs · Light trucks |
| Rim size | 12 in (and larger) |
Request a quote
Unusual bolt pattern, motorsport hub, agricultural wheel: we build it around your wheel.
Used with the LW series
What you add here goes into the same quote request.
-
Measure on a steered wheel
SAC stator angle corrector
Corrects the rotation angle signal in real time for the coordinate transformation, with no over-the-wheel bracket. Internal encoder accuracy ≤ 0.25°, IP67.
Slip ring versions, with the CT3 interface box.
Resources
Datasheets and manuals
Drawings
None for LW60.
CAD models
Related applications
-
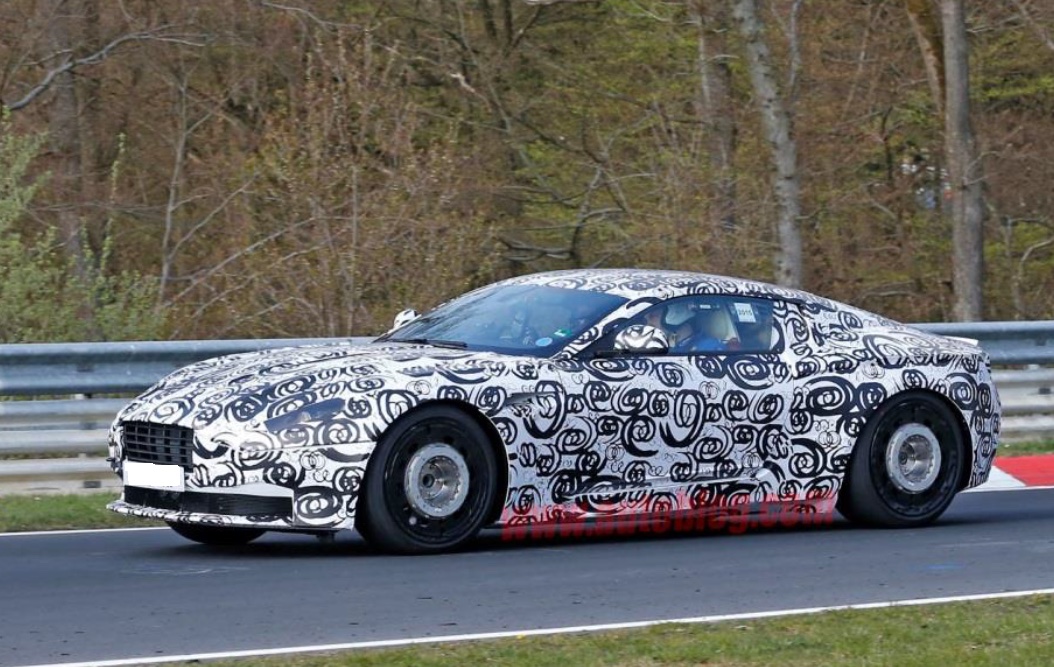 Durability Wheel loads on the road Three forces and three moments at each wheel, recorded while the vehicle is driven.
-
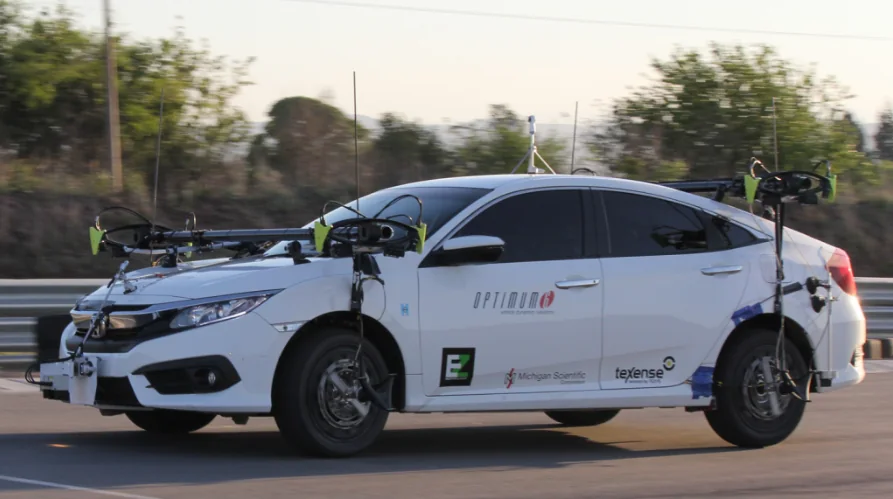 Dynamics Vehicle dynamics The forces and moments at each wheel while the vehicle brakes, turns and changes lane.
-
 Dynamics Side slip angle Side slip angle read without contact by an optical sensor, on a wheel or on the vehicle body.
-
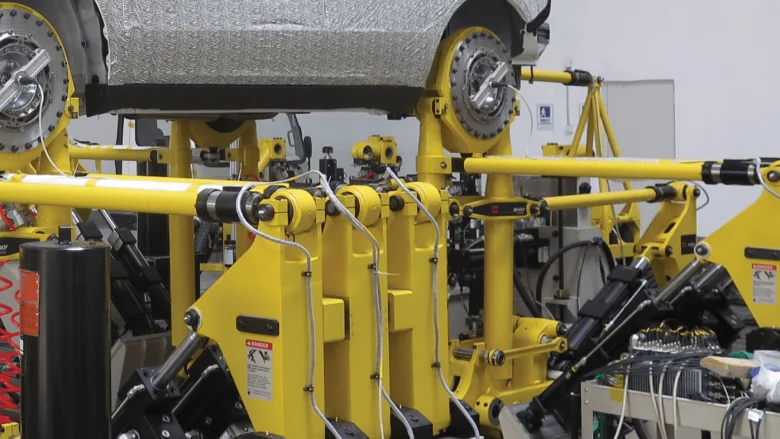 Test rig Road simulators The loads measured at the wheel on the road, and the proof that the simulator reproduces them.
If a six-axis wheel is not what you need
- Torque only TW series wheel torque transducers
Drive and brake torque My at the wheel, 237 N·m to 81 kN·m.
- Signals from the series wheel Wheel instrumentation system
Strain gages, thermocouples and wheel speed, on the wheel the vehicle already has.
- Force on a part, not a wheel TR3D-B three-axis load cells
Three orthogonal forces from 1.1 to 71 kN per axis.
A question on this product?
Vehicle, wheel size, expected loads. An application engineer answers.
More details to give? Use the full contact form.