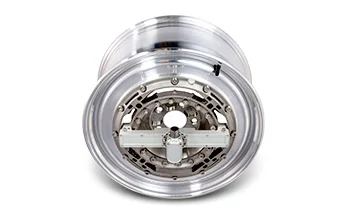
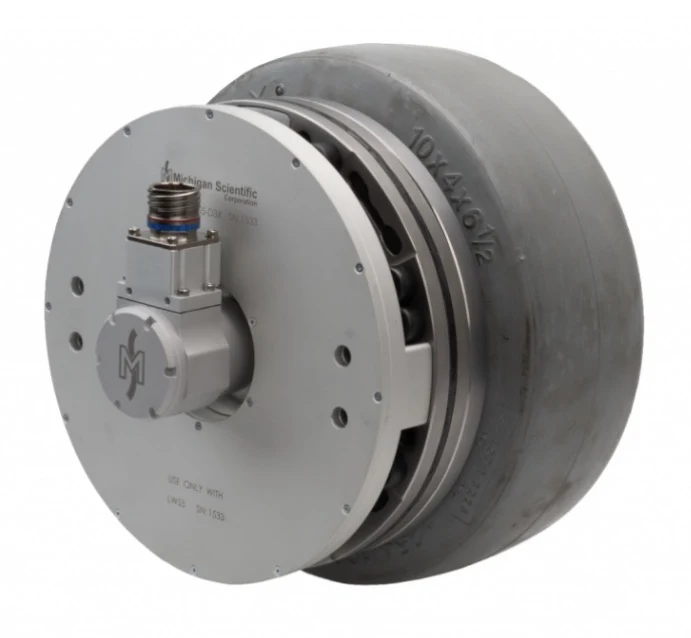
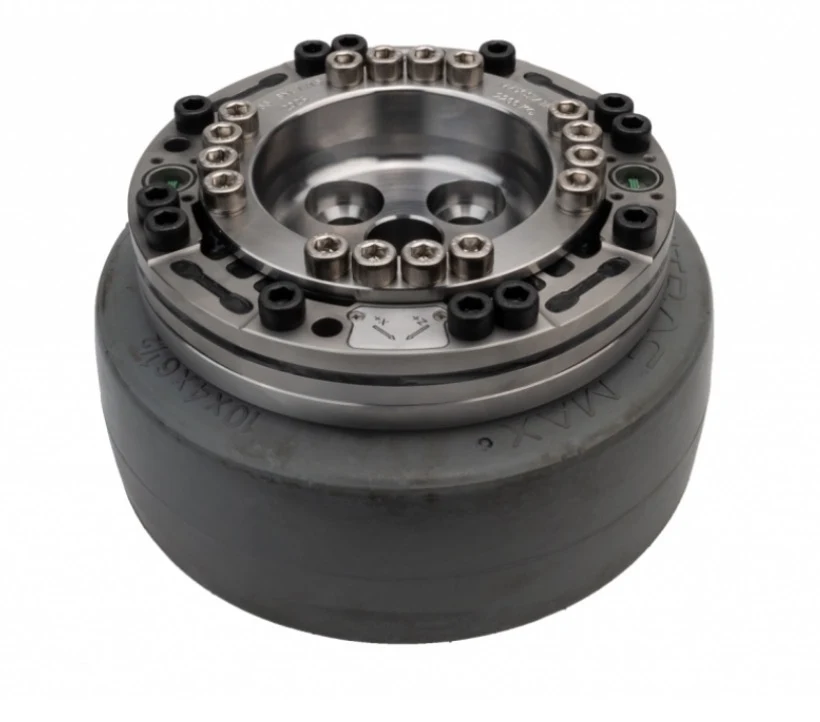
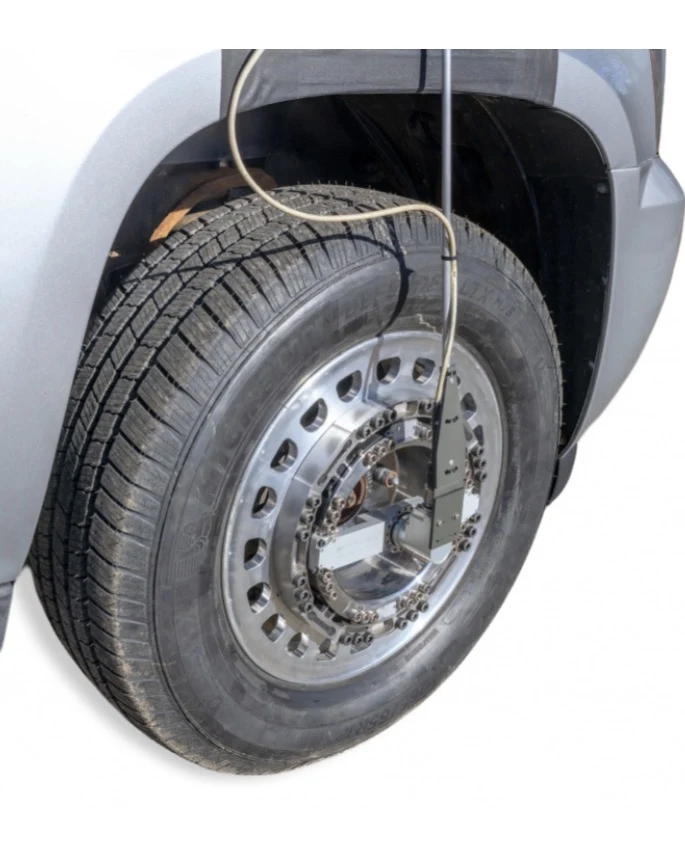
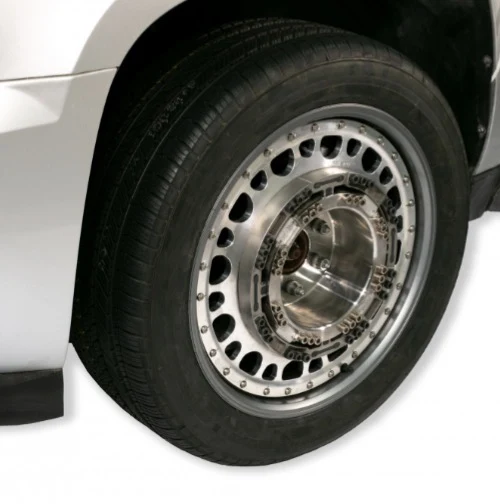
LW700 wheel force transducer
Six-axis wheel force transducer for standard hubs with a 425 mm PCD, 700 kN per force and 275 kN·m per moment, sealed to IP67, with slip ring or telemetry.
- 700 kN
- Fx, Fz capacity
- 700 kN
- Fy capacity
- 275 kN·m
- Moment capacity
- ≤ 0.5 % FS
- Non-linearity
- OutputsFx Fy Fz · Mx My Mz
- Also measuredX and Z acceleration (X, Y, Z on the LW50 and LW55) · wheel speed and angle
- Signal outputanalog · CAN · Ethernet · CAN FD and EtherCAT on the CT3
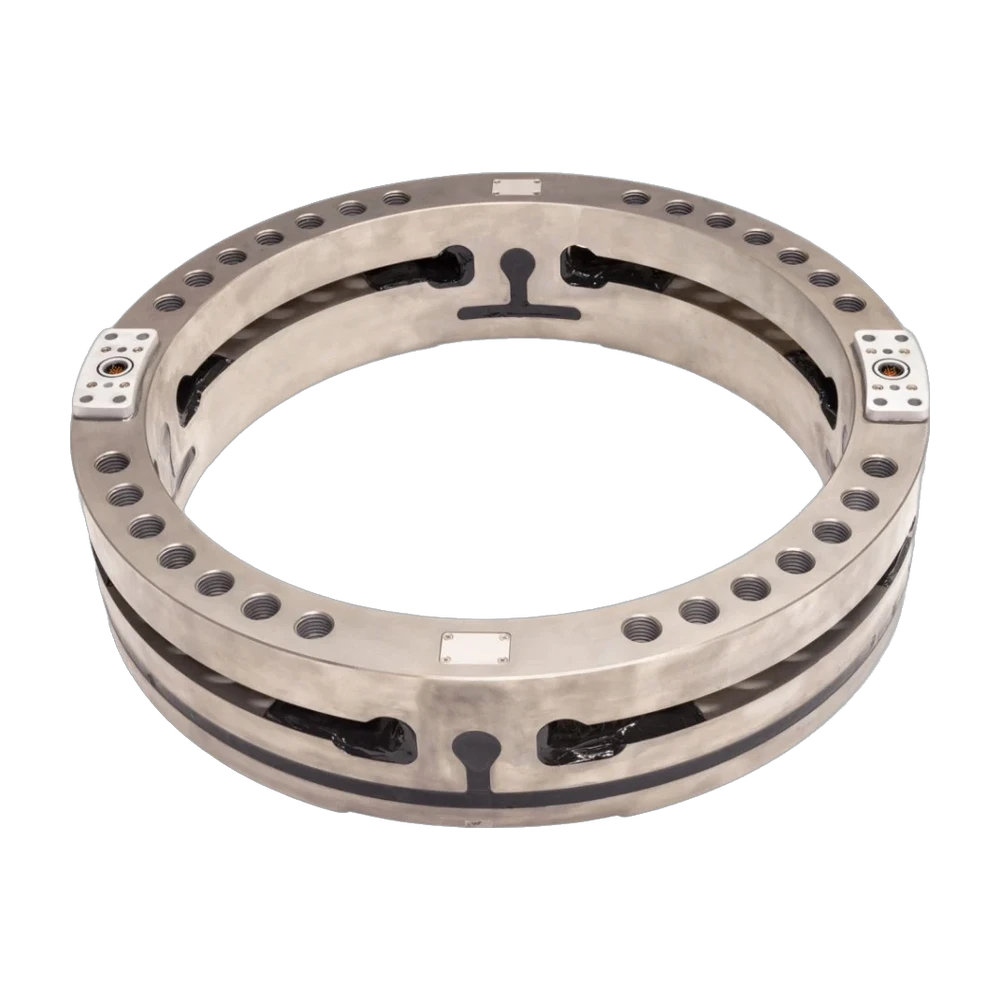
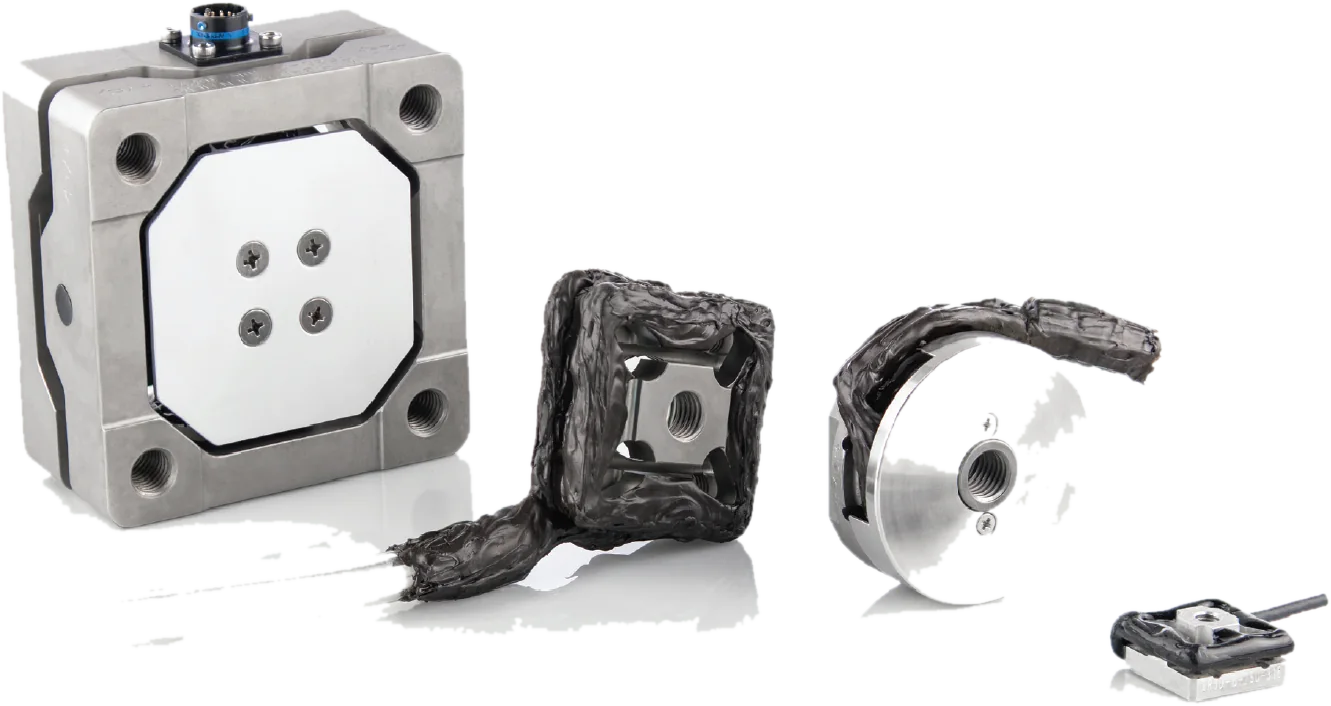
LW700: wheel force transducer, 700 kN
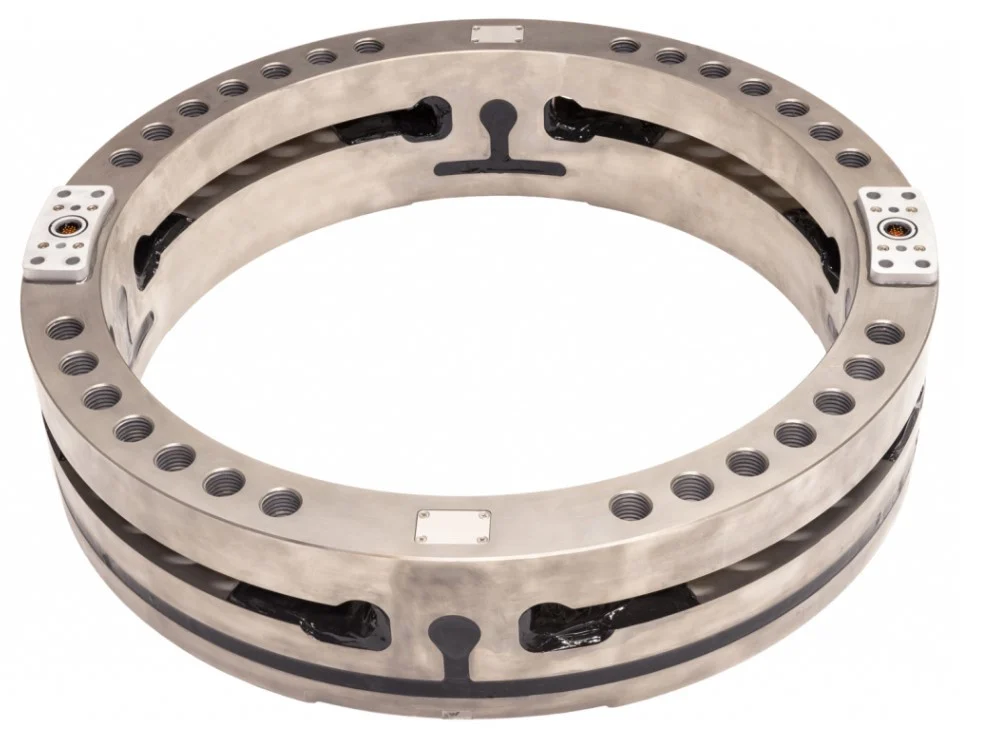
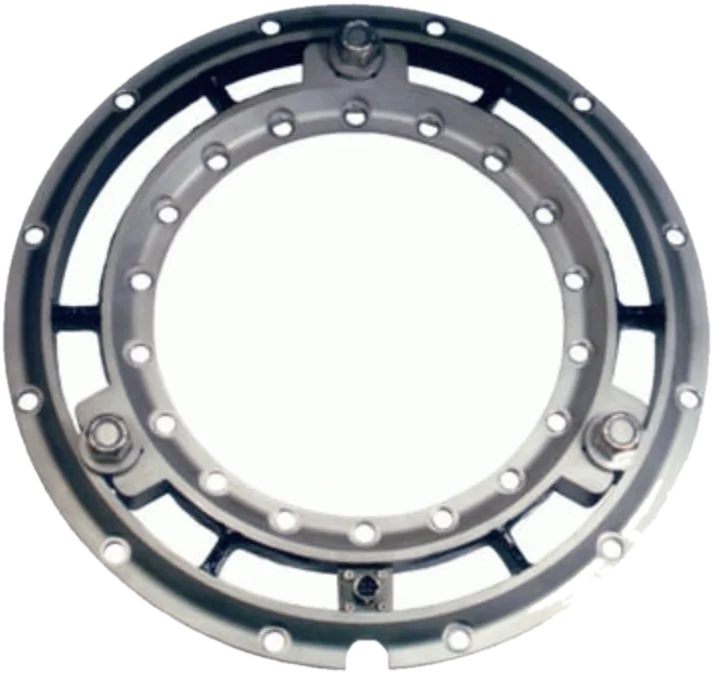
The LW700 measures all the wheel forces and moments: vertical, lateral and longitudinal forces up to 700 kN each (Fx, Fy, Fz), and camber, steer and torque moments of 275 kN·m each. The maximum recommended static load is 23,800 kg. Non-linearity and hysteresis are 0.5 % of full scale or less, and cross-axis sensitivity after correction 0.2 %. Of robust IP67 design, the transducer weighs 64.5 kg and fits standard hubs with a 425 mm pitch circle diameter. Its ± 100 g accelerometers give X and Z accelerations, and an encoder gives wheel position and speed.
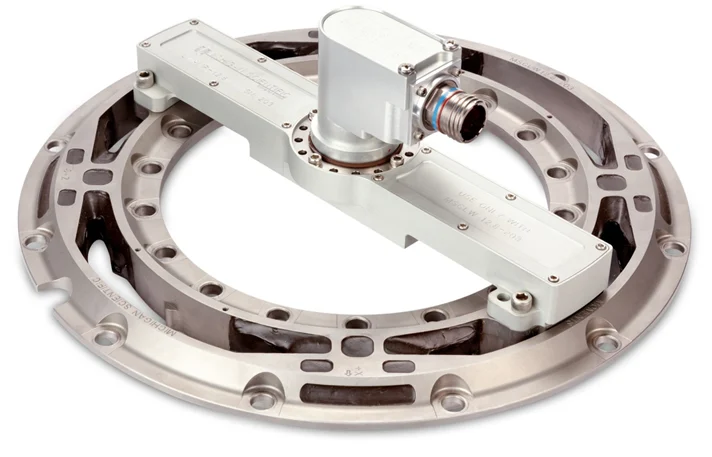
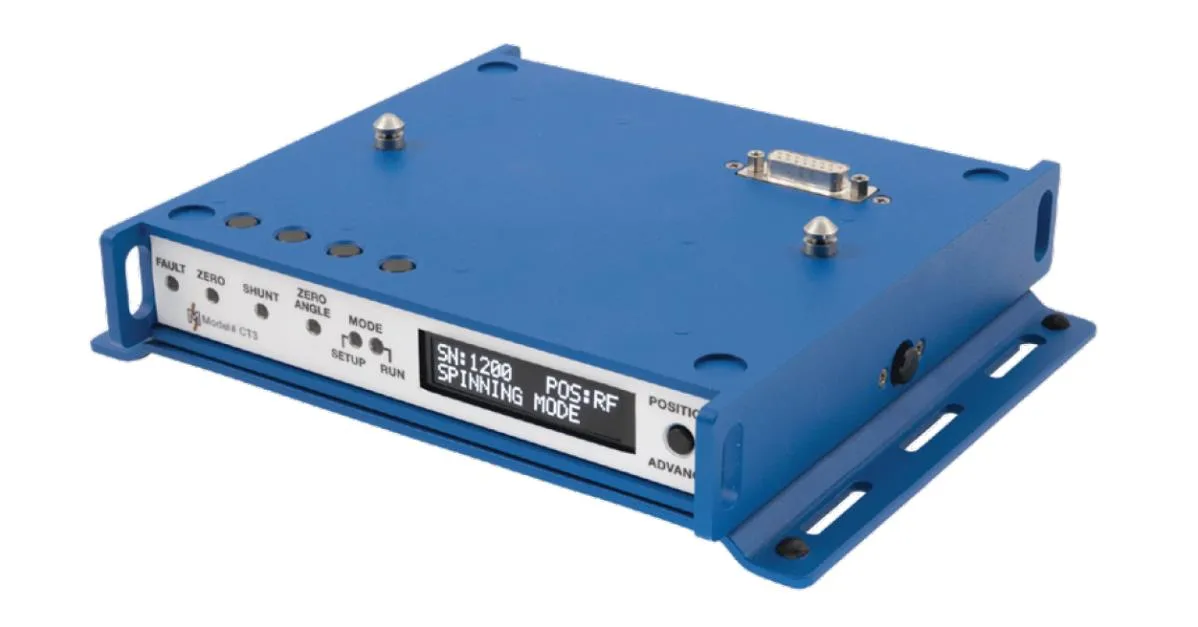
In spinning use, the signals leave through an outboard slip ring, with the amplifier package mounted onto the transducer, or through inboard telemetry, whose stator, mounted close to the rotating telemetry ring, holds the receiver, the encoder pick-ups and the induction coil; the CT3 box then also supplies the induction power. The CT3 performs coordinate transformation and crosstalk, offset and polarity correction, with zero, shunt calibration check and zero angle functions; its embedded web page, reached over USB, sets up the system and moves the measurement origin.
Its robust IP67 design suits the harshest track and off-road measurements; in non-spinning applications, the LW700 is used to monitor and control laboratory test rigs.
Specifications
| Measured quantities | Fx · Fy · Fz · Mx · My · Mz |
|---|---|
| Force capacity | Fx 700 · Fy 700 · Fz 700 kN |
| Moment capacity | Mx 275 000 · My 275 000 · Mz 275 000 N·m |
| Max static load | 23 800 kg |
| Non-linearity | ≤ 0.5 % FS |
| Hysteresis | ≤ 0.5 % FS |
| Crosstalk | ≤ 0.2 % FS (after correction) |
| Axes | 6 |
| Accelerometer range | 100 g |
| Signal transmission | Slip ring · Telemetry |
| Weight | 64.5 kg |
| Protection | IP67 |
| Interface box | CT3 |
| Hub bolt pattern | 425 mm (standard hubs) |
Request a quote
Unusual bolt pattern, motorsport hub, agricultural wheel: we build it around your wheel.
Used with the LW series
What you add here goes into the same quote request.
-
Measure on a steered wheel
SAC stator angle corrector
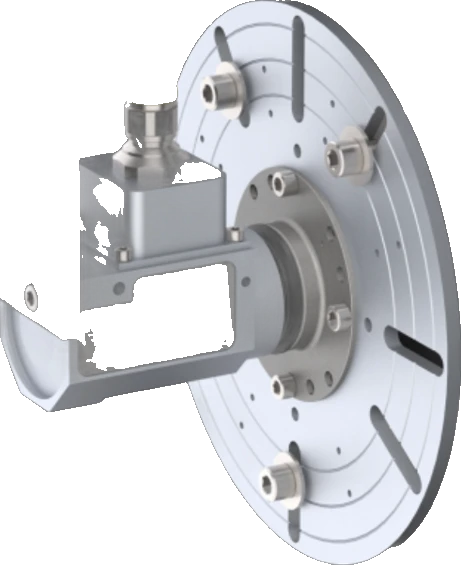
Corrects the rotation angle signal in real time for the coordinate transformation, with no over-the-wheel bracket. Internal encoder accuracy ≤ 0.25°, IP67.
Slip ring versions, with the CT3 interface box.
Resources
Datasheets and manuals
Drawings
None for LW700.
CAD models
None for LW700.
Guides and notes
Related applications
-
 Durability Wheel loads on the road Three forces and three moments at each wheel, recorded while the vehicle is driven.
-
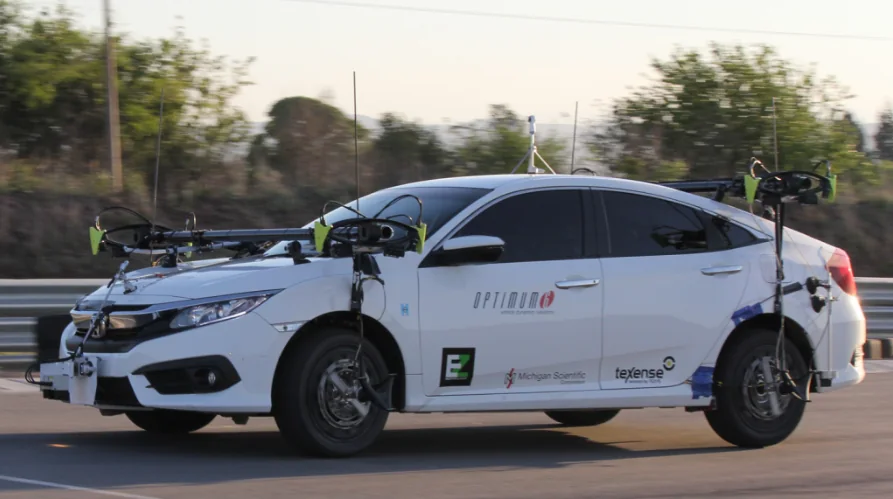 Dynamics Vehicle dynamics The forces and moments at each wheel while the vehicle brakes, turns and changes lane.
-
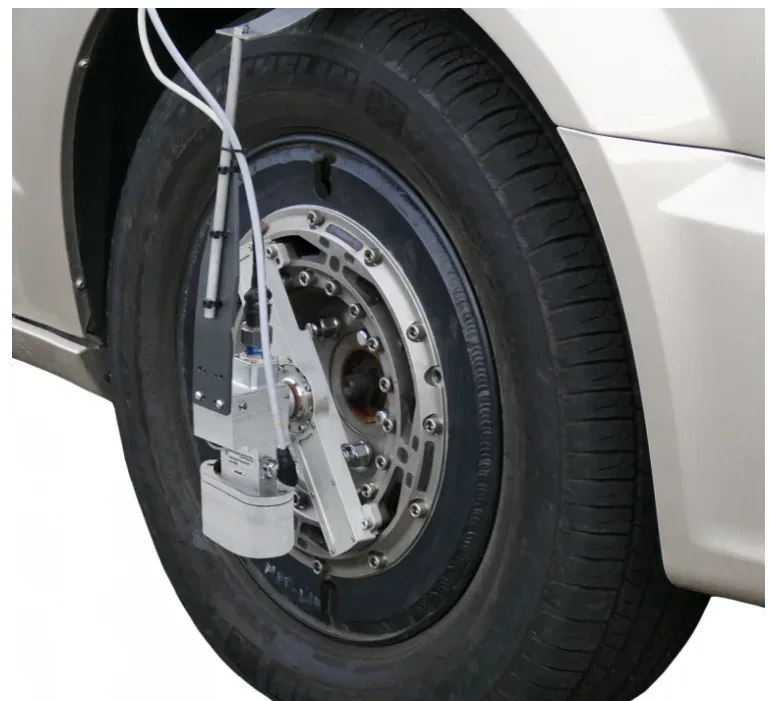 Dynamics Side slip angle Side slip angle read without contact by an optical sensor, on a wheel or on the vehicle body.
-
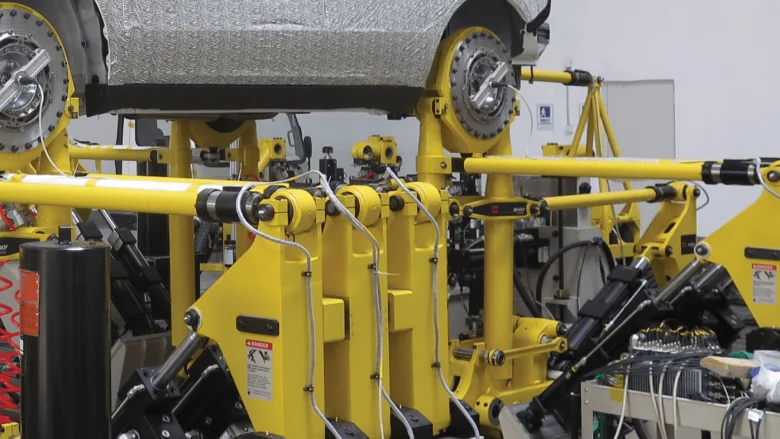 Test rig Road simulators The loads measured at the wheel on the road, and the proof that the simulator reproduces them.
If a six-axis wheel is not what you need
- Torque only TW series wheel torque transducers
Drive and brake torque My at the wheel, 237 N·m to 81 kN·m.
- Signals from the series wheel Wheel instrumentation system
Strain gages, thermocouples and wheel speed, on the wheel the vehicle already has.
- Force on a part, not a wheel TR3D-B three-axis load cells
Three orthogonal forces from 1.1 to 71 kN per axis.
A question on this product?
Vehicle, wheel size, expected loads. An application engineer answers.
More details to give? Use the full contact form.