
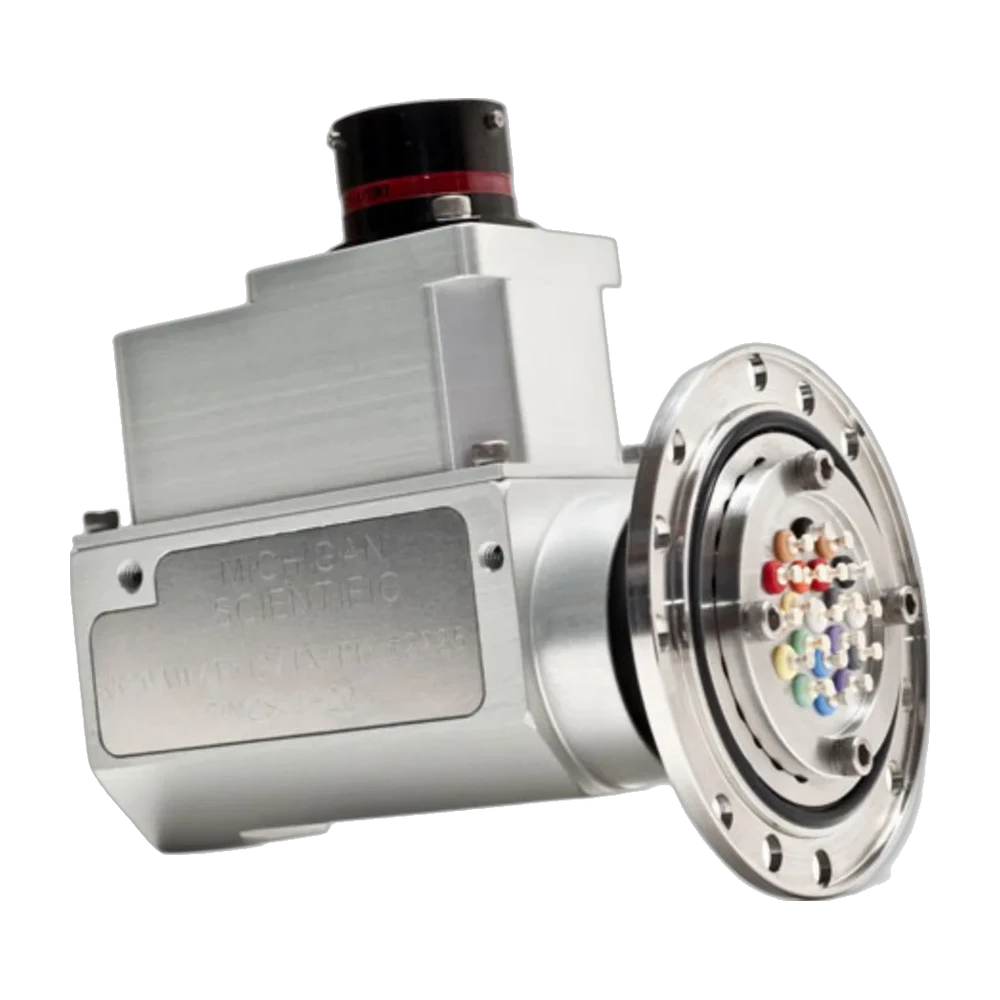
SR/ERT Series slip rings with encoder
Ten-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor, without encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Ten-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Weatherproof ten-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor, without encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Weatherproof ten-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Ten-circuit end-of-shaft slip ring with a 50.8 mm (2 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Weatherproof ten-circuit end-of-shaft slip ring with a 50.8 mm (2 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
20-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor, without encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
20-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Weatherproof 20-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor, without encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Weatherproof 20-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
20-circuit end-of-shaft slip ring with a 50.8 mm (2 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Weatherproof 20-circuit end-of-shaft slip ring with a 50.8 mm (2 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
36-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor, without encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
36-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Weatherproof 36-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor, without encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Weatherproof 36-circuit end-of-shaft slip ring with a 63.5 mm (2.5 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
36-circuit end-of-shaft slip ring with a 50.8 mm (2 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Weatherproof 36-circuit end-of-shaft slip ring with a 50.8 mm (2 in) rotor and a built-in optical encoder, for low-level signals: strain gages, thermocouples, accelerometers and low voltages.
Model SR10A/E512/AX
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- None
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 80 mm · 397 g
- Length · weight
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 80 mm · 397 g
- Length · weight
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 80 mm · 397 g
- Length · weight
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 80 mm · 397 g
- Length · weight
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- None
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 80 mm · 397 g
- Length · weight
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 80 mm · 397 g
- Length · weight
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 80 mm · 397 g
- Length · weight
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 80 mm · 397 g
- Length · weight
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 10 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 10
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- None
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 93 mm · 425 g
- Length · weight
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 93 mm · 425 g
- Length · weight
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 93 mm · 425 g
- Length · weight
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 93 mm · 425 g
- Length · weight
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- None
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 93 mm · 425 g
- Length · weight
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 93 mm · 425 g
- Length · weight
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 93 mm · 425 g
- Length · weight
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 93 mm · 425 g
- Length · weight
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr
- Encoder
- 93 mm · 369 g
- Length · weight
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr
- Encoder
- 93 mm · 369 g
- Length · weight
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr
- Encoder
- 93 mm · 369 g
- Length · weight
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr
- Encoder
- 93 mm · 369 g
- Length · weight
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 4 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr
- Encoder
- 93 mm · 369 g
- Length · weight
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr
- Encoder
- 93 mm · 369 g
- Length · weight
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr
- Encoder
- 93 mm · 369 g
- Length · weight
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr
- Encoder
- 93 mm · 369 g
- Length · weight
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 20
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 36
- Circuits
- 2 400 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- None
- Encoder
- 36
- Circuits
- 2 400 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 115 mm · 482 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 115 mm · 482 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 115 mm · 482 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 115 mm · 482 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 36
- Circuits
- 2 400 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 36
- Circuits
- 2 400 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 36
- Circuits
- 2 400 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 36
- Circuits
- 2 400 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 36
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- None
- Encoder
- 36
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr
- Encoder
- 115 mm · 482 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr
- Encoder
- 115 mm · 482 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr
- Encoder
- 115 mm · 482 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr
- Encoder
- 115 mm · 482 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 36
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 36
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 36
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 36
- Circuits
- 2 000 rpm
- Max speed
- 63.5 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 36
- Circuits
- 2 400 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr
- Encoder
- 115 mm · 369 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr
- Encoder
- 115 mm · 369 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr
- Encoder
- 115 mm · 369 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr
- Encoder
- 115 mm · 369 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 115 mm · 425 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 115 mm · 425 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 115 mm · 425 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 115 mm · 425 g
- Length · weight
- 36
- Circuits
- 2 400 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- 36
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr
- Encoder
- 115 mm · 369 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr
- Encoder
- 115 mm · 369 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr
- Encoder
- 115 mm · 369 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr
- Encoder
- 115 mm · 369 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 256 ppr, tachometer outputs
- Encoder
- 115 mm · 425 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr, tachometer outputs
- Encoder
- 115 mm · 425 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 500 ppr, tachometer outputs
- Encoder
- 115 mm · 425 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 512 ppr, tachometer outputs
- Encoder
- 115 mm · 425 g
- Length · weight
- 36
- Circuits
- 2 000 rpm
- Max speed
- 50.8 mm
- Rotor diameter
- 360 ppr, resolver outputs
- Encoder
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length80 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length80 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length80 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length80 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length80 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length80 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length80 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length80 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length93 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
- Length115 mm
- Max current per circuit500 mA
Ten-circuit end-of-shaft slip ring, 63.5 mm rotor
This end-of-shaft slip ring has ten gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its stainless steel rotor has a 63.5 mm (2.5 in) flange with a circular connector, and its anodized aluminum stator a radial circular connector. It runs up to 10 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. A rotation restraint is attached to the threaded holes of the stator.
Ten-circuit end-of-shaft slip ring and encoder, 63.5 mm rotor
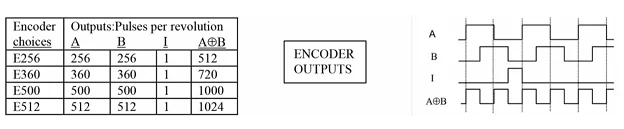
This end-of-shaft slip ring has ten gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Its stainless steel rotor has a 63.5 mm (2.5 in) flange, and its anodized aluminum stator a radial Bendix PT02E-14-19P connector. It is 80 mm long, weighs 397 g and runs up to 10 000 rpm, from −40 to 85 °C.
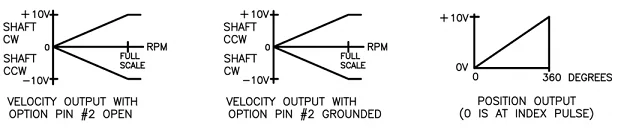
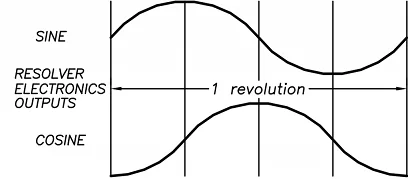
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. A rotation restraint is attached to the threaded holes of the stator. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add either tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC, or, with the 360 ppr encoder, resolver outputs (R), sine and cosine up to ±10 V.
It is used, for example, on a gaged accessory belt pulley, where speed, angle and direction of rotation are recorded with the torque, or on a running engine’s crankshaft.
Weatherproof ten-circuit end-of-shaft slip ring, 63.5 mm rotor
This end-of-shaft slip ring has ten gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Contacting rotary seals make it completely weatherproof. Its stainless steel rotor has a 63.5 mm (2.5 in) flange with a circular connector, and its anodized aluminum stator a radial circular connector. It runs up to 2 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. Connector plugs are sealed at the rear with RTV silicone or a sealing backshell, whose tube can hold the stator against a wheel-well bracket.
Weatherproof ten-circuit end-of-shaft slip ring and encoder, 63.5 mm rotor
This end-of-shaft slip ring has ten gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Contacting rotary seals make it completely weatherproof. Its stainless steel rotor has a 63.5 mm (2.5 in) flange, and its anodized aluminum stator a radial Bendix PT02E-14-19P connector. It is 80 mm long, weighs 397 g and runs up to 2 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. Connector plugs are sealed at the rear with RTV silicone or a sealing backshell, whose tube can hold the stator against a wheel-well bracket. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add either tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC, or, with the 360 ppr encoder, resolver outputs (R), sine and cosine up to ±10 V.
It is used, for example, with tachometer outputs as an SR10AW/T512/AX2 on Michigan Scientific’s 152 mm (6 in) Wheel Instrumentation Package WIP6-SG-TC2K, with a strain gage amplifier and two thermocouple amplifiers.
Ten-circuit end-of-shaft slip ring and encoder, 50.8 mm rotor
This end-of-shaft slip ring has ten gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Its stainless steel rotor has a 50.8 mm (2 in) flange with color-coded solder terminals, and its anodized aluminum stator a radial circular connector. It runs up to 10 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft. A rotation restraint is attached to the threaded holes of the stator. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC.
It is used, for example, on a running engine’s crankshaft, where the encoder records crank speed and position while all the rings stay available for the strain channels.
Weatherproof ten-circuit end-of-shaft slip ring and encoder, 50.8 mm rotor
This end-of-shaft slip ring has ten gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Contacting rotary seals make it completely weatherproof. Its stainless steel rotor has a 50.8 mm (2 in) flange with color-coded solder terminals, and its anodized aluminum stator a radial circular connector. It runs up to 2 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft. Connector plugs are sealed at the rear with RTV silicone or a sealing backshell, whose tube can hold the stator against a wheel-well bracket. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC.
It is used in wet-weather applications such as automotive wheels, which mostly stay within 2 000 rpm; on torque wheels, the tachometer outputs are normally set to 10 V at 1 000 or 1 800 rpm.
20-circuit end-of-shaft slip ring, 63.5 mm rotor
This end-of-shaft slip ring has 20 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its stainless steel rotor has a 63.5 mm (2.5 in) flange with a circular connector, and its anodized aluminum stator a radial circular connector. It runs up to 4 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. A rotation restraint is attached to the threaded holes of the stator.
20-circuit end-of-shaft slip ring and encoder, 63.5 mm rotor
This end-of-shaft slip ring has 20 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Its stainless steel rotor has a 63.5 mm (2.5 in) flange, and its anodized aluminum stator a radial Bendix PT02E-16-26P connector. It is 93 mm long, weighs 425 g and runs up to 4 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. A rotation restraint is attached to the threaded holes of the stator. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add either tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC, or, with the 360 ppr encoder, resolver outputs (R), sine and cosine up to ±10 V.
It is used, for example, on a running engine’s crankshaft, for torque, bending and fillet strain, with crank speed and position from the encoder.
Weatherproof 20-circuit end-of-shaft slip ring, 63.5 mm rotor
This end-of-shaft slip ring has 20 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Contacting rotary seals make it completely weatherproof. Its stainless steel rotor has a 63.5 mm (2.5 in) flange with a circular connector, and its anodized aluminum stator a radial circular connector. It runs up to 2 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. Connector plugs are sealed at the rear with RTV silicone or a sealing backshell, whose tube can hold the stator against a wheel-well bracket.
Weatherproof 20-circuit end-of-shaft slip ring and encoder, 63.5 mm rotor
This end-of-shaft slip ring has 20 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Contacting rotary seals make it completely weatherproof. Its stainless steel rotor has a 63.5 mm (2.5 in) flange, and its anodized aluminum stator a radial Bendix PT02E-16-26P connector. It is 93 mm long, weighs 425 g and runs up to 2 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. Connector plugs are sealed at the rear with RTV silicone or a sealing backshell, whose tube can hold the stator against a wheel-well bracket. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add either tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC, or, with the 360 ppr encoder, resolver outputs (R), sine and cosine up to ±10 V.
It is used, for example, on vehicle wheels: with tachometer outputs, as on the SR20AW/T512/AX, the direction option gives a positive velocity output for forward motion on both sides of the vehicle.
20-circuit end-of-shaft slip ring and encoder, 50.8 mm rotor
This end-of-shaft slip ring has 20 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Its stainless steel rotor has a 50.8 mm (2 in) flange with color-coded solder terminals, and its anodized aluminum stator a radial Bendix PT02E-16-26P connector. It is 93 mm long, weighs 369 g and runs up to 4 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with three 8-32 screws on a 43.18 mm (1.700 in) circle, and the sensor wires are soldered to the rotor terminals. A rotation restraint is attached to the threaded holes of the stator. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC.
It is used, for example, on a gaged accessory belt pulley or a running engine’s crankshaft, where speed, angle and direction of rotation are recorded with the torque and strain signals.
Weatherproof 20-circuit end-of-shaft slip ring and encoder, 50.8 mm rotor
This end-of-shaft slip ring has 20 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Contacting rotary seals make it completely weatherproof. Its stainless steel rotor has a 50.8 mm (2 in) flange with color-coded solder terminals, and its anodized aluminum stator a radial Bendix PT02E-16-26P connector. It is 93 mm long, weighs 369 g and runs up to 2 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with three 8-32 screws on a 43.18 mm (1.700 in) circle, and the sensor wires are soldered to the rotor terminals. Connector plugs are sealed at the rear with RTV silicone or a sealing backshell, whose tube can hold the stator against a wheel-well bracket. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC.
It is used in wet-weather applications such as automotive wheels, which mostly stay within 2 000 rpm; with tachometer outputs, its analog signals are easier to record than encoder pulses.
36-circuit end-of-shaft slip ring, 63.5 mm rotor
This end-of-shaft slip ring has 36 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its stainless steel rotor has a 63.5 mm (2.5 in) flange with a circular connector, and its anodized aluminum stator a radial circular connector. It runs up to 2 400 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. A rotation restraint is attached to the threaded holes of the stator.
36-circuit end-of-shaft slip ring and encoder, 63.5 mm rotor
This end-of-shaft slip ring has 36 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Its stainless steel rotor has a 63.5 mm (2.5 in) flange, and its anodized aluminum stator a radial Bendix JT02RE-16-35P connector. It is 115 mm long, weighs 482 g and runs up to 2 400 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. A rotation restraint is attached to the threaded holes of the stator. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add either tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC, or, with the 360 ppr encoder, resolver outputs (R), sine and cosine up to ±10 V.
It is used, for example, on a running engine’s crankshaft, for torque near the main bearing, bending and strain in the fillets of the throws, with crank speed and position.
Weatherproof 36-circuit end-of-shaft slip ring, 63.5 mm rotor
This end-of-shaft slip ring has 36 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Contacting rotary seals make it completely weatherproof. Its stainless steel rotor has a 63.5 mm (2.5 in) flange with a circular connector, and its anodized aluminum stator a radial circular connector. It runs up to 2 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. Connector plugs are sealed at the rear with RTV silicone or a sealing backshell, whose tube can hold the stator against a wheel-well bracket.
Weatherproof 36-circuit end-of-shaft slip ring and encoder, 63.5 mm rotor
This end-of-shaft slip ring has 36 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Contacting rotary seals make it completely weatherproof. Its stainless steel rotor has a 63.5 mm (2.5 in) flange, and its anodized aluminum stator a radial Bendix JT02RE-16-35P connector. It is 115 mm long, weighs 482 g and runs up to 2 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with 8-32 screws on a 57.15 mm (2.250 in) circle. Connector plugs are sealed at the rear with RTV silicone or a sealing backshell, whose tube can hold the stator against a wheel-well bracket. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add either tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC, or, with the 360 ppr encoder, resolver outputs (R), sine and cosine up to ±10 V.
It is used in wet-weather applications such as automotive wheels, which mostly stay within 2 000 rpm; with tachometer outputs, its analog signals are easier to record than encoder pulses.
36-circuit end-of-shaft slip ring and encoder, 50.8 mm rotor
This end-of-shaft slip ring has 36 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Its stainless steel rotor has a 50.8 mm (2 in) flange with color-coded solder terminals, and its anodized aluminum stator a radial Bendix JT02RE-16-35P connector. It is 115 mm long, weighs 369 g and runs up to 2 400 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with three 8-32 screws on a 43.18 mm (1.700 in) circle, and the sensor wires are soldered to the rotor terminals. A rotation restraint is attached to the threaded holes of the stator. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add either tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC, or, with the 360 ppr encoder, resolver outputs (R), sine and cosine up to ±10 V.
It is used, for example, on a running engine’s crankshaft, where the encoder records crank speed and position while all 36 rings stay available for the strain channels.
Weatherproof 36-circuit end-of-shaft slip ring and encoder, 50.8 mm rotor
This end-of-shaft slip ring has 36 gold alloy rings rated at 0.5 A, which carry strain gages, thermocouples, accelerometers and low voltages with a peak resistance variation of 0.1 Ω. Its optical encoder, of 256, 360, 500 or 512 pulses per revolution according to the model, measures speed, angle and direction of rotation without using any ring. Contacting rotary seals make it completely weatherproof. Its stainless steel rotor has a 50.8 mm (2 in) flange with color-coded solder terminals, and its anodized aluminum stator a radial Bendix JT02RE-16-35P connector. It is 115 mm long, weighs 369 g and runs up to 2 000 rpm, from −40 to 85 °C.
On installation, the rotor flange is screwed to the end of the shaft with three 8-32 screws on a 43.18 mm (1.700 in) circle, and the sensor wires are soldered to the rotor terminals. Connector plugs are sealed at the rear with RTV silicone or a sealing backshell, whose tube can hold the stator against a wheel-well bracket. The encoder runs on 5 to 20 V DC, 100 mA, and gives A and B quadrature, index and A⊕B pulses of 0 to 5 V, with a maximum cumulative error of 0.25°. As an option, built-in electronics add either tachometer outputs (T), a velocity voltage up to ±10 V and a position voltage up to +10 V, on 8 to 18 V DC, or, with the 360 ppr encoder, resolver outputs (R), sine and cosine up to ±10 V.
It is used in wet-weather applications such as automotive wheels, which mostly stay within 2 000 rpm; with tachometer or resolver outputs, its analog signals are easier to record than encoder pulses.
Specifications
| Circuits | 10 |
|---|---|
| Rotation sensor | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 80 mm (without mating connectors) |
| Weight | 397 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 80 mm (without mating connectors) |
| Weight | 397 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 80 mm (without mating connectors) |
| Weight | 397 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 80 mm (without mating connectors) |
| Weight | 397 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Circuits | 10 |
|---|---|
| Rotation sensor | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 80 mm (without mating connectors) |
| Weight | 397 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 80 mm (without mating connectors) |
| Weight | 397 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 80 mm (without mating connectors) |
| Weight | 397 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 80 mm (without mating connectors) |
| Weight | 397 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 10 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 10 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Circuits | 20 |
|---|---|
| Rotation sensor | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 425 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 425 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 425 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 425 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Circuits | 20 |
|---|---|
| Rotation sensor | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 425 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 425 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 425 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 425 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix PT circular connector, alternative position; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 4 000 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 93 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 20 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix PT circular connector, alternative position; rotor: solder terminals) |
| Circuits | 36 |
|---|---|
| Rotation sensor | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 482 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 482 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 482 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 482 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 63.5 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Circuits | 36 |
|---|---|
| Rotation sensor | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 482 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 482 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 482 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 482 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 63.5 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector (stator: radial Bendix JT circular connector; rotor: circular connector) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (drawing C337077B, 4.52 in) |
| Weight | 425 g (drawing C337077B, 15 oz) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (drawing C337077B, 4.52 in) |
| Weight | 425 g (drawing C337077B, 15 oz) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (drawing C337077B, 4.52 in) |
| Weight | 425 g (drawing C337077B, 15 oz) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Dimensions | length 115 mm (drawing C337077B, 4.52 in) |
| Weight | 425 g (drawing C337077B, 15 oz) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 400 rpm |
| Running torque | 0.021 N·m (3 in-oz without seals) |
| Rotor diameter | 50.8 mm |
| Seals | None (sealed against dust) |
| Operating temperature | −40 to 85 °C |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | None |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Encoder signals | A · B · Index · A⊕B (A and B in quadrature, 1 ppr index, 0 to 5 V) |
| Current per circuit | 500 mA |
| Supply voltage | 5 to 20 V (encoder) |
| Supply current | 100 mA (encoder) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (without mating connectors) |
| Weight | 369 g (without mating connectors) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 256 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (drawing C337077B, 4.52 in) |
| Weight | 425 g (drawing C337077B, 15 oz) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (drawing C337077B, 4.52 in) |
| Weight | 425 g (drawing C337077B, 15 oz) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 500 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (drawing C337077B, 4.52 in) |
| Weight | 425 g (drawing C337077B, 15 oz) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 512 ppr |
| Encoder electronics | Tachometer |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Supply voltage | 8 to 18 V (with the tachometer outputs) |
| Supply current | 200 mA (with the tachometer outputs) |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Dimensions | length 115 mm (drawing C337077B, 4.52 in) |
| Weight | 425 g (drawing C337077B, 15 oz) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
| Angle accuracy | ≤ 0.25° (maximum cumulative error) |
|---|---|
| Circuits | 36 |
| Rotation sensor | Encoder |
| Encoder resolution | 360 ppr |
| Encoder electronics | Resolver |
| Embedded amplifier | None |
| Max peak contact noise | ≤ 100 mΩ |
| Current per circuit | 500 mA |
| Mounting | End of shaft |
| Max speed | 2 000 rpm |
| Running torque | 0.148 N·m (21 in-oz with seals) |
| Rotor diameter | 50.8 mm |
| Seals | Contacting rotary seals (W) |
| Operating temperature | −40 to 85 °C |
| Protection | Weatherproof |
| Connections | Connector · Solder terminals (stator: radial Bendix JT circular connector; rotor: solder terminals) |
Request a quote
The stator always has a radial circular connector (X).
Resources
Datasheets and manuals
Drawings
None for SR10A/AX.
CAD models
None for SR10A/AX.
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
None for SR10AW/AX.
CAD models
None for SR10AW/AX.
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
None for SR10M/E256/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10M/E360/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10M/E500/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10M/E512/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10M/T256/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10M/T360/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10M/T500/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10M/T512/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10MW/E256/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10MW/E360/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10MW/E500/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10MW/E512/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10MW/T256/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10MW/T360/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10MW/T500/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR10MW/T512/X.
Guides and notes
Datasheets and manuals
Drawings
None for SR20A/AX.
CAD models
None for SR20A/AX.
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
None for SR20AW/AX.
CAD models
None for SR20AW/AX.
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
Drawings
None for SR36A/AX.
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
CAD models
Guides and notes
Datasheets and manuals
Drawings
None for SR36AW/AX.
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
Drawings
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
CAD models
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Datasheets and manuals
Guides and notes
Related applications
-
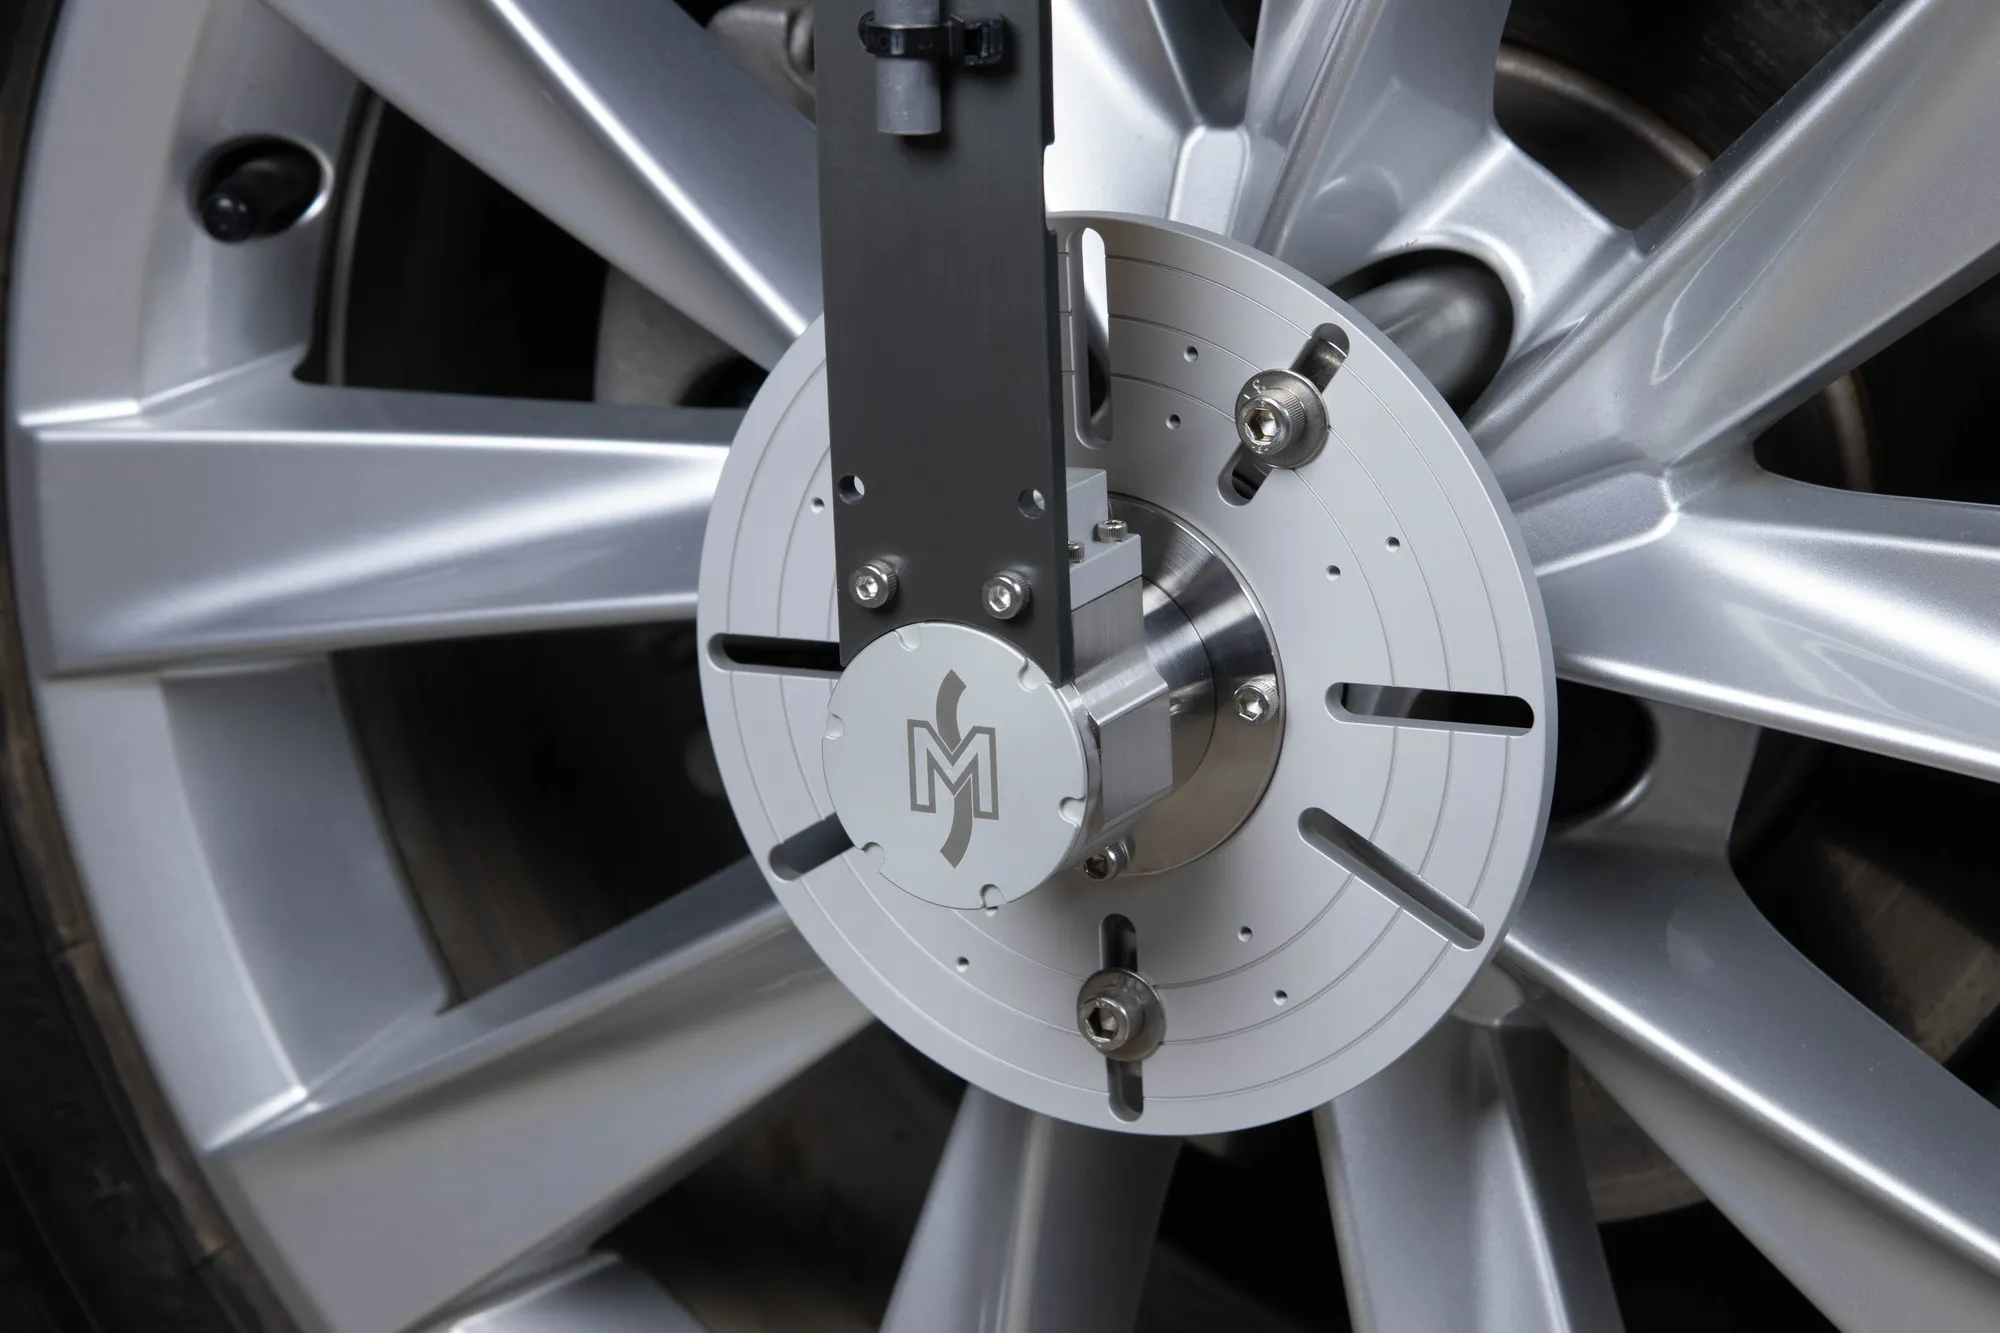 Speed Encoder pulses to analog voltage Encoder pulses converted in line to a speed voltage and an angle voltage, for recorders that cannot read pulses.
-
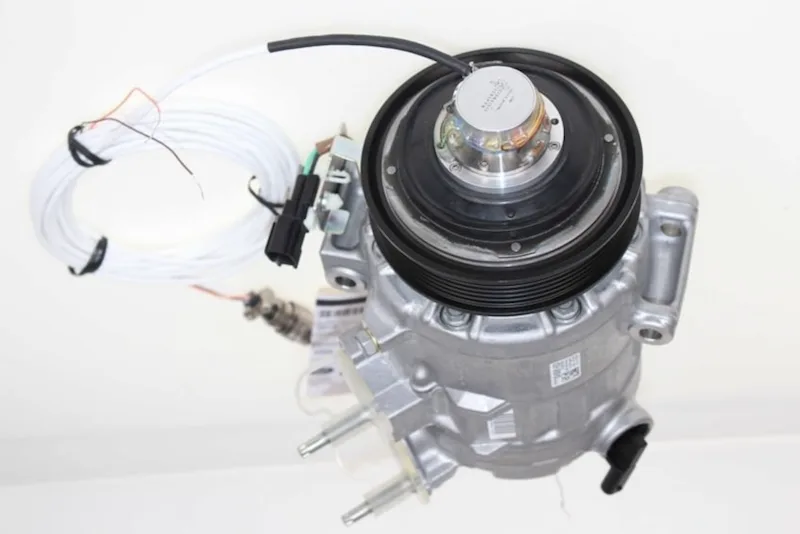 Powertrain Accessory belt pulley torque Torque on an accessory drive pulley, from a strain gage bridge on the pulley and a slip ring on the shaft end.
-
 Engine Crankshaft measurements Torque, bending and strain on the production crankshaft with the engine running, in the vehicle or on the dyno.
-
 Efficiency Vehicle efficiency and power mapping Torque and speed measured at each driveline stage, from engine to wheel, so each power loss has a location.
If the SR/ERT Series is not the one
- 60 ppr is enough SR10AW/E60/A
Weatherproof, 10 circuits, 60 ppr encoder, connector on the rotor.
- Inside a small bore SR20/75/W
20 circuits in a 0.75 in diameter rotor and stator.
- More circuits SR45A-AXHS and SR60A-AXHS
End of shaft, 45 or 60 circuits, 4 000 rpm.
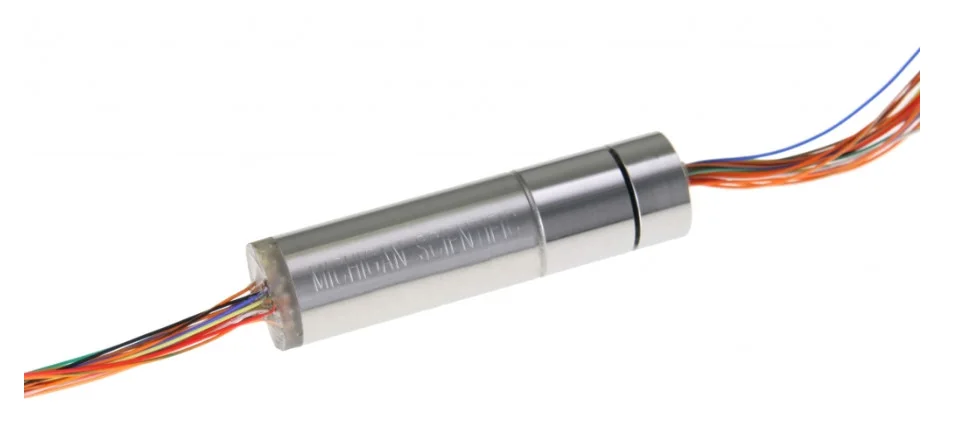
A question on this product?
Describe the measurement. An application engineer answers.
More details to give? Use the full contact form.